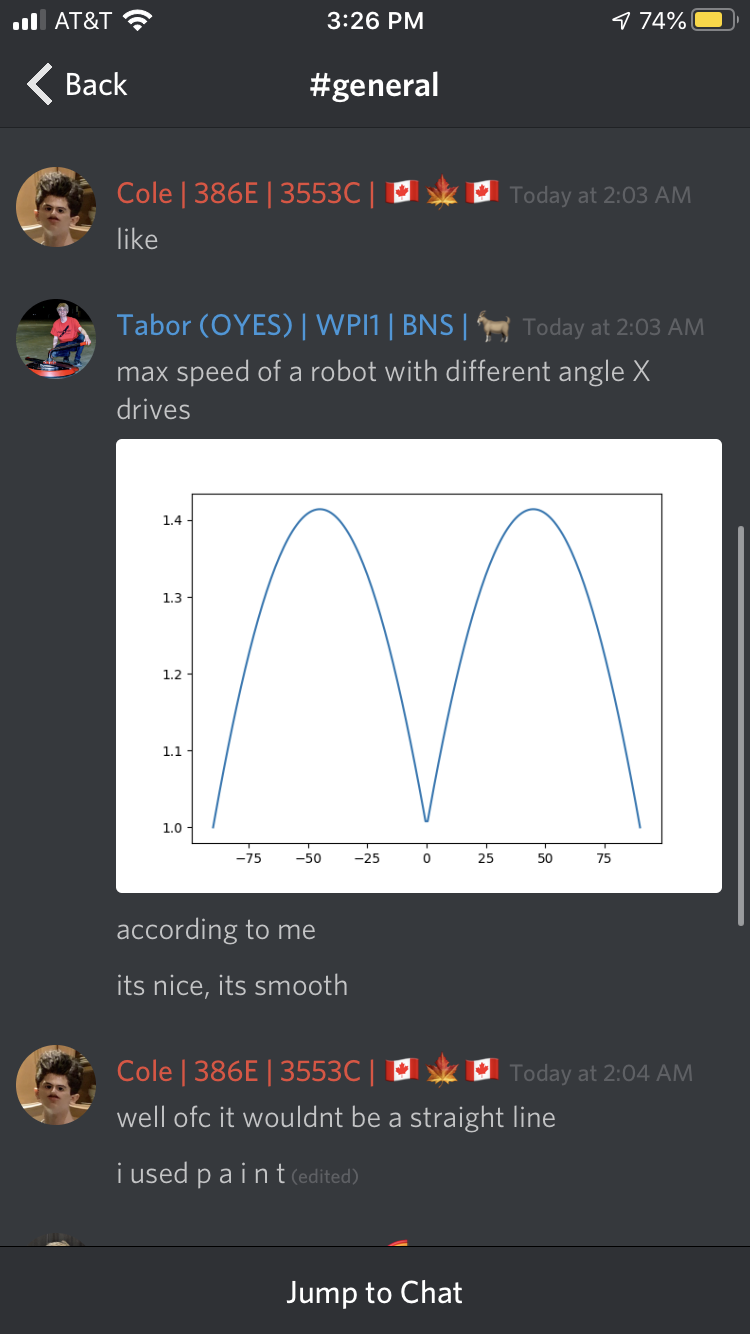
We were actually having a conversation about this on discord yesterday. The discussion lasted over 4 hours. In the solution you describe, you theoretically approach infinite speed as the MA gets smaller and smaller. While this may be true (in fact I agree with what you described), many people commonly see it as the following:
Because of this discrepancy, (and the fact that large amounts of evidence and logic were compiled on both sides of the discussion, it is not fair to simply declare one untrue until we experimentally test it.
(The motion you are describing is one who’s MA follows a csc/sec function, where csc theta is forwards ma and sec theta is sideways ma, where theta= degrees from tank)
You must just be confusing what the vector does then. The vector you showed earlier is for force, which is inversely related to speed (in this scenario)
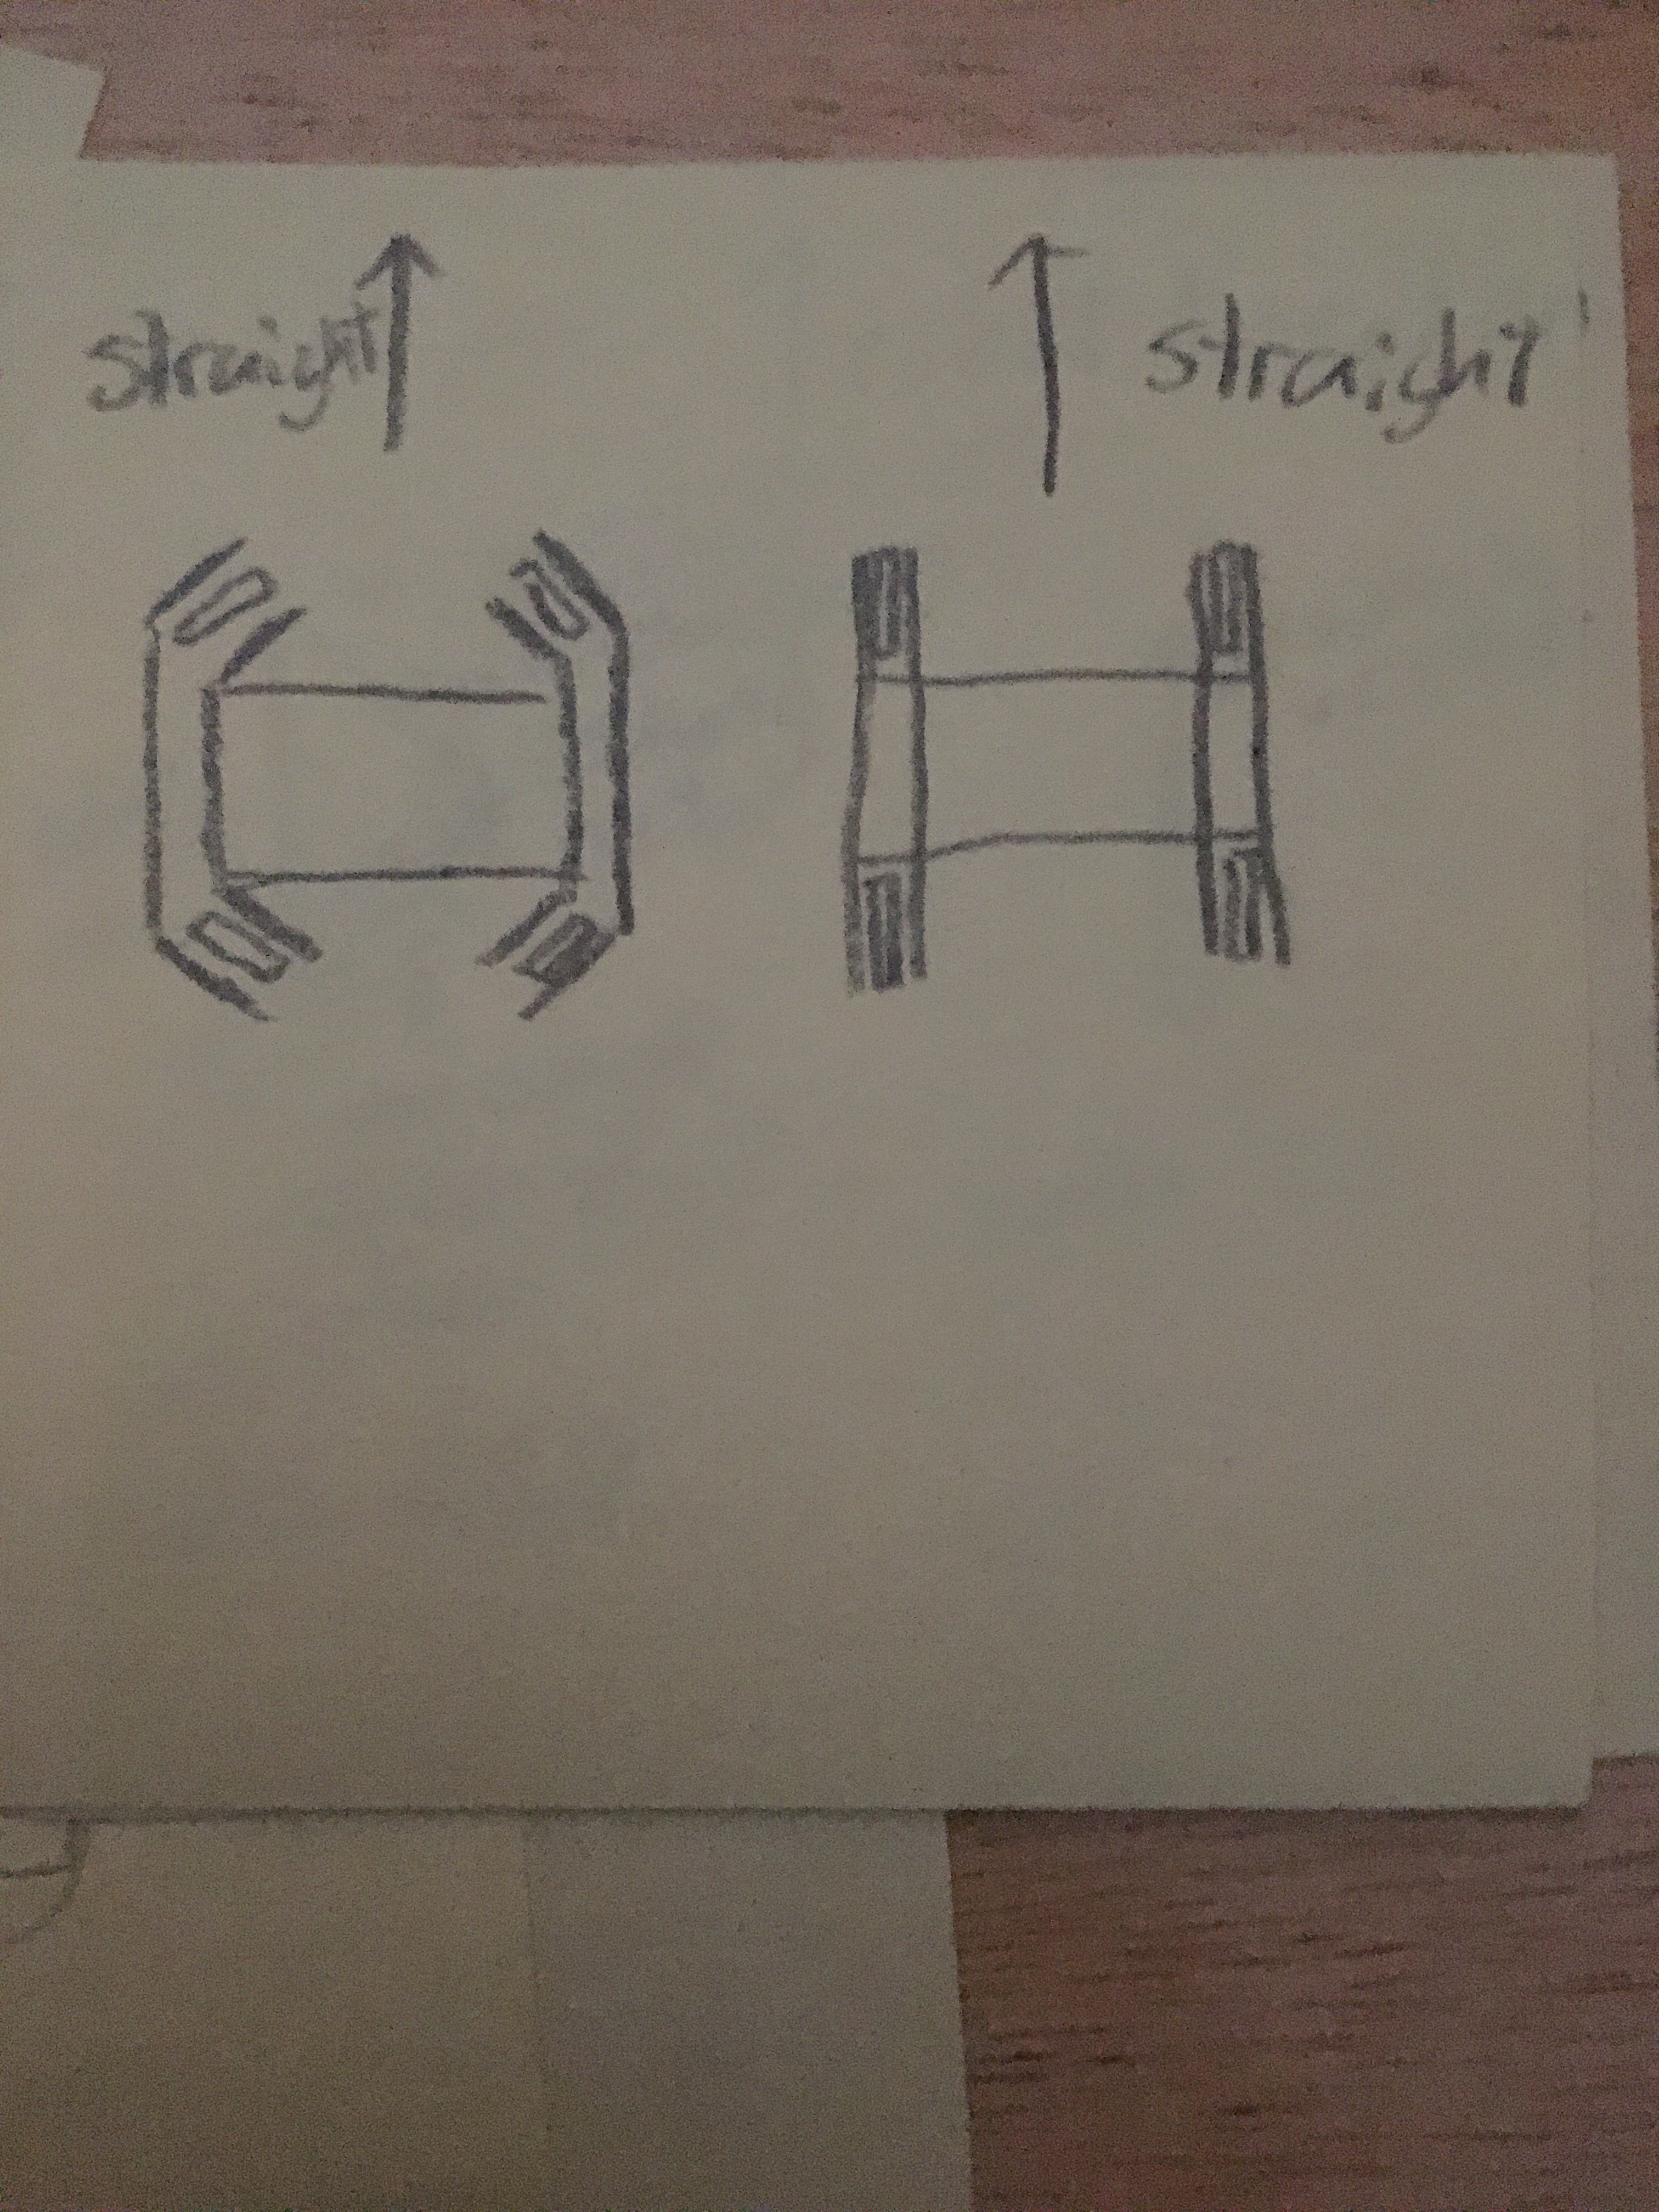
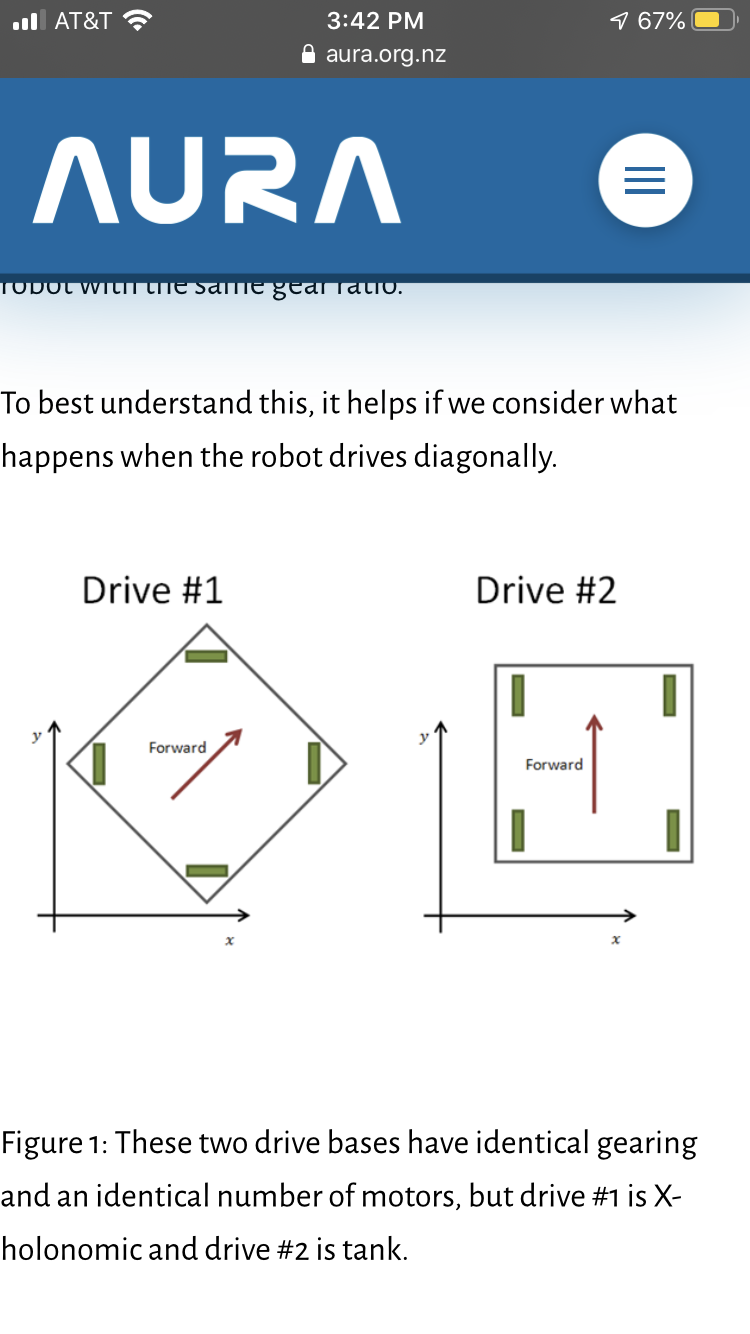
Yes with that perspective of straight the straight direction is faster. When I was talking about diagonal being faster earlier I was referring to the x drive orientation that was shown in the aura article I linked ( it looks like a + sign).
Not exactly. Specifically, I would add more bracing between the two sides, with some above the channel and some below. This way your drive will be stronger and have less torsion.
Yes, but again I would put some bracing on the top of the C-channels. It doesn’t have to go all the way across, just a small piece on either side to hold it together from the top.