The black wire is ground and the red wire is 5V. Those are the two you need. If you have more wires in your USB extension, they are data wires. You do not need those.
Maybe I mixed up which pin was which…
Also, I indeed did not consider programmatically powering the LEDs on or off.
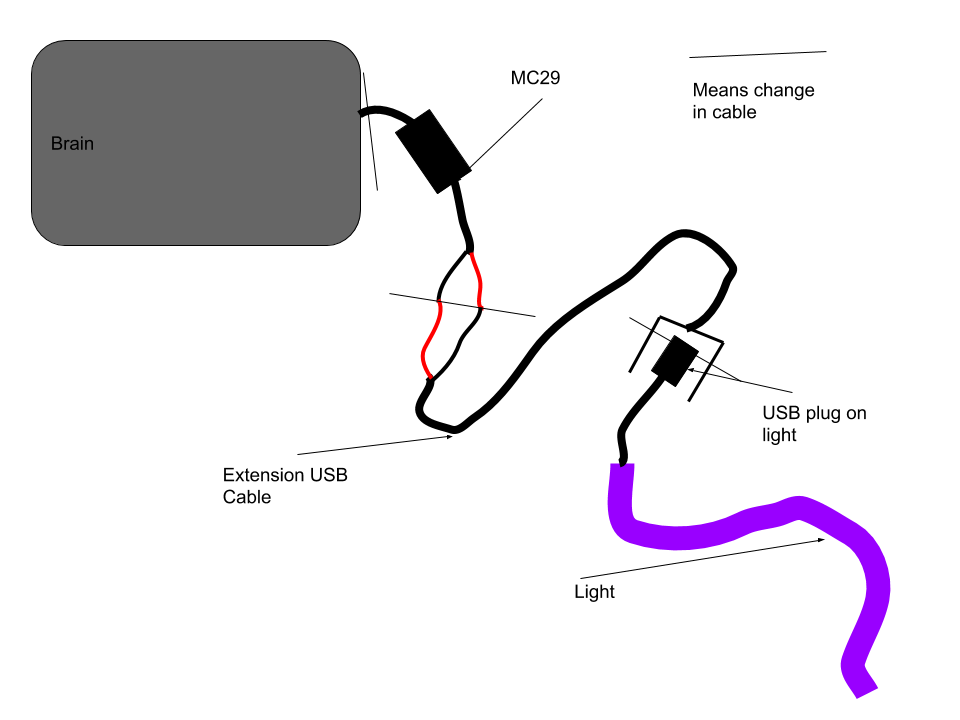
That looks like how I have it set up.
And when it plugs into the brain it just turns on?
No, you need code. I uploaded my code.
Okay. Do I need to set it up as an output in the setup or anything?
Did you look at the code?
Yes. I just realized that that’s in c++ pro, I was just using the regular c++. I see the setup in there - is there any way to do that for the regular c++?
There is no PWM out in the graphical robot configuration page, but I think you can just put the configuration for the port at the top of the main.cpp file:
vex::pwm_out Pwm_out = vex::pwm_out(Brain.ThreeWirePort.A);
I haven’t tried it though, so I’m not 100%.
It works. Thanks for all the help.
Would the remote control one work?
You can just connect the LED strips without a motor controller to the three wire ports without any programming:

I tried this and it works flawlessly, and turns on right when the robot is on
Can you zoom out a bit?