This is mid-west VEX in a nutshell, and the reason why I put so much effort into “getting good” last year.
I went from being a very, very inexperienced rookie to tournament finalist by the end of the year, and personally I’m very proud of that. (Personally, I’m aiming for at least one of each award this year. Hoping to get design early-season)
For a robot that is supposedly completely autonomous during the whole match, its Auton is pretty miserable.
Presumably they just use the same code, and don’t have a pre-programmed routine beyond a certain point, but I don’t know.
So for the precoded autonomous. Which was just dumping the cube I don’t think I ever saw a VEXU team get their first dump off faster. The rest of autonomous the robot made its own decisions. Which meant it was the only VEXU robot that would adapt and combat its opponents autonomous.
I wouldn’t so quickly say this was the “only” VEXU robot that could adapt to its opponents autonomous. Many teams, through scouting and code, made autos that would counter teams based on where they dumped, essentially “adapting” and countering their opponent.
For example, here team MASON1 countered WPI0 based on where they dumped. (I understand this is a different WPI team, I am linking it to show the adaptation) .
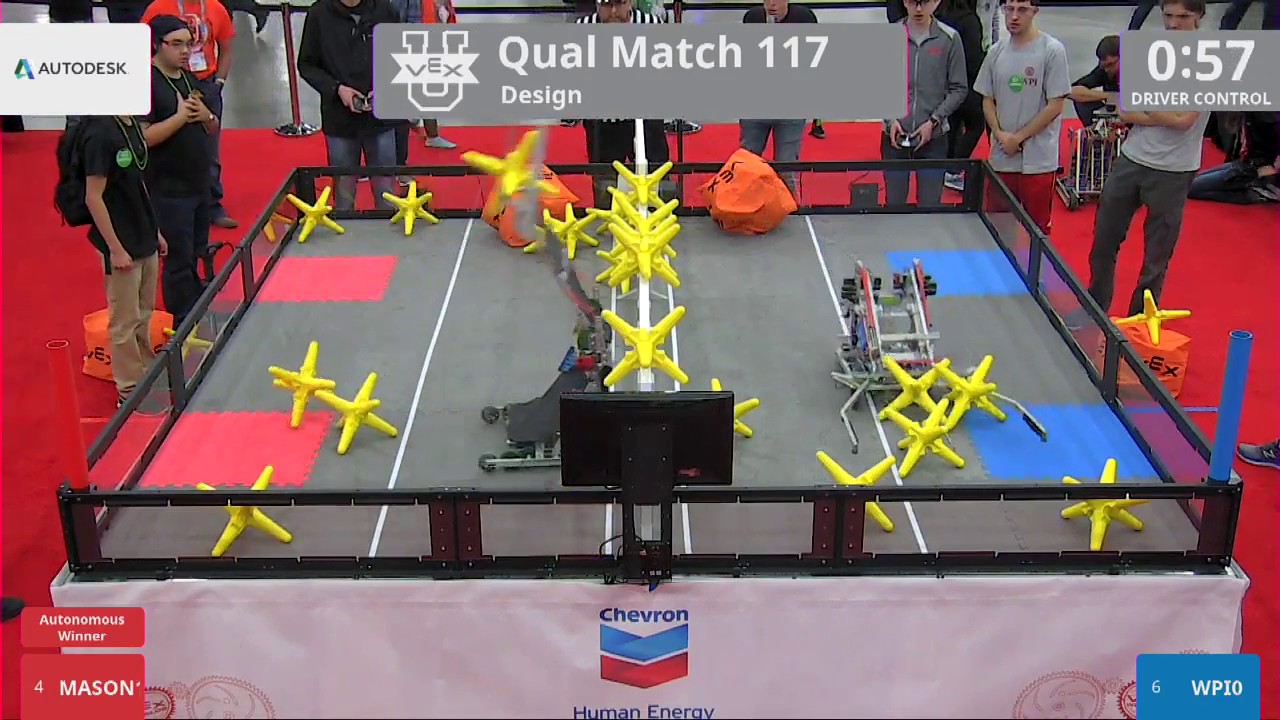
Regardless of what I said above, this was a very impressive achievement that I’ve never seen done before. Thank you for sharing the code as well, I feel it will be a great resource for teams that wish to explore completely autonomous robots.
You all set the bar higher for all the VEXU teams across the world, showing that this level of code is possible on a VEX robot. Best of luck with “In the Zone”, can’t wait to see what you guys come up with :)!