I had a chance to read through all details one more time…
First, I was trying to understand if your flywheel control algorithm is a continuous (textbook definition) PID, where everything is controlled in a smooth manner, without artificial jumps, vs the multi-segmented approach, where if() statements introduce discontinuity.
For example, your 7842F-Alpha-Code-RobotC repository has such if() statement, but in V5 code it is essentially a nop-statement
Then I got lost trying to decide which of the features I like more:
demonstrated at 3:35 in this video: https://youtu.be/iW4RlnHbDrY?t=215
or the Vision Sensor instant visualization and filtering:
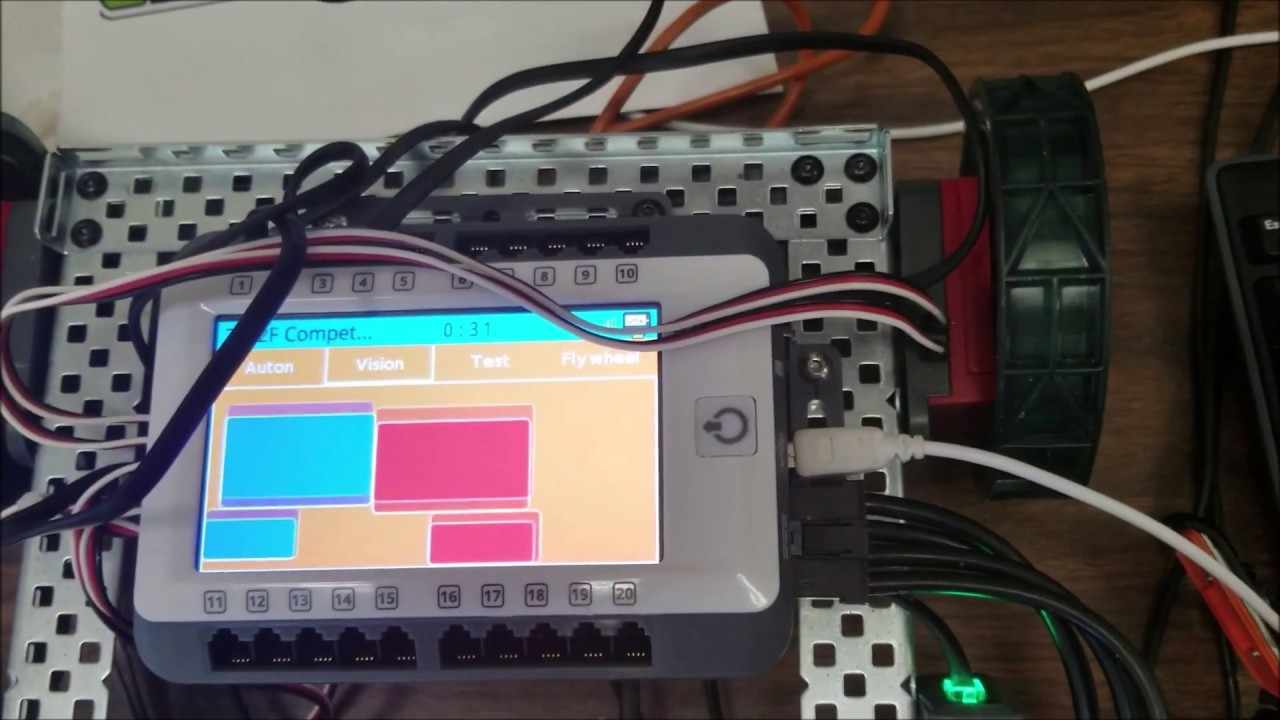
Please, don’t wait until the end of the season to release the code. 