To be fair that was very early in vex, when they didn’t have much experience, I’m fine with these exploits existing but I would like them to take more effort
So, the locked ball is not far enough back to do something like what is pictured in 2020 - 2021 VEX Robotics Competition - Change Up - #116 by Mentor_355v and score 5 total?
You probably can’t get 2 side by side in the corner. You could probably get a 4th ball in front of the jammed one but it could be descored so it probably wouldn’t be worth it
why would you try to get more than 3 in a goal tho?
Because there are 32 balls and only 9 goals, so if you only scored 3 in each goal then there are extra balls. This problem will naturally be eliminated if and when hoarding becomes used effectively by more teams, but for early season it might not be a bad idea.
Here’s the thing. Matches become extremely predictable if that happens. If a team wins auton, they’ll immediately try and go for a diagonal. If they do that, both robots can defend middle and win. If a team doesn’t win auton, they’ll just lock the 2 corner goals on their side of the field. Since all the corners are locked, there are only four rows left. Teams will just defend their home row side goal and it’ll be a battle for the two auton line side goals. The auton losers can at best win by one point if they get that row and the center. So essentially, the auton winners only have to defend two goals to guarantee a win.
Locking balls is broken
It’s gonna become a game of who can win auton
Note: this argument only takes into account rows and not individual balls, but the point still stands imo.
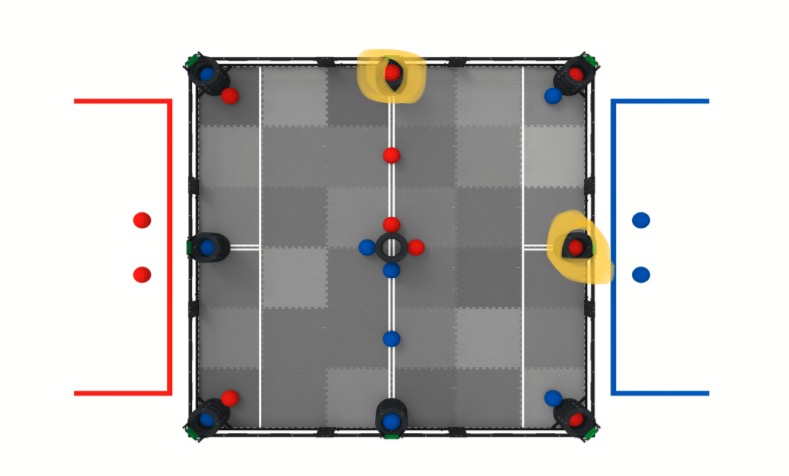
Ik that that probably sounds very confusing so TL;DR the auton winner only has to defend the marked goals above on their side to pretty much guarantee a victory
Crisis averted, it seems ez to take out
Thank you @224x, very cool.
Actually though, how fast are your intakes running and how far wedged in was the ball?
Idk this isn’t my vid I just found it, I think it’s all the way back though, and I think it’s VTOC robot
I wish i know how to insert the clapping hand emoji over here.
But this is the type of attitude that i was talking abt!!
There are 2 approach to this issue…
-
make changes to the field elements… which honestly, it is not difficult. just add a standoff on the ring to stop the balls from rolling up.
-
teams to see it as a problem to solve and think of ways or mechanism to solve it or dislodge the balls.
I definitely prefer the 2nd approach.
And @224x just showed the way to it.
edit: just saw the post that it was done by another team. Well done to whichever team that figured this out!
edt 2: when you take a step back and look at the big picture, it gives me a… a strange feeling.
Not long after game release, we have lots of teams saying that this is just too easy a game. with meta bot appearing within days, etc.
and now we have this issue of “locked” balls, which i thought it will add a layer of complexity to the game. But yet many in the forum rather don’t want this additional problem to solve.
I think that goal isn’t set up 100% correctly. The #4 spacer was shown to fit snugly in between those rings in the center, but that second ring actually sags significantly, and the #4 spacer is supposed to be the space between the two rings right next to the post, which is probably higher on that goal. which means that goal is looser than a perfect one. I can confirm this just because there is no way any sort of roller would be able to dislodge the balls from my goals.
which is even worse imo, because the ±1" field tolerances will allow some goals to be locked, and others not to be. inconsistent. Which means that if the goals you start on happen to be lockable, and the ones your opponent starts on down, you immediately have a huge unfair advantage.
Then let’s try to figure out mechanism to dislodge balls?
which may or may not be possible depending on minor variations in the goal. My major complaint isn’t the strategy itself, but the inconsistency it creates.
sigh… there will be inconsistency in all games.
but i do agree - some inconsistencies are not acceptable, but some are actually just another design consideration to take note of.
I don’t have the game element to do any testing (yes… nowadays game elements are available to US teams ahead of many other countries).
but for this case, factoring in the tolerance, if it is physically possible to dislodge the ball, then we should accept the inconsistency caused by the variant (within tolerance limit) in the field setup.
Eg. if we factor in the tolerance, and if the locked ball is still able to be removed by using a c-channel, etc, then there is actually no case over here.
but again - there were times that goals were designed in such a way that we were allowed to “lock” our scores.
look at this:
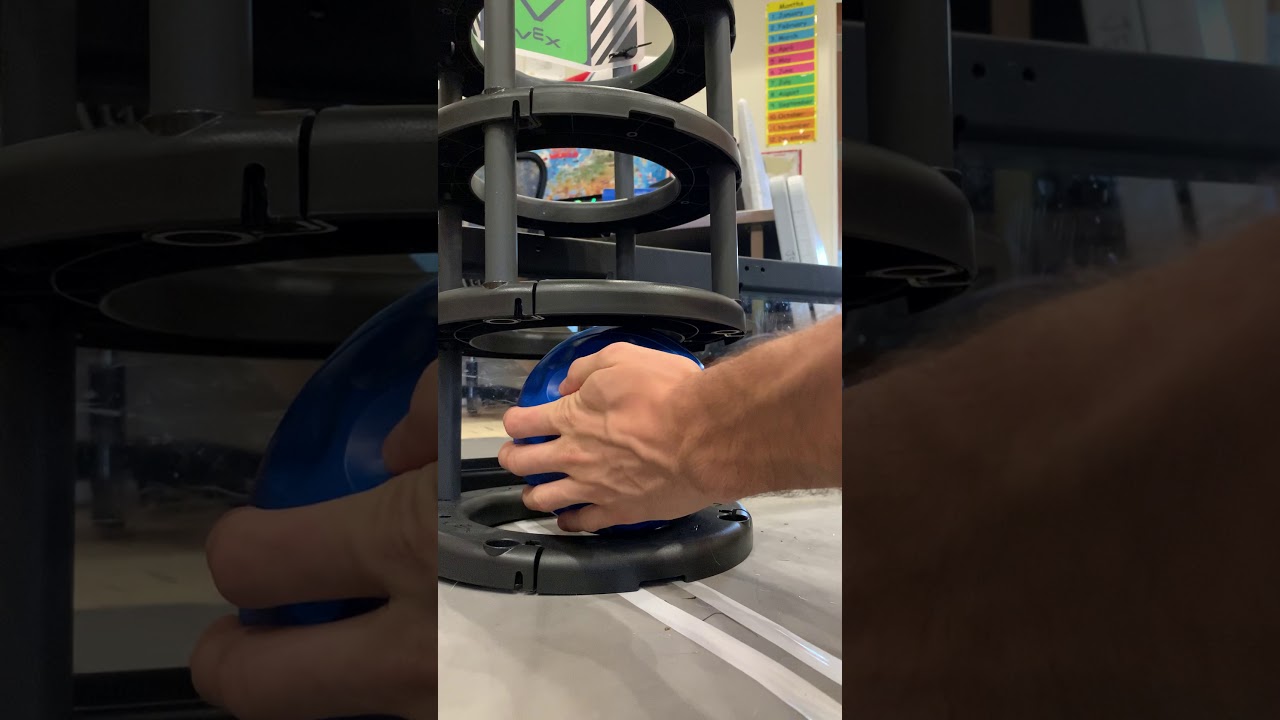
this goal is within the field tolerances. minor variations in goals is ok, but stuff like this isn’t tbh. I really think that the negative tolerances on these goals was a very bad choice. and if they’re going to keep it like that, they should at least lower the tolerance to like ± 0.1 icnhes, instead of ±1"
imagine dislodging from a goal like this, it simply won’t be possible.
ok… but think this got to do with descoring in general and not about the locked balls?
the tightness of those rings is what holds the lodged balls in. This was to demonstrate how the ring tightness can effect descoring, and the lodging is even more sensitive to these tolerances.
of course, it may turn out that all of the goals are more or less the same, which is fine I guess. Not the strategy I want, but as long as it’s level, it’s fine.
so have we determined how much total force it takes to actually remove a ball from a goal if it is just sitting in there normally?
depends on the goal, but generally not too much. 400 rpm rollers can do it fine