Hi,
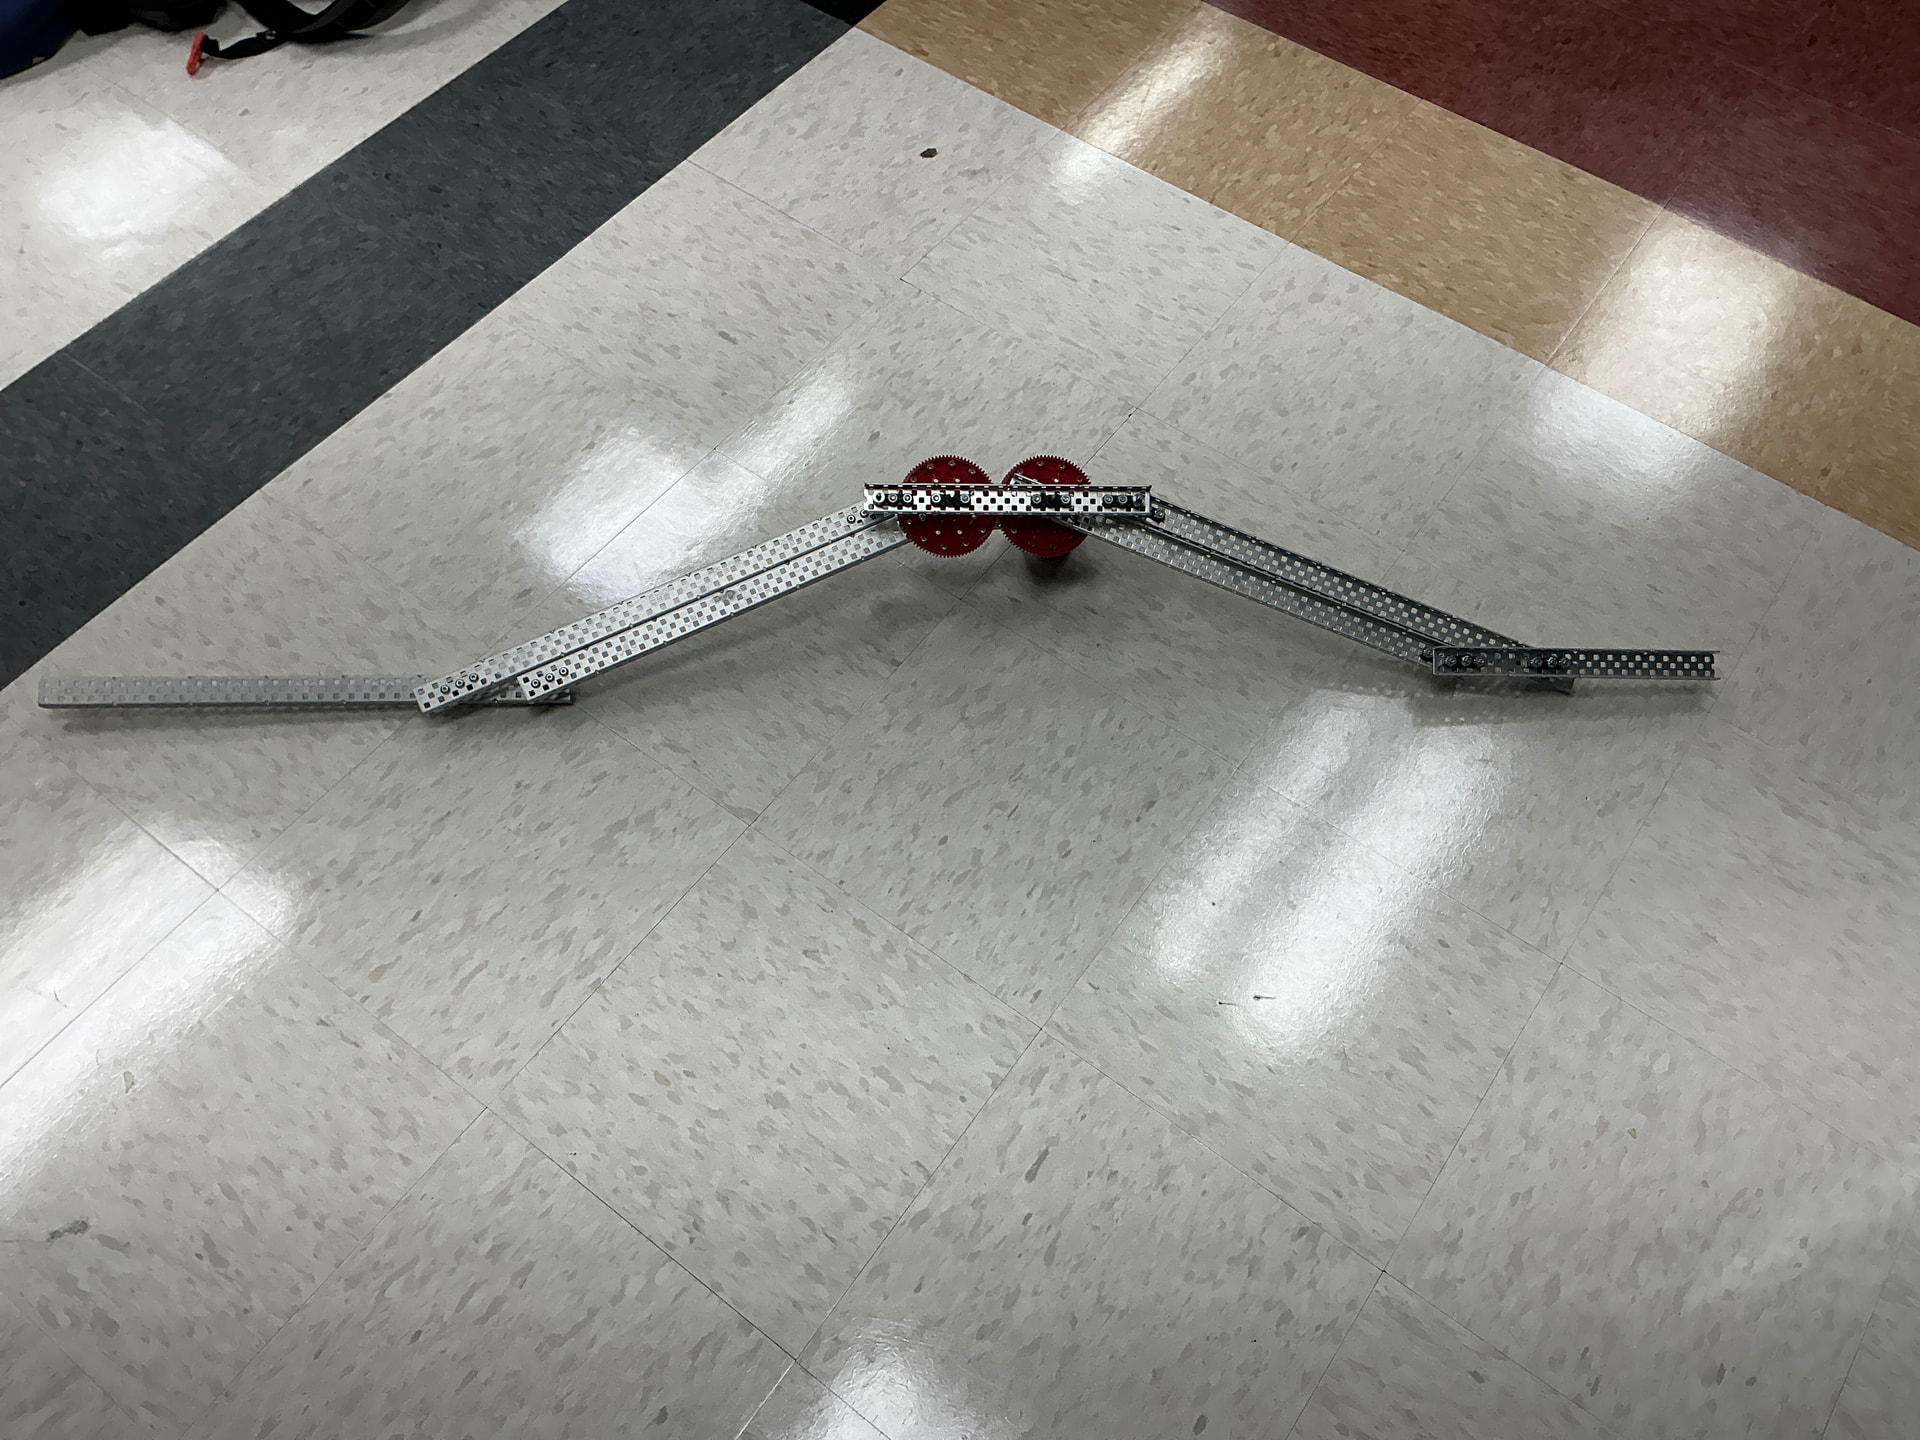
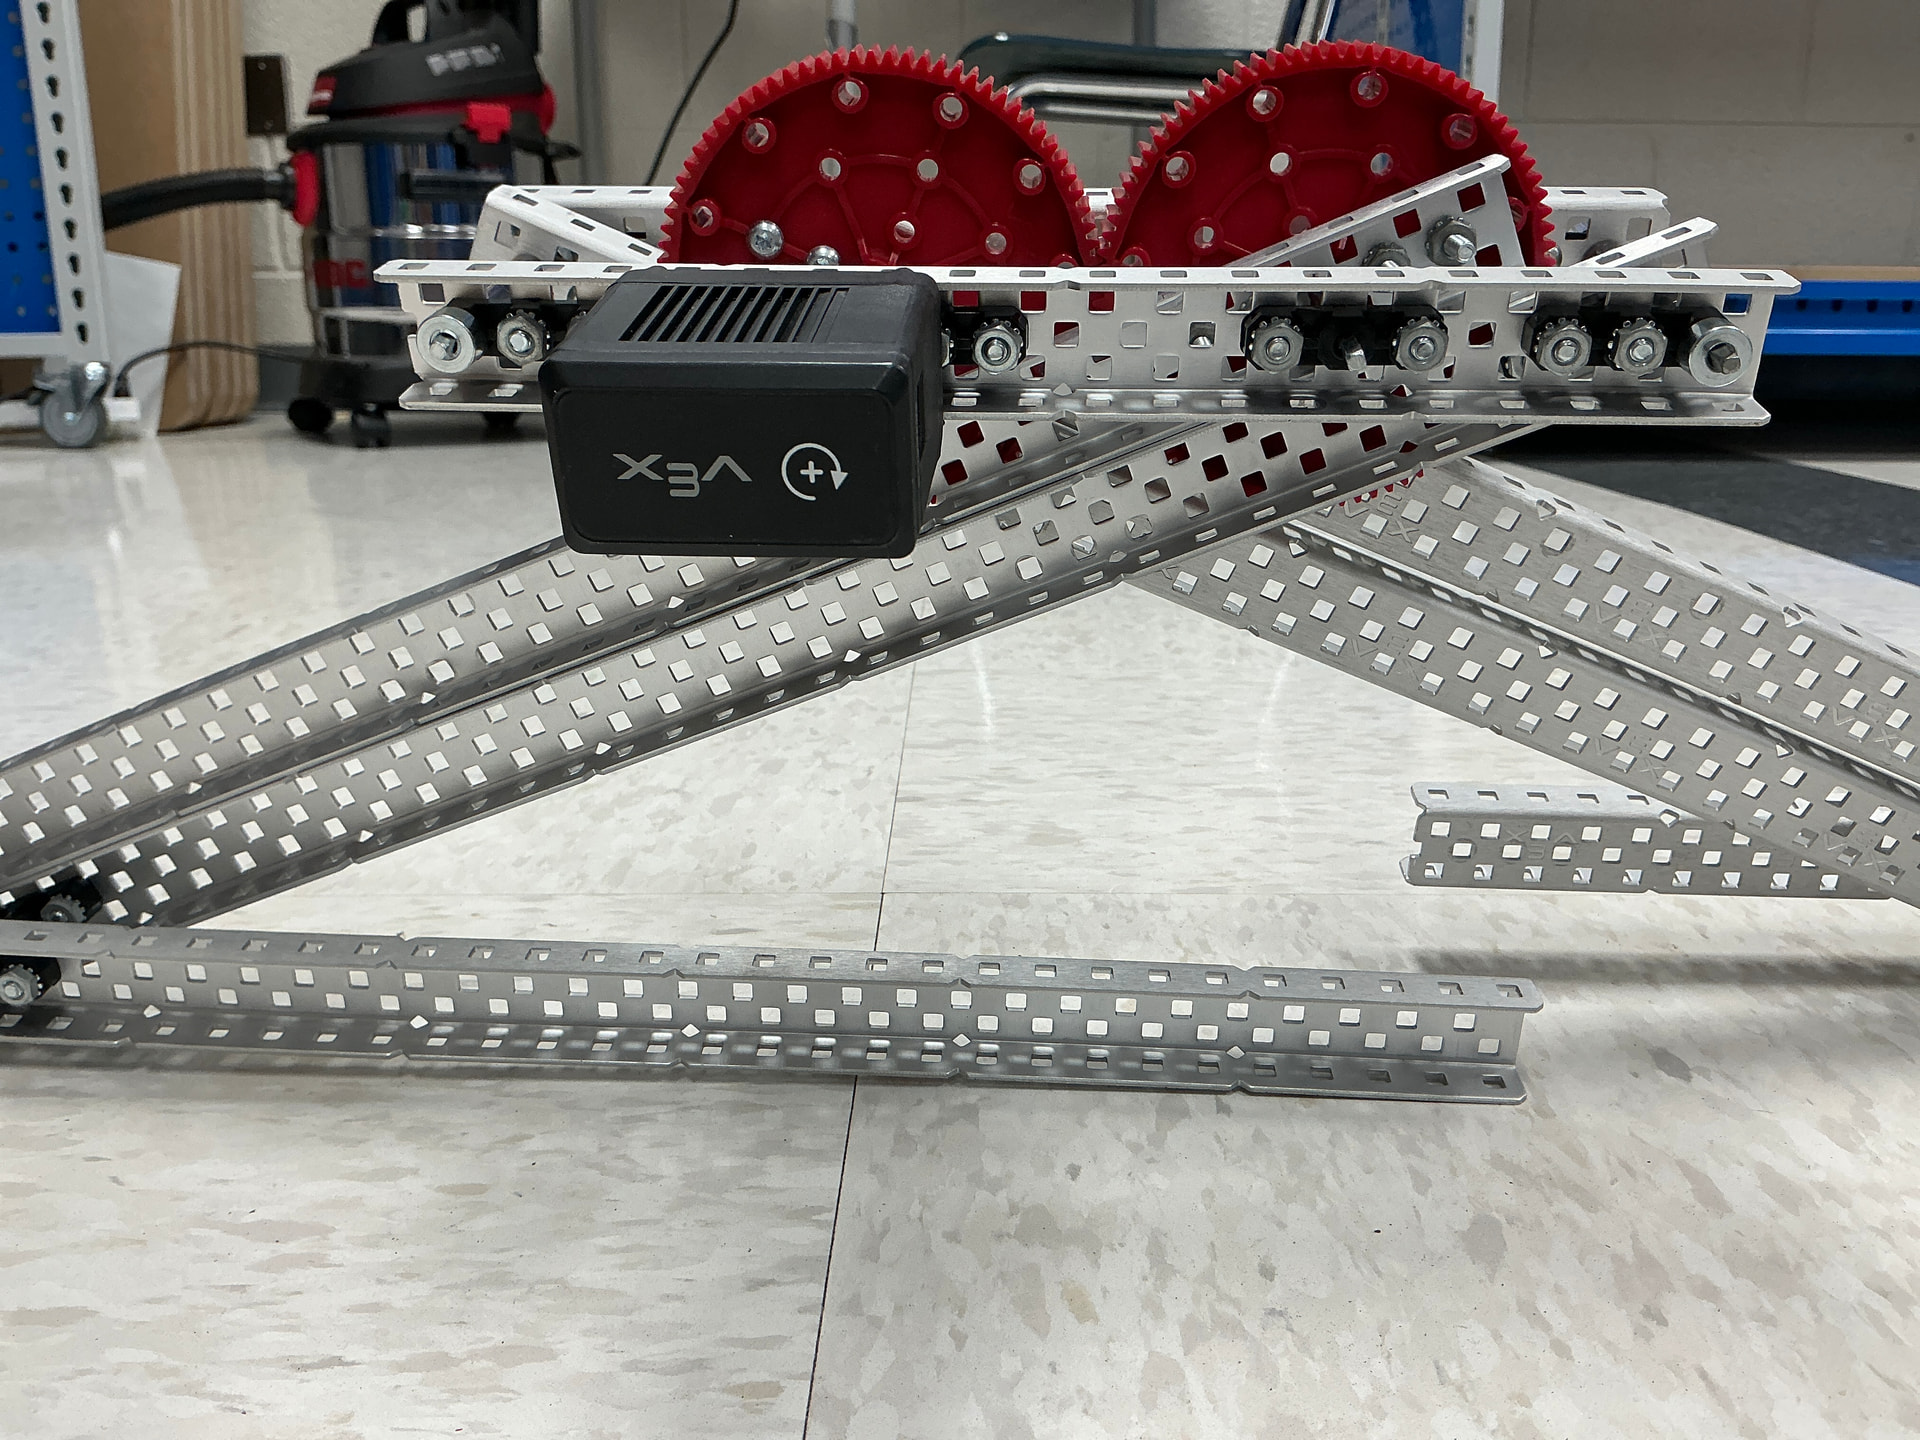
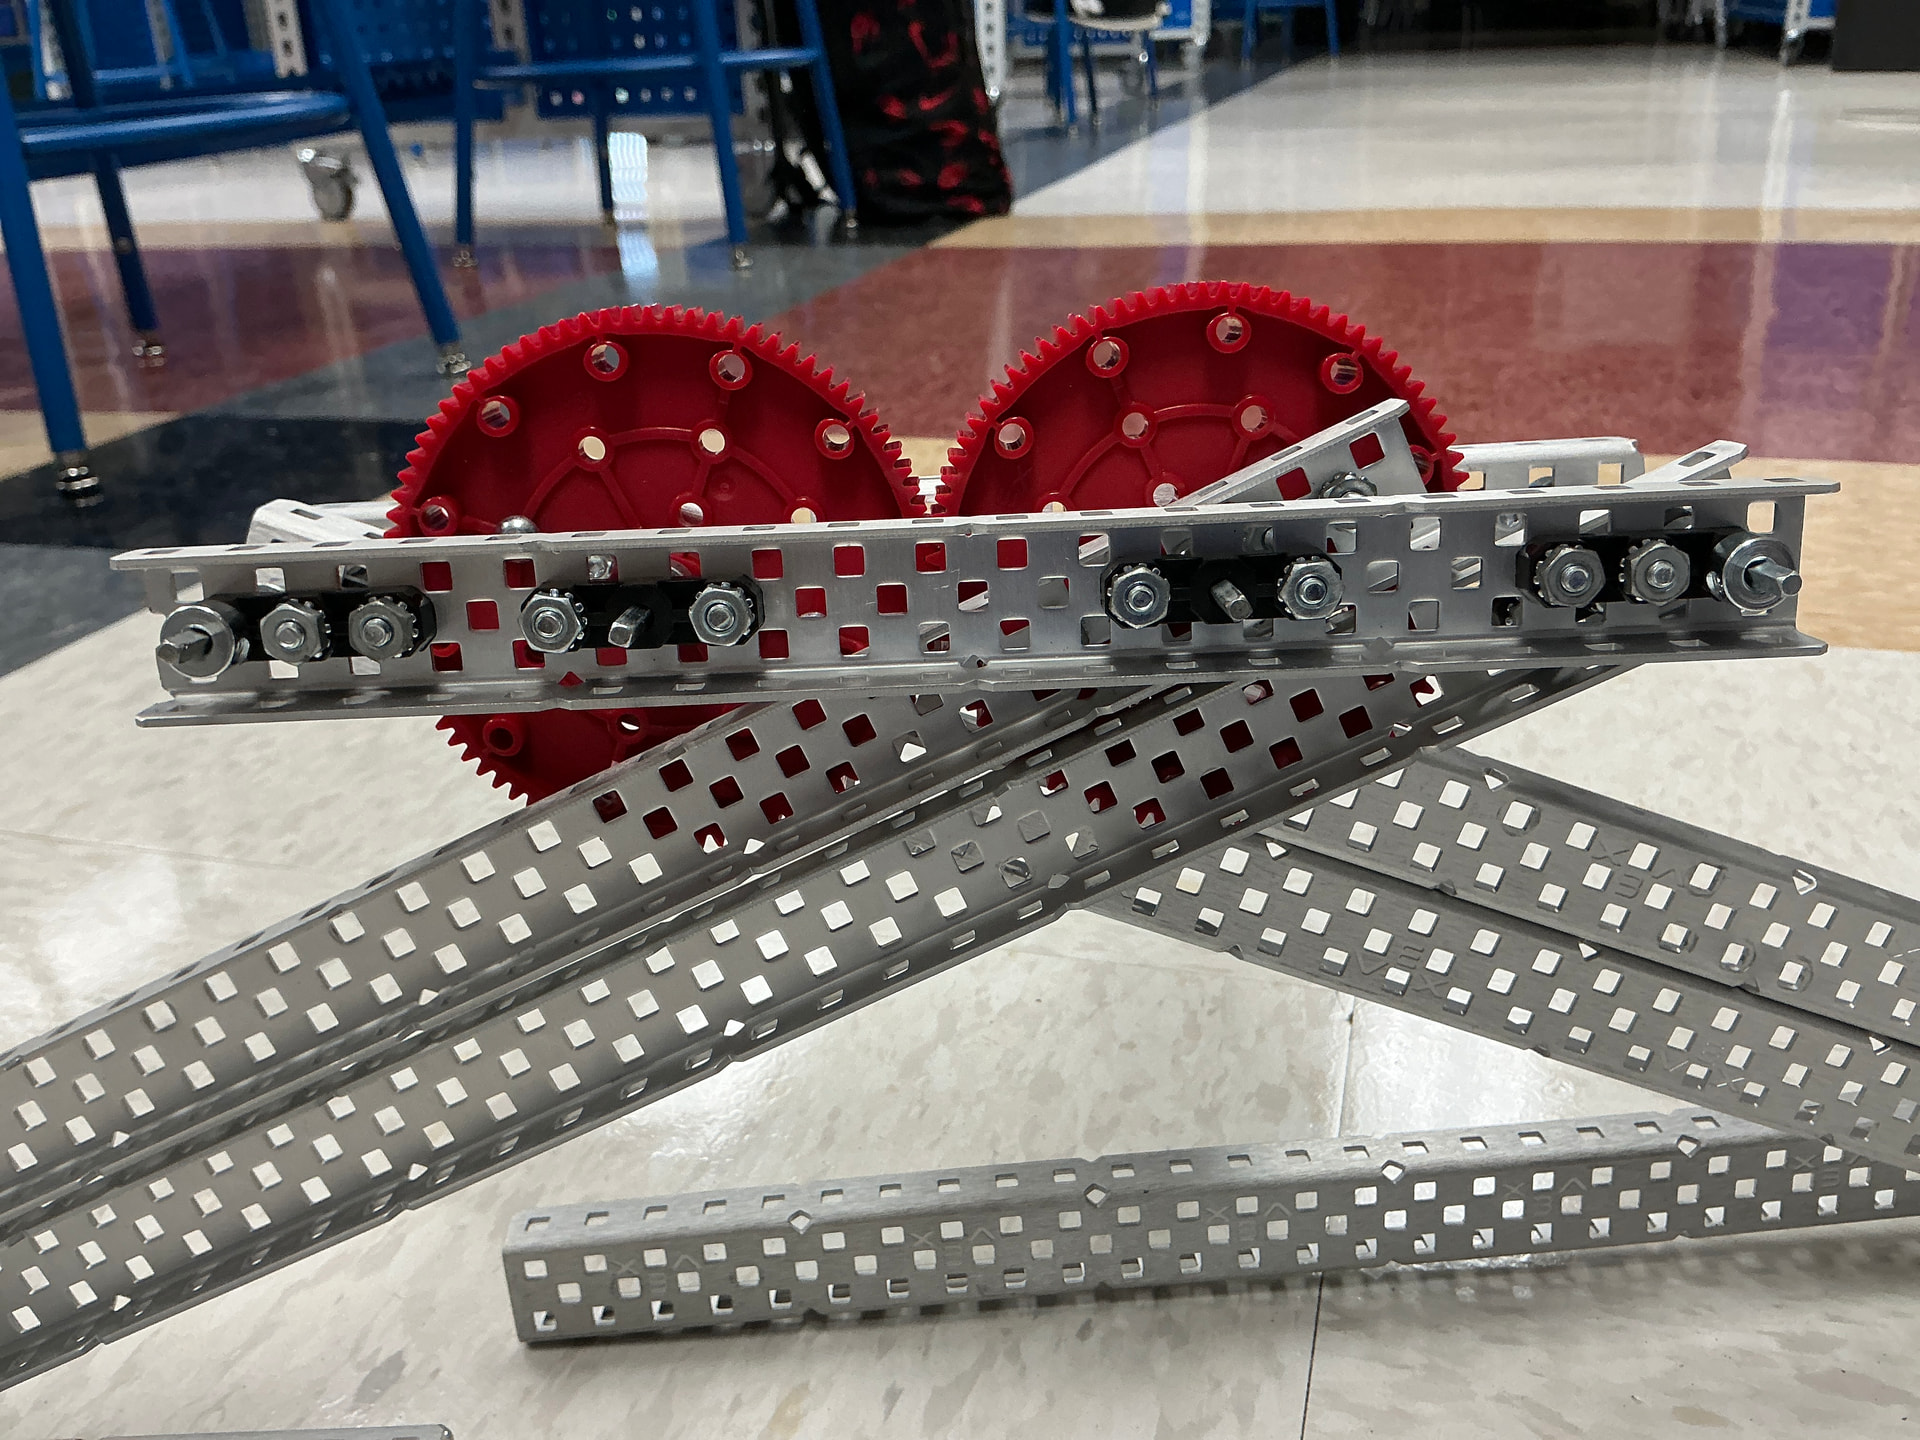
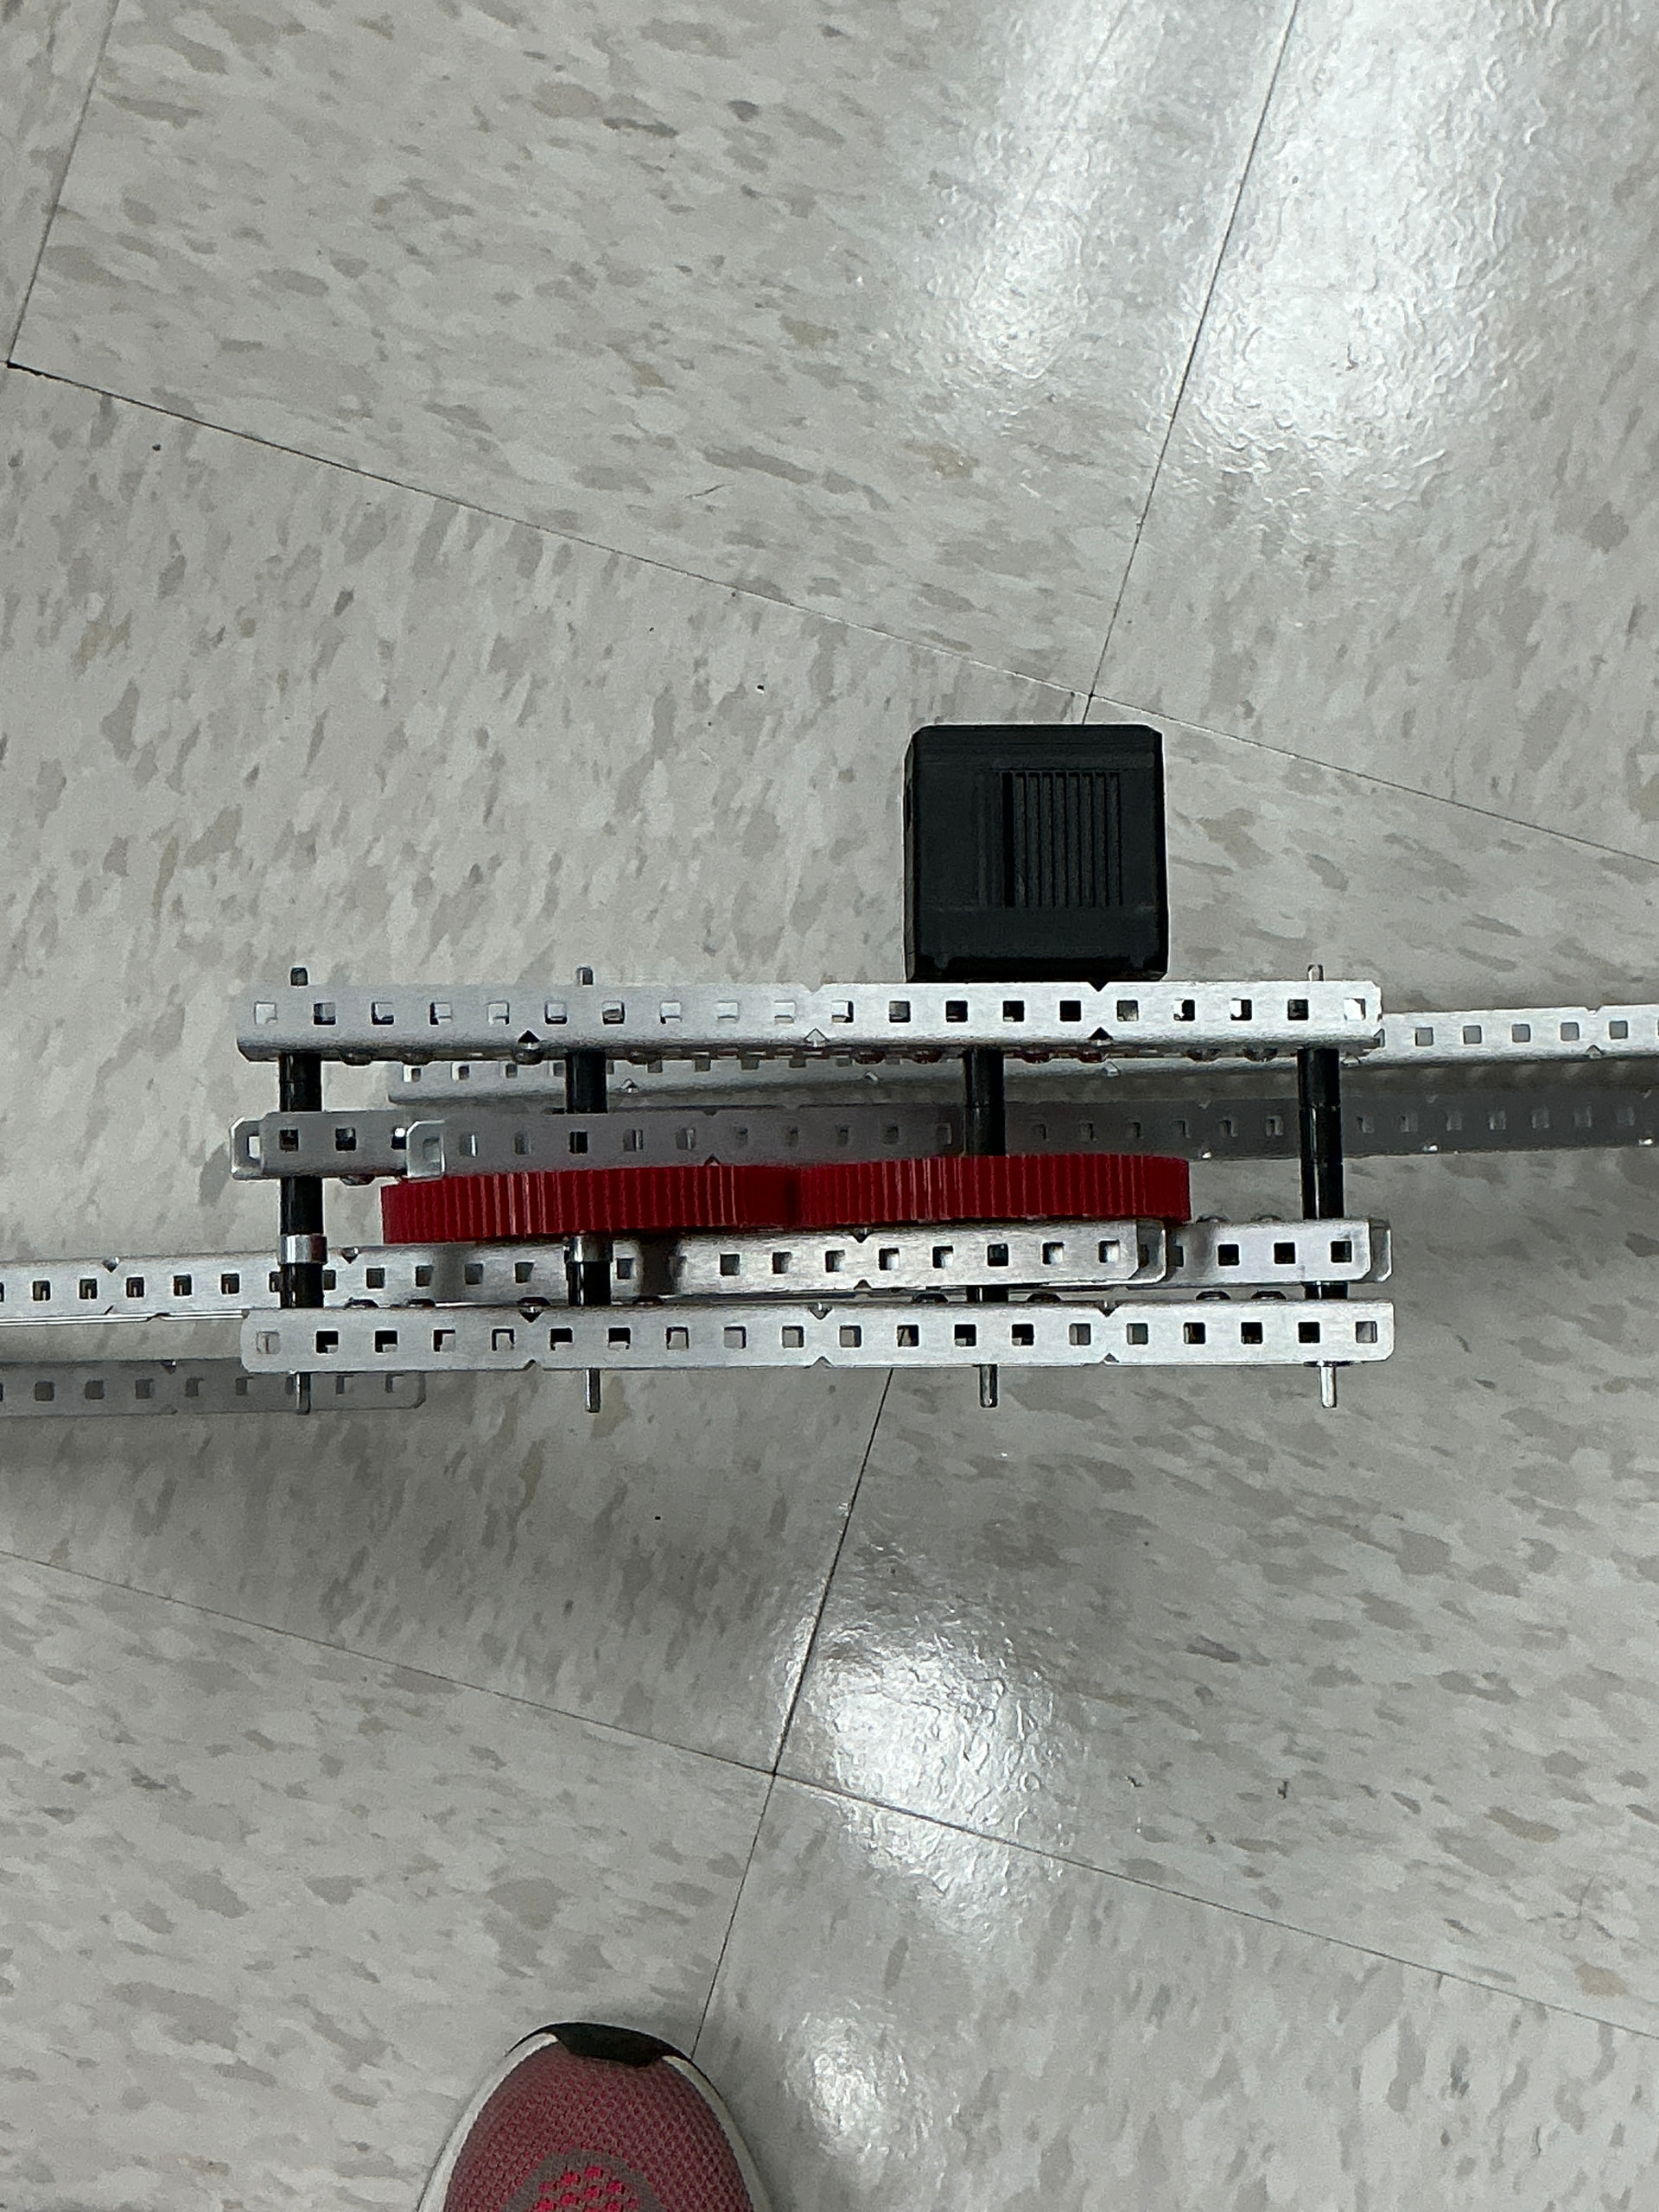
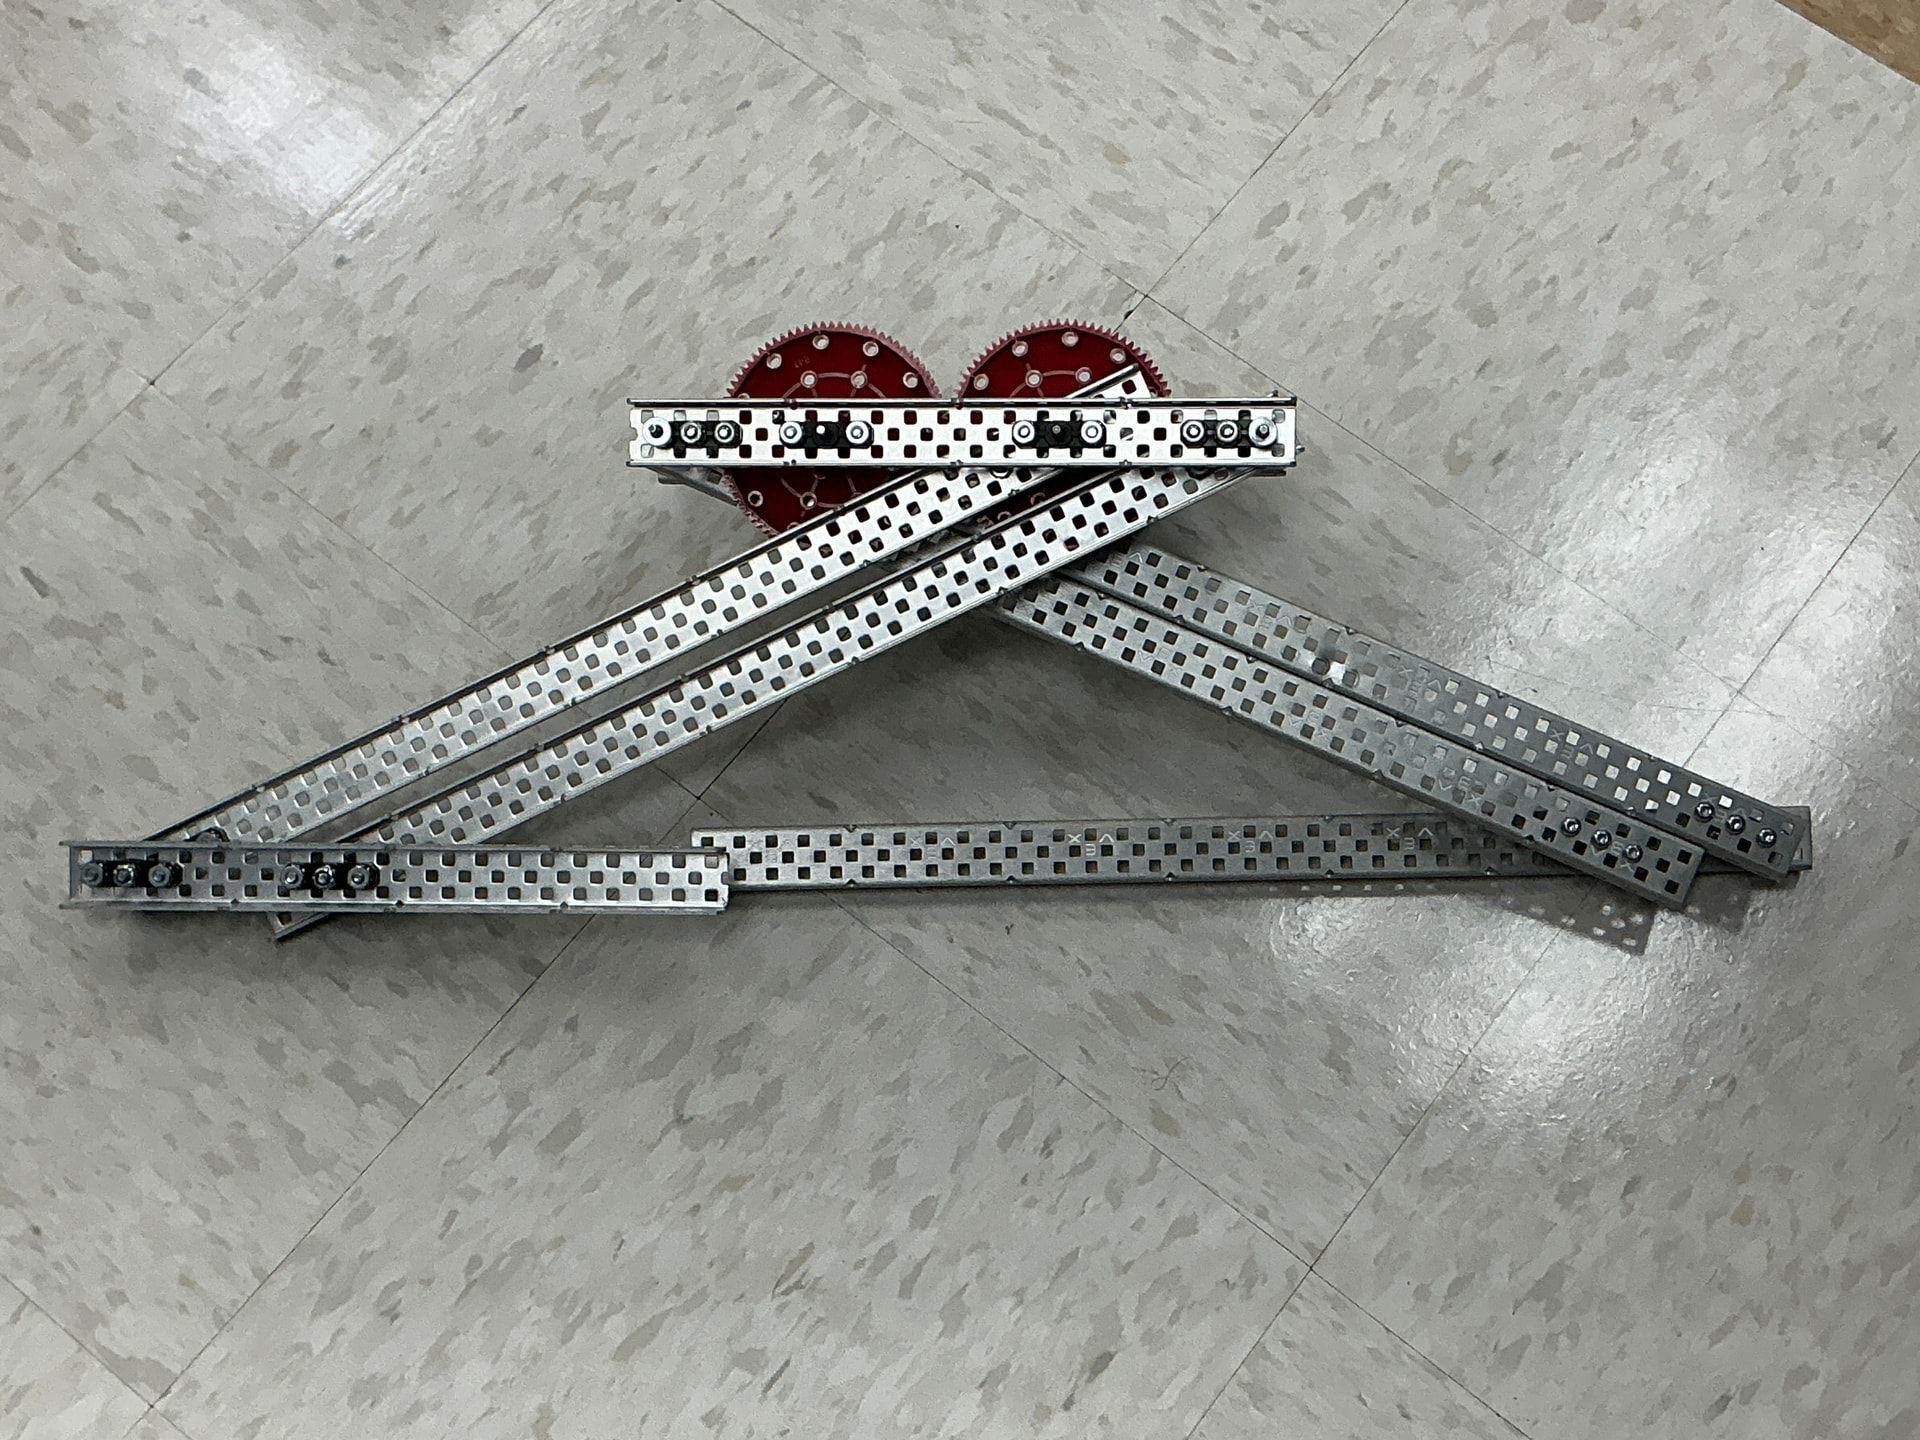
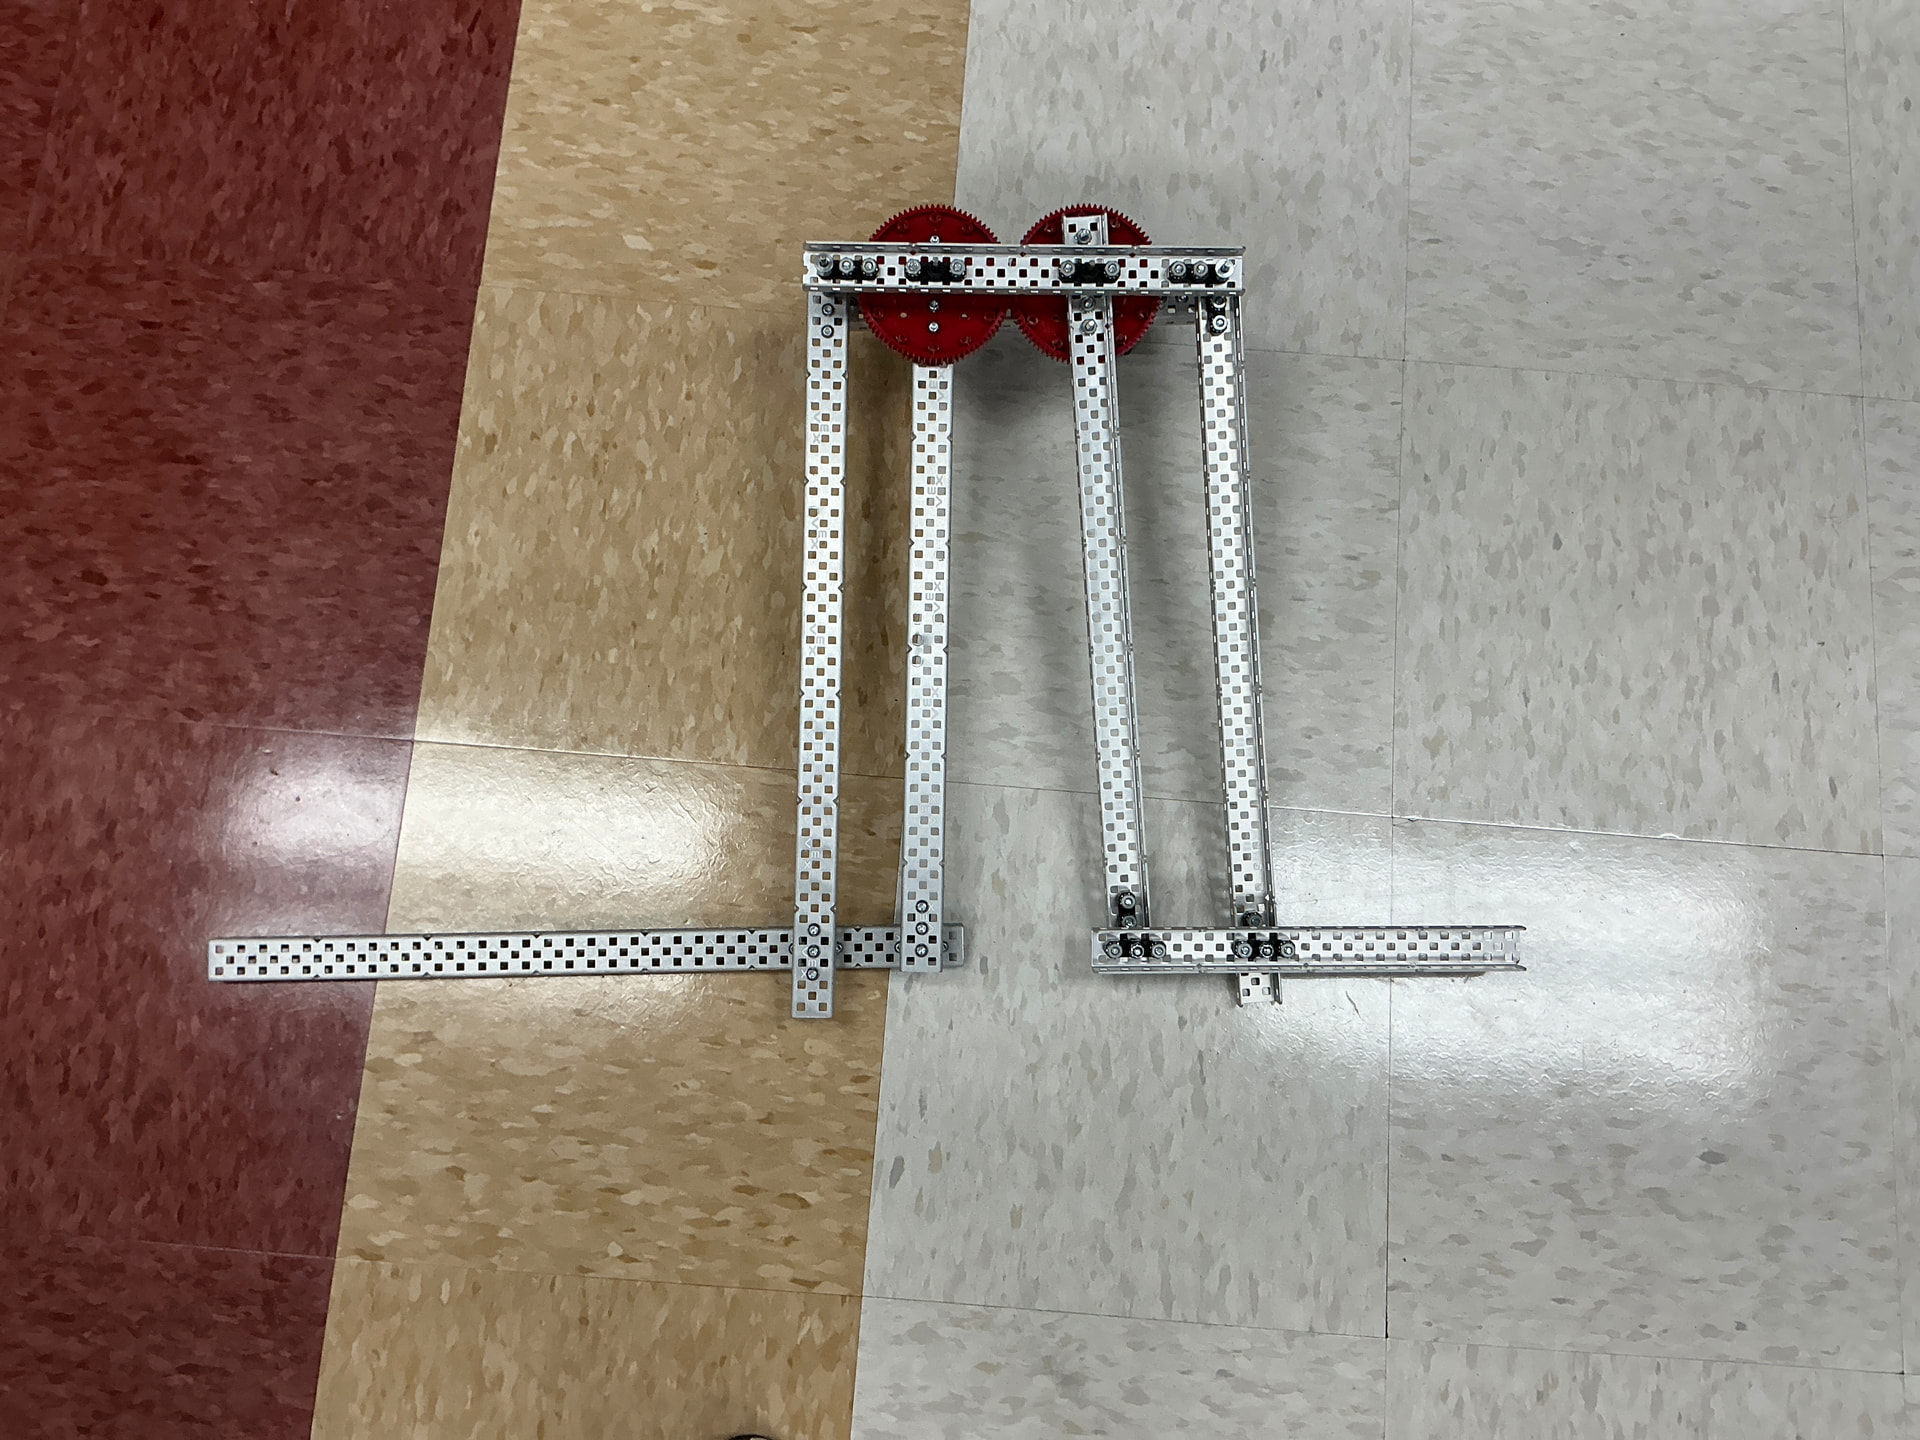
So I just made a DR4B arm and I was wondering if you guys had any feedback and or improvements on this arm for my team. Should we make a second one of this? So yeah. Thanks!
Definitely make a second one on the other side of ur robot or it will get too unstable
One thing I would say is attach the motor to the base. Ik that that is if you have like a heavy thing for the “claw”. But it still works and better wire management.
Did you use Kepler electronics video?
Please use halfcuts on a dr4b or even dr6b because it will save you lots of weight and also I’d recommend having your motor(s) on the bottom for better center of gravity. If possible also use nylon screws for additional weight savings and if you want an optimized dr4b (or dr6b) use standoffs or screw joints on your gears to save weight (if you decide to move the motor to the bottom, but if you leave it at the top i guess it would be fine but watch out for bending on the shaft).
I would use nylon lock nuts to make it stronger.
How would the arm be able to move if the motor is on the bottom?
Also, we were thinking of making a second one.
That increases gear slop so i would recommend it in the middle
I have seen teams use it. Right now I am still trying to make the lift onto the bot.
Yeah built it using that video
Then you have seen him use the method and one thing I would say is to build the motor to the top, I have tried bottom and it is not the best.
Ok. Thanks for all the information!
One more question for you, should I attach a vex claw or make my own claw for weight?
Also, should we use pneumatics instead of motors?
I feel that the vex claws are bulky and a smaller custom polycarbonate claw would be better. And definitely make it pneumatic.
Use motors for the lift. But you can use pneumatics or 5.5 watt motors. If you use a plastic claw, use pneumatics. Make sure you keep the tanks low to the ground.
Should I do a roller arm or a double sided for override?
A double-sided claw would pick up stacks and match load more efficiently while a roller arm is better for picking from intake. So it really depends on your bot design.
I presume you are referring to this - https://youtu.be/xbqURp5oiAc?is=K0xUHnP3C3h_6RsJ
Were probably going to do a regular vex claw that can flip upside down
Should we do pneumatics or motors?