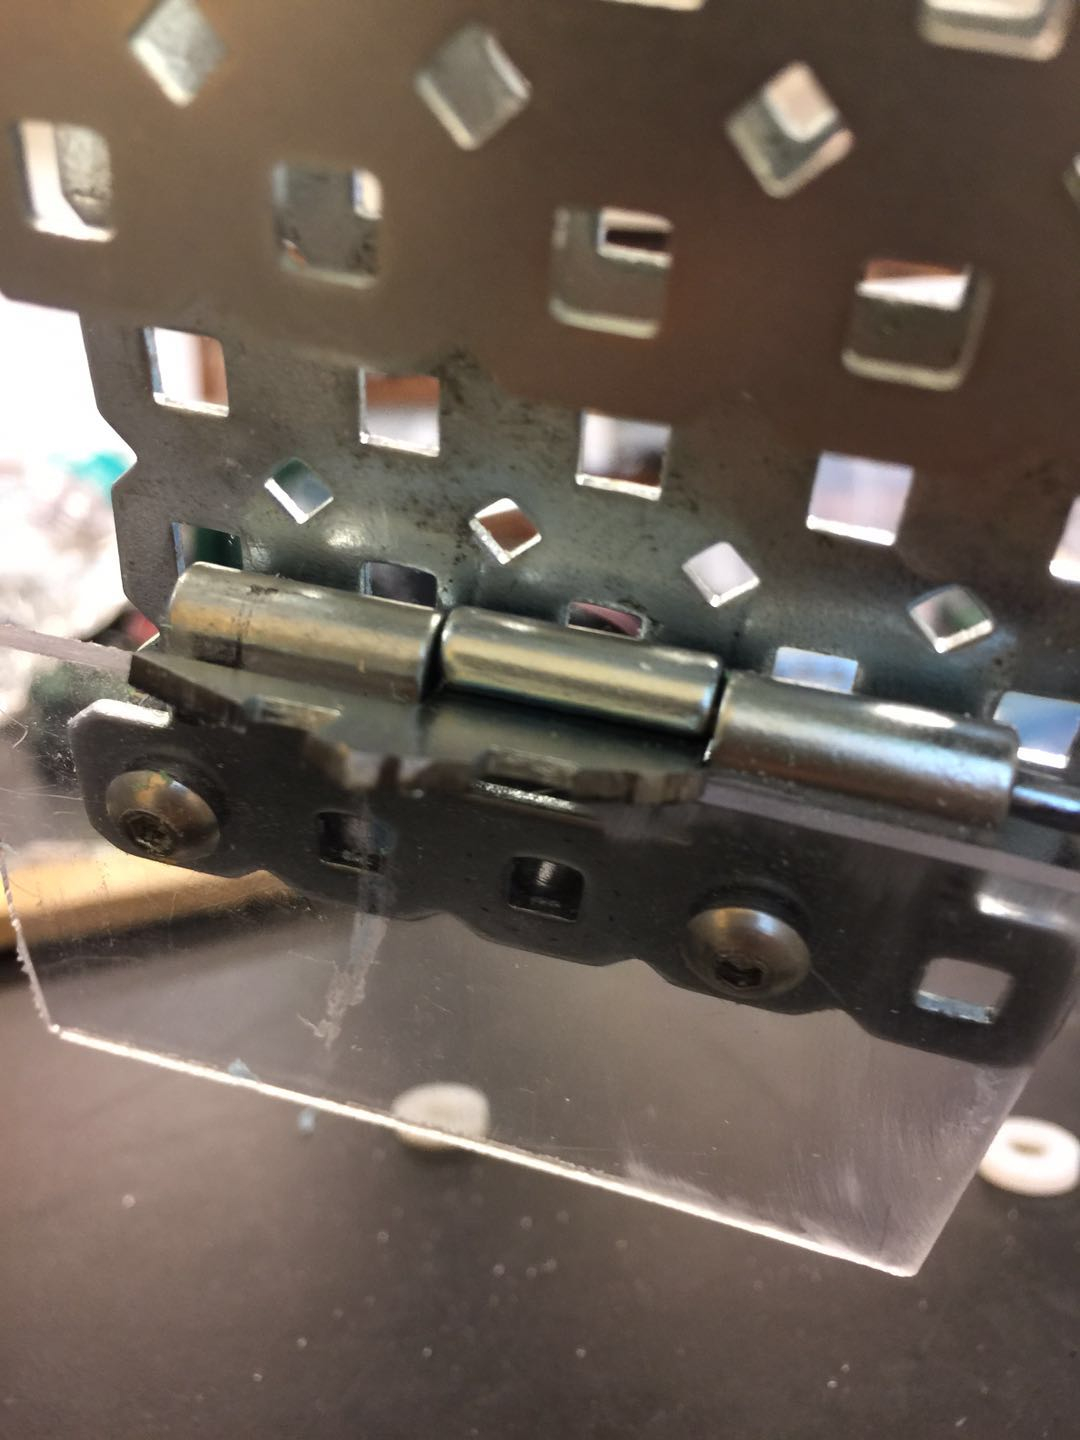
I used hinge to make a hook, when the cube goes into the intake the hook automatically holds it.
ah… clever. Thanks for sharing!
How would you let go of the cubes tho?
I plan to use pneumatic to release the cubes. I’m going to use hinges to connect the two 1x35 c channel to the rest of the intake, so the 1x35 c channels will act as gates that hold the cubes in the intake. When the cylinders retract the “gates” will open, so the cubes can come out.
I find it hard to explain my idea in words, I’ll post another video in a few days.
I feel like the pneumatic penalty is not worth it. You can get more functionality from a motor either through transmissions, or simply controlling the motor’s velocity. You can also get more range of motion and force from a motor, whereas a pneumatic piston is simply release and contract.
Still worth experimenting with though, try and see if there is a way to have a release mechanism with a motor. I’d recommend at looking how some teams used a motor transmission to actuate an angling flywheel hood, their mechanisms were super fast as a double shot had to be within the span of milliseconds. Particularly 9605a did a good job with a transmission for the flywheel hood.
Thanks for the suggestion! I thought about using 1 motor to do the release, but pneumatic is an easier and simpler way to do it. I only need 6 motors for my robot, 4 motors for driving and 2 motors for dr4b lift.
But yes, if I find out I need one more motor for something else, I will use motor instead of pneumatic to do the release.
I have thought a lot a lot about what intake to use and my favorite is an intake using either tank treads or wheels on either side to intake the cubes quickly and then tip them forward to place them. This intake would also be placed on a lift. If on a lift you could tilt the lift so it is perpendicular with the ground and drop it down onto the vertically stacked cubes using the rollers. The idea 81k has revealed as well as others in this thread is a good one (the passive drop thing) except once the cubes are all over the ground it’s hard to grab them. Finally, I know 20 character limit but this I think is very insightful, is that I think that everyone should try to focus on getting the most speed, while also holding a lot of cubes. (4 motor drive 2 motor lift 2 motor intake) Best of luck to everyone in the competition!
If you use a rack gear for your intake you can avoid the pneumatic penalty and have the other motor left over for something you might really need…
I abandoned the pneumatic idea currently since I have a truly passive system working really well.
How are you releasing your cubes if its truly passive? I was going to use a cut gear so I have full motion in a secondary arm and then release with the same motor (also with full movement but only when the arm is all the way out) but if you can passive release that would save a motor, but maybe slower.
soo what are some ideas that use 2 omni wheels?
if you’re asking about using omni wheels as intakes, it doesnt work well. at all. the double rollers mess with the intaking of the cube, and the final placement when ur scoring the stack. ofc we tested this in a traybot situation, but i highly doubt they have any other use as well because of their extra large size.
i meant that if you use omni wheels as a base what are some ideas
sorry, my bad. really, omni wheels should not affect your design too much. the amount of motors u use however will definitely affect which design you go with.