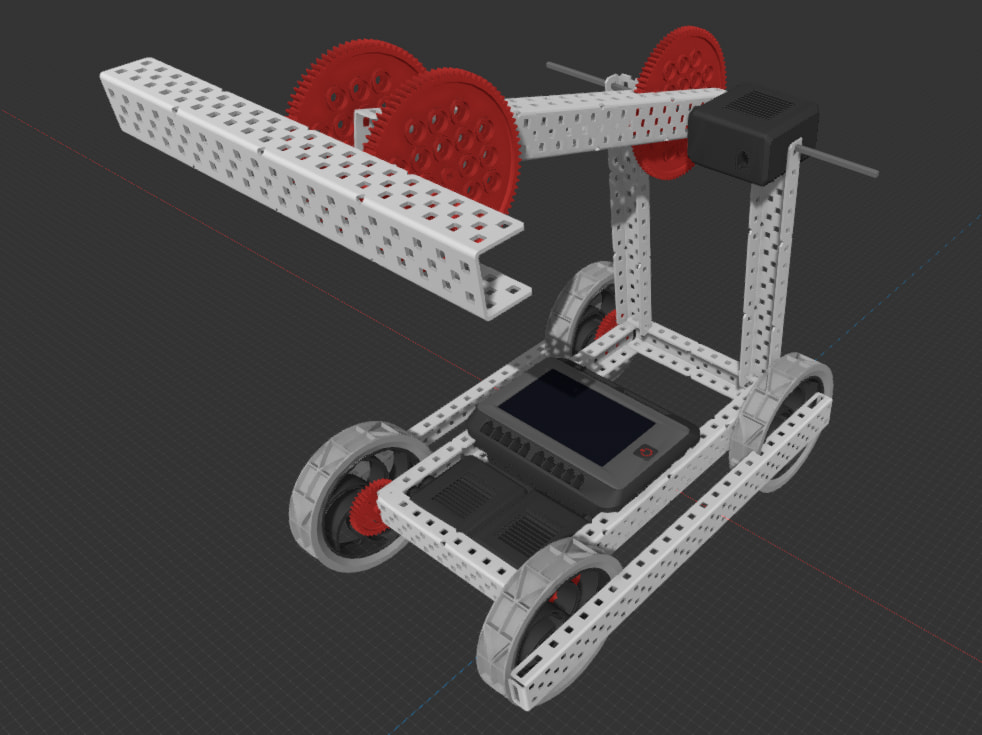
Hey guys! So this is the OS-01 conceptual model on what me and my team are currently working on. We were thinking of trying something that would use a lot of power on attachment motors and less on the drive train to make it have a better structural integrity. Now the bot looks really weird because the gear alignment and screws are slightly or really off but we’ve started a small 3D print build IRL to make sure everything is in order and will be sending it out as soon as possible. The whole goal for this bot is to be balanced between defense and offensive with it’s “high powered hammer grip claw” that can easily pick up pins and cones. We are planning on adding something on the back possibly to activate toggles. The motors are not covered so you can see where they are located but there usually will be a cover to hide electronics probably using a base plate. Sorry if it looks kind of bad my oneshape account is having some errors so I am using protobot temporarily. If you guys have any questions or suggestions please let us know!
Note: Physical Testing has not been done on this bot and design is still being worked on in CAD.