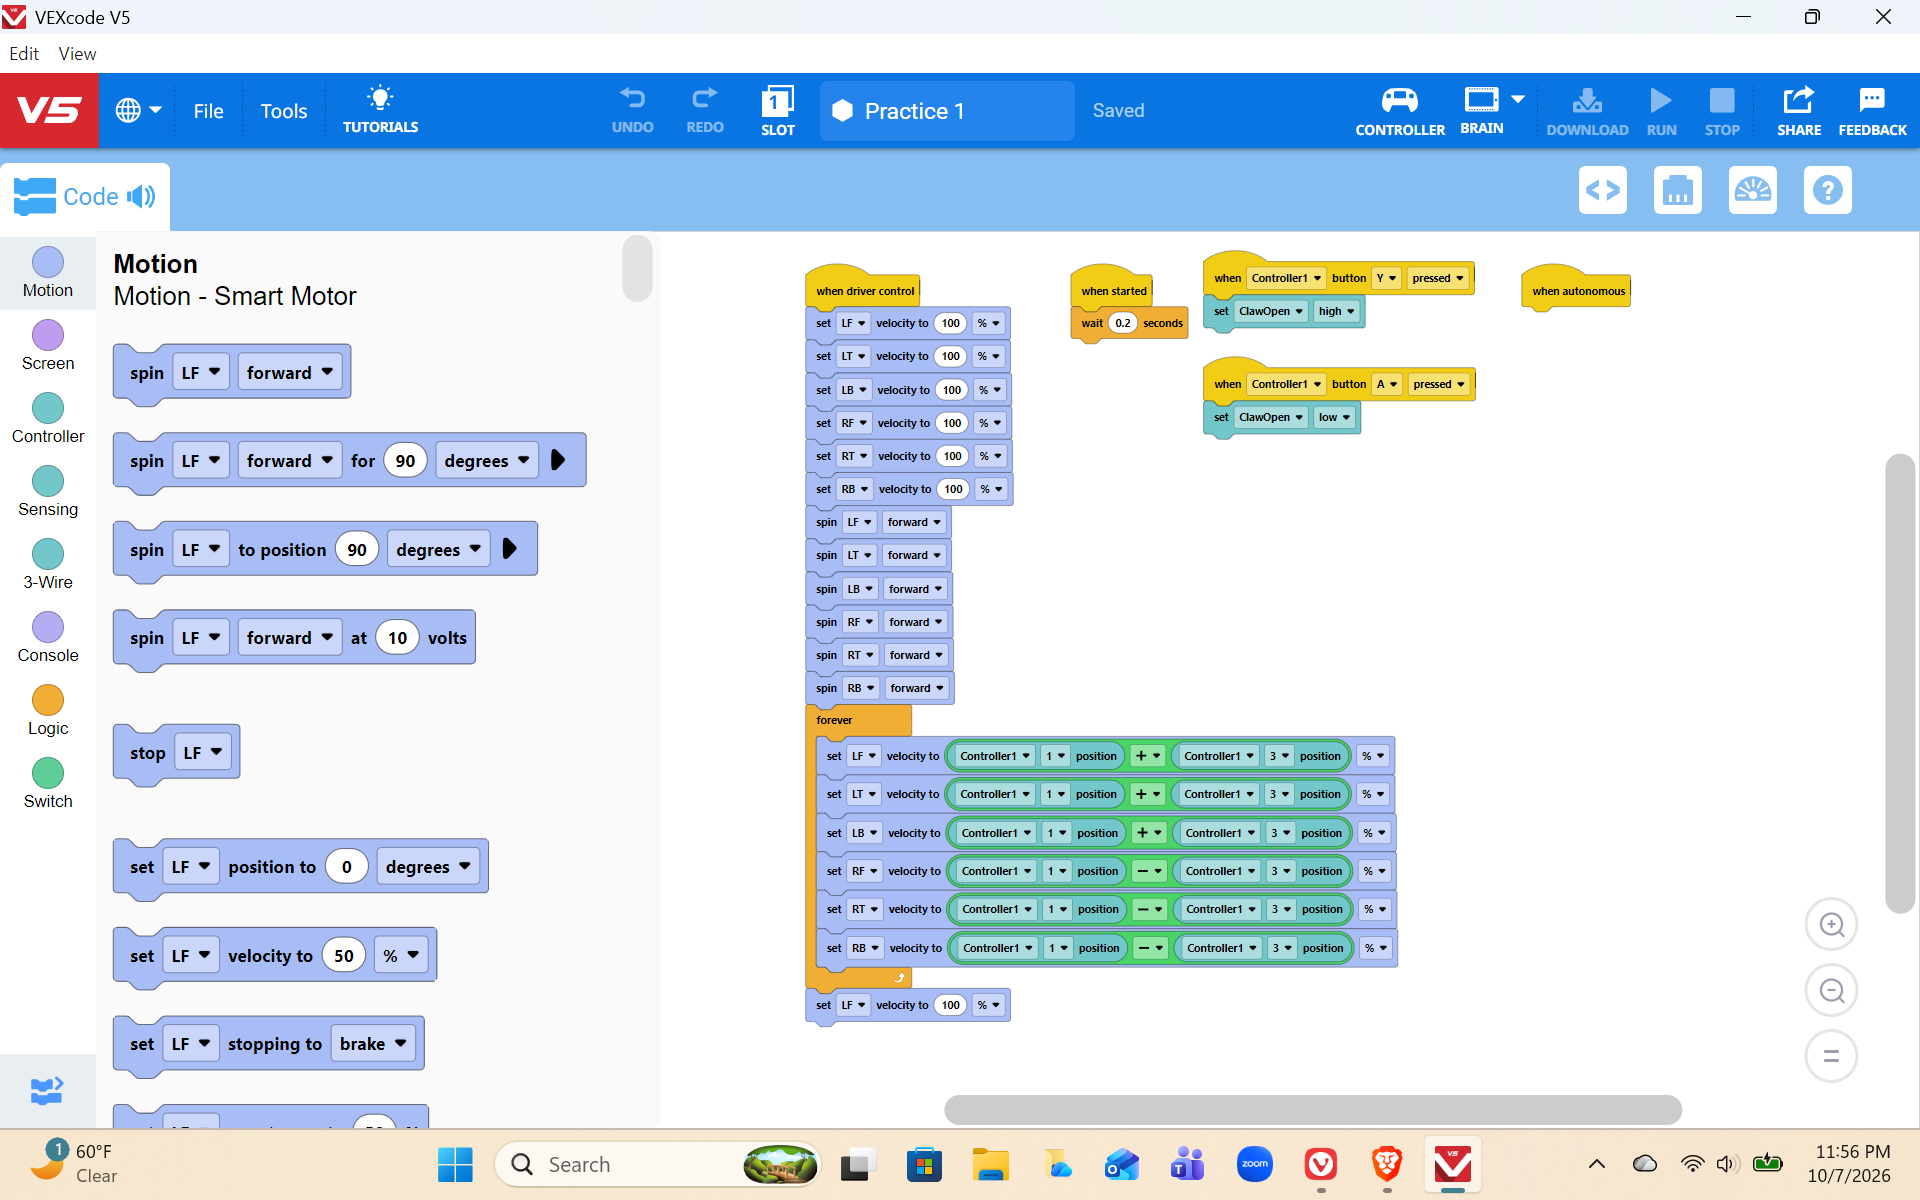
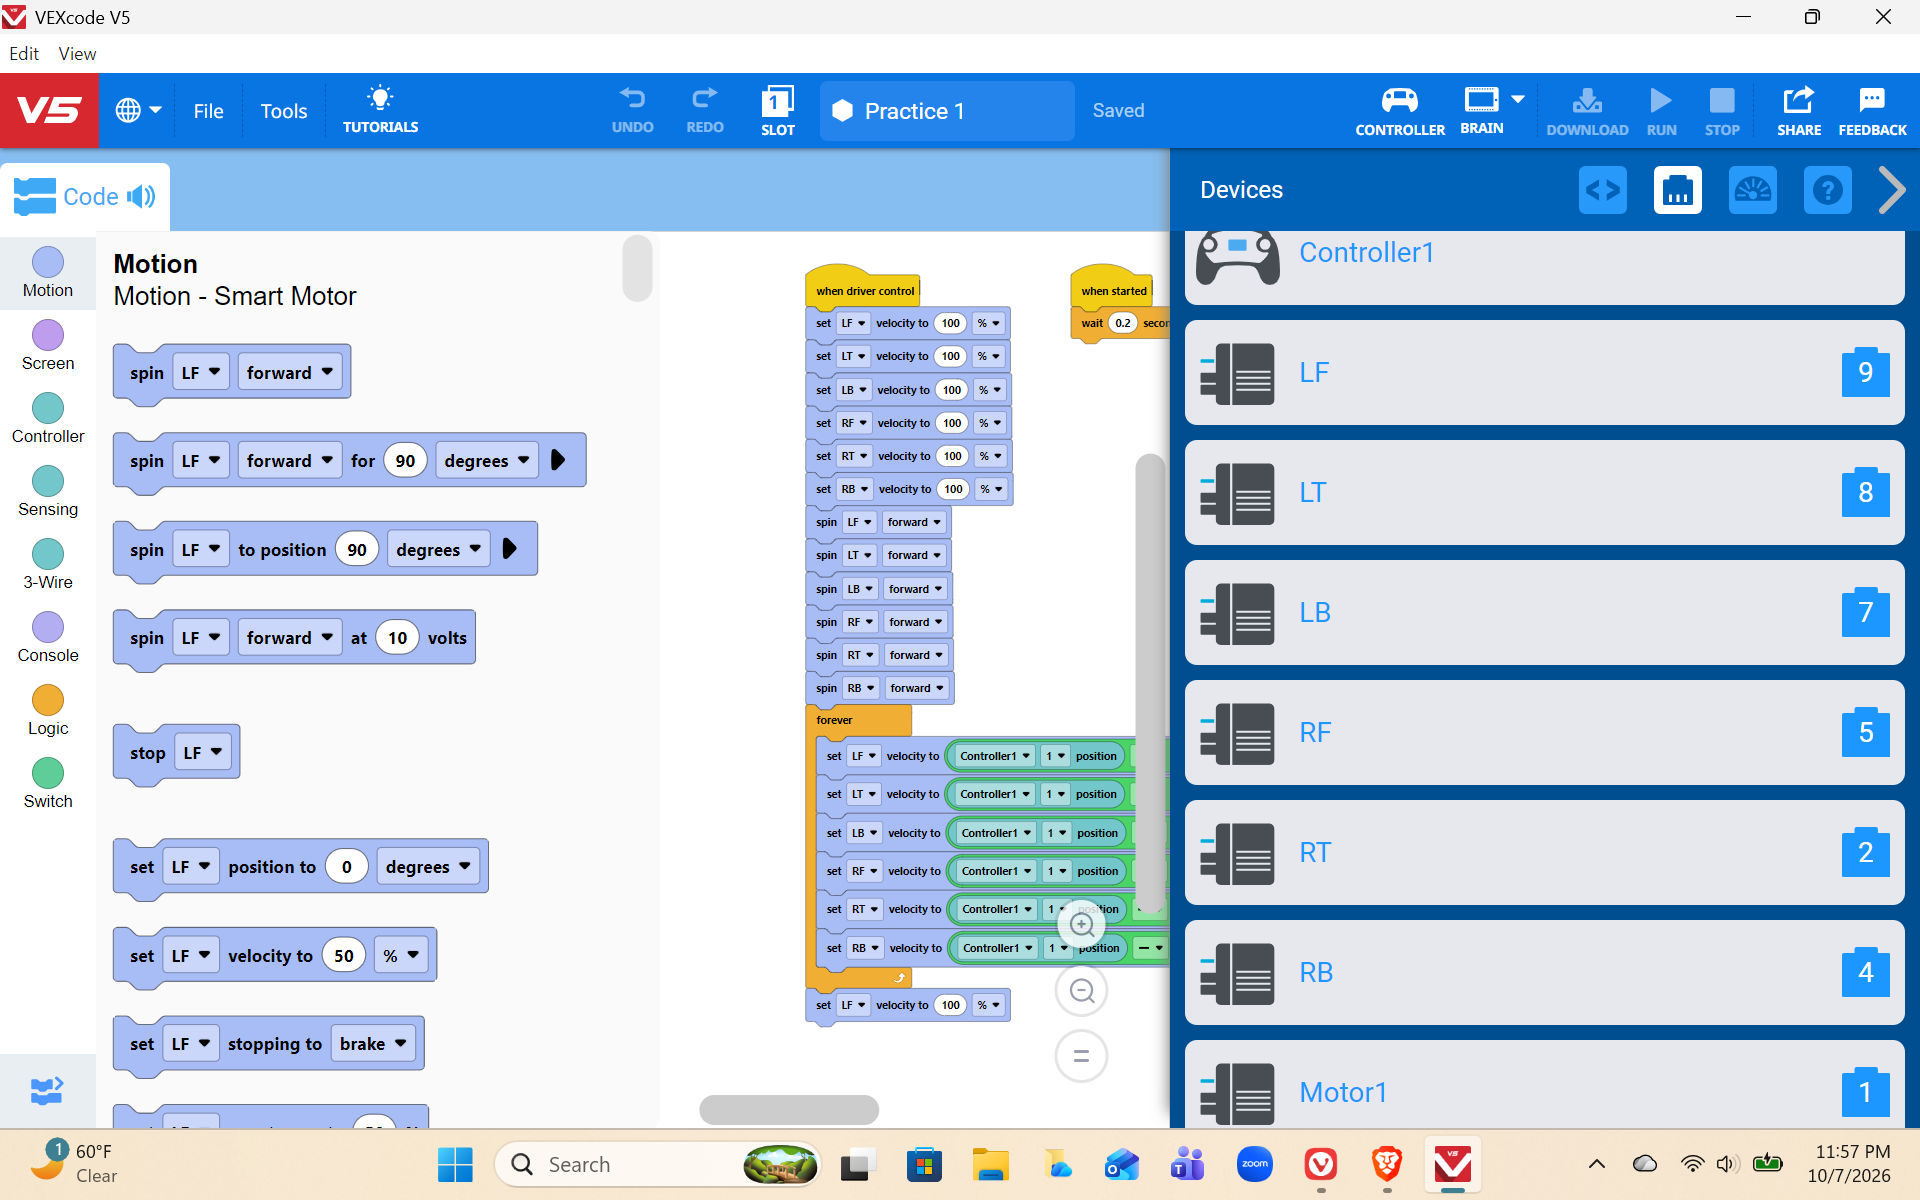
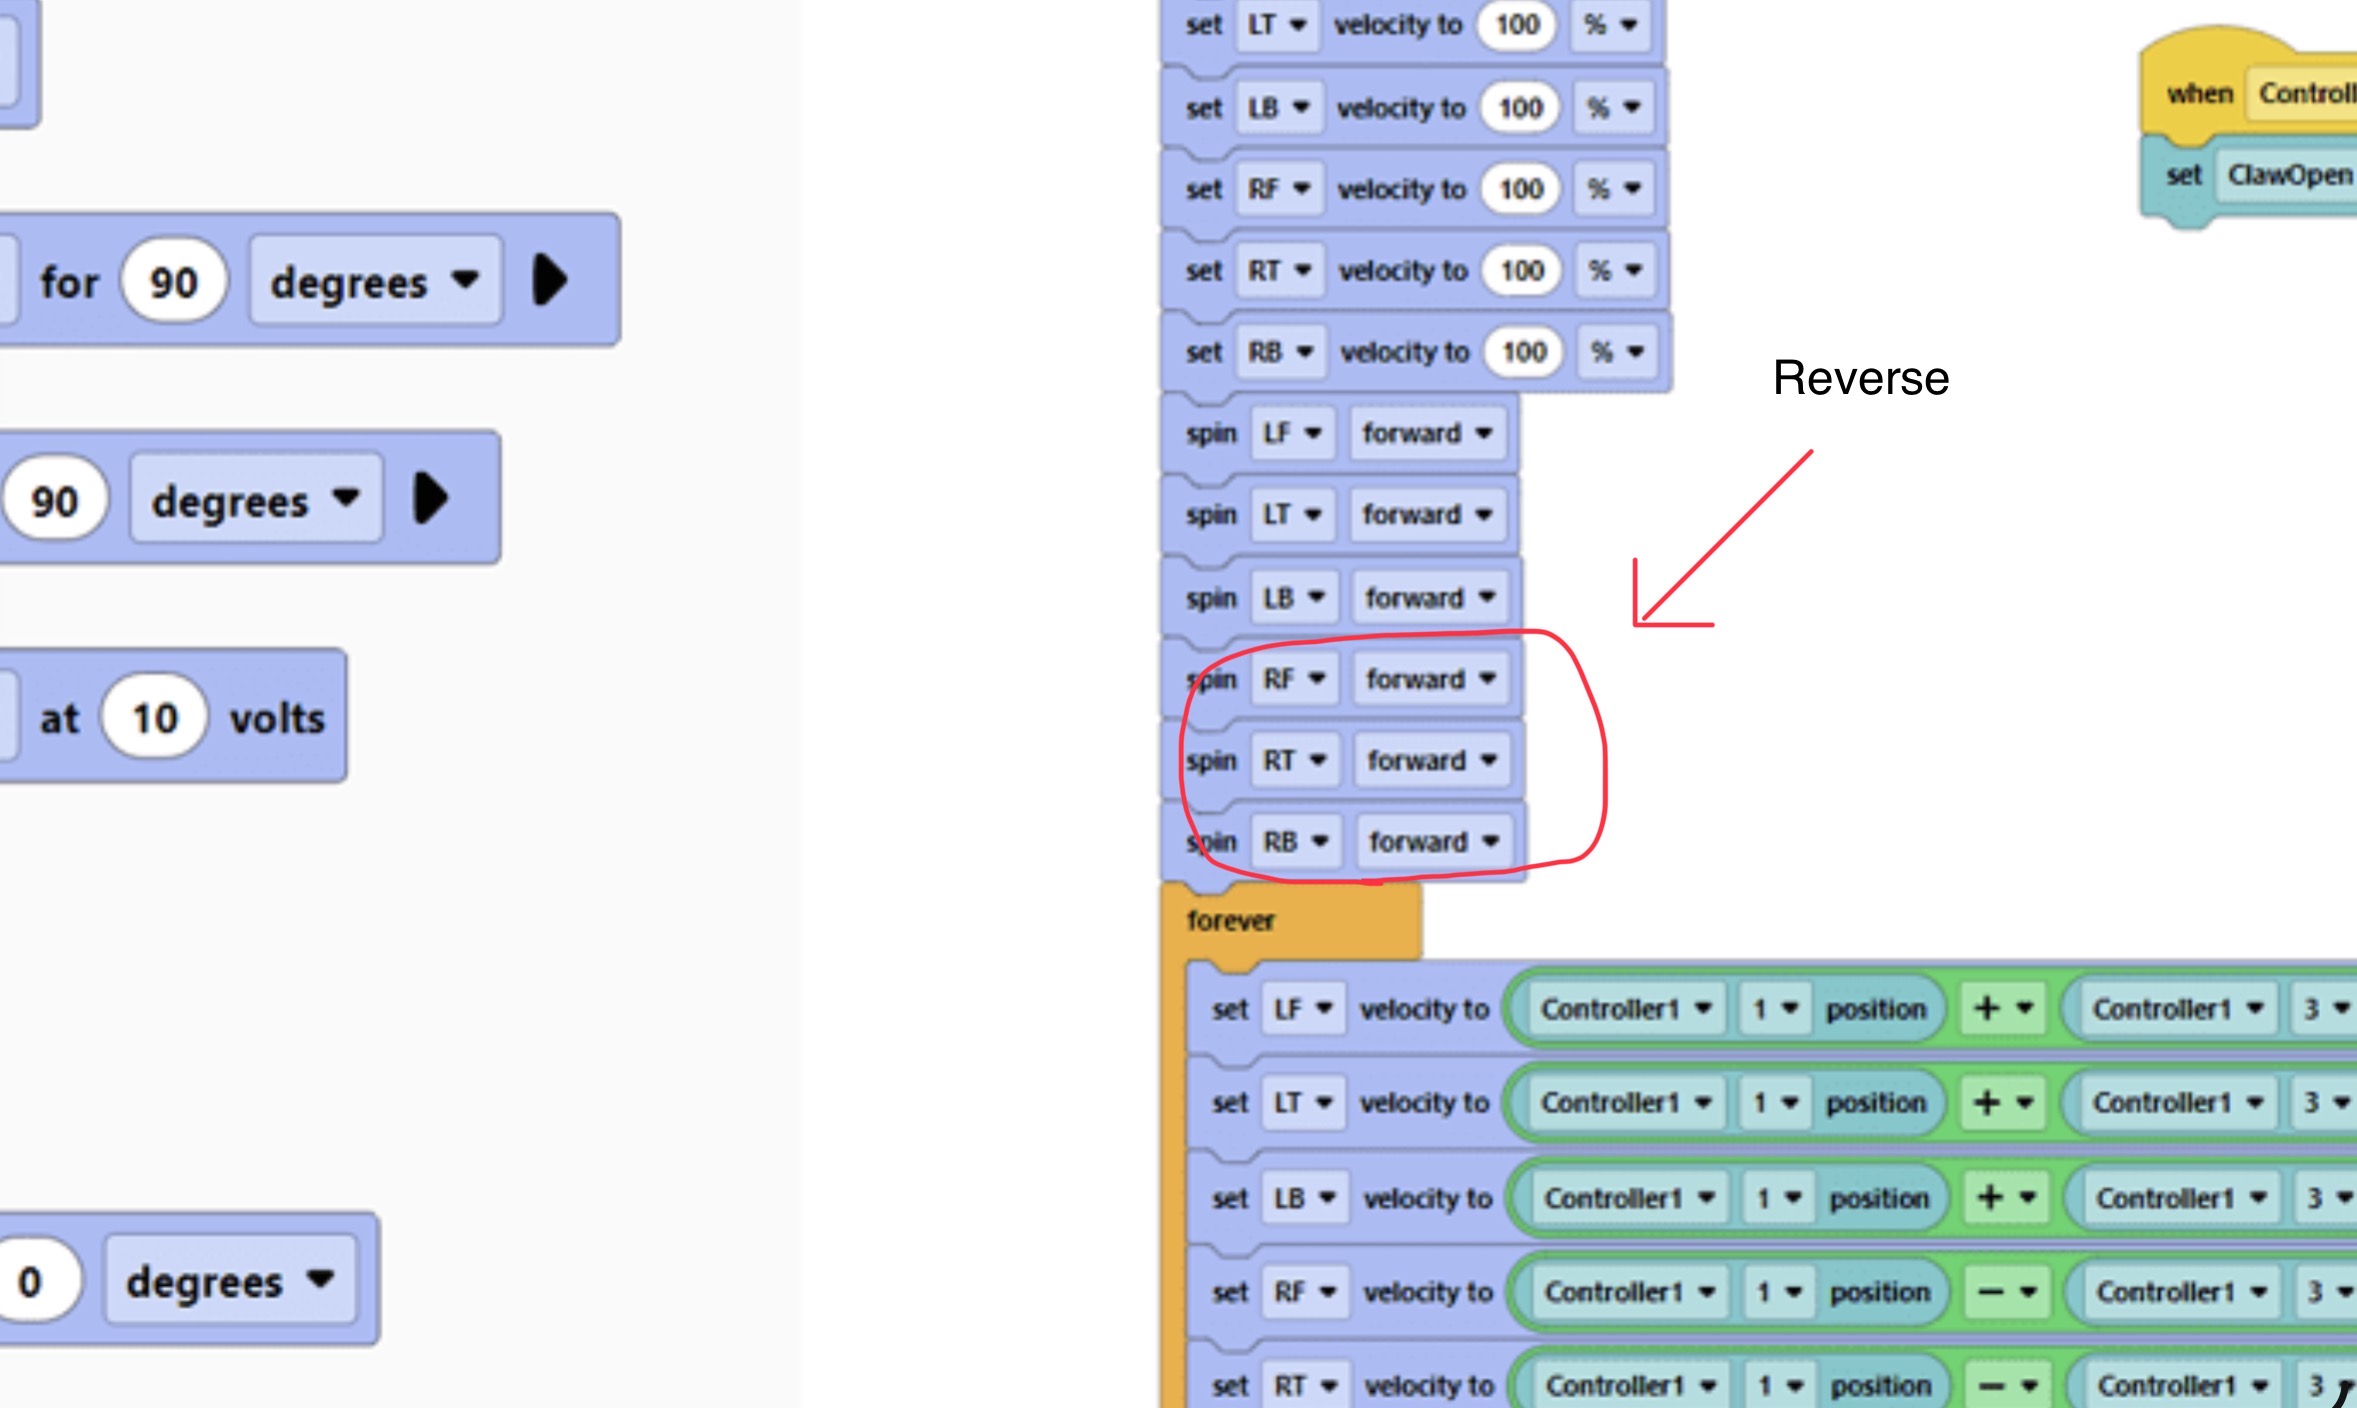
We use a split arcade drive and I have been using the same programming template of it for three years but the controls are currently wrong and I cannot get them to work. Additionally, the program was working until we switched some motors and switched the controller and now it is not. Going forward and back with the left joystick makes the robot turn and going right and left with the right joystick makes the robot go forward and back. I have attached pictures of the program. Each side has a motor in the front and two stacked motors (hence f-front, t-top, and b-bottom in the program). The left top and right front motors are reversed due to their positioning. I have tried reversing all the motors from what they were before, switching 3+1 to 3-1 and vice versa on the program, both at the same time, and nothing will work. (Also I see that I have LF velocity twice on accident, but that can’t be the issue)