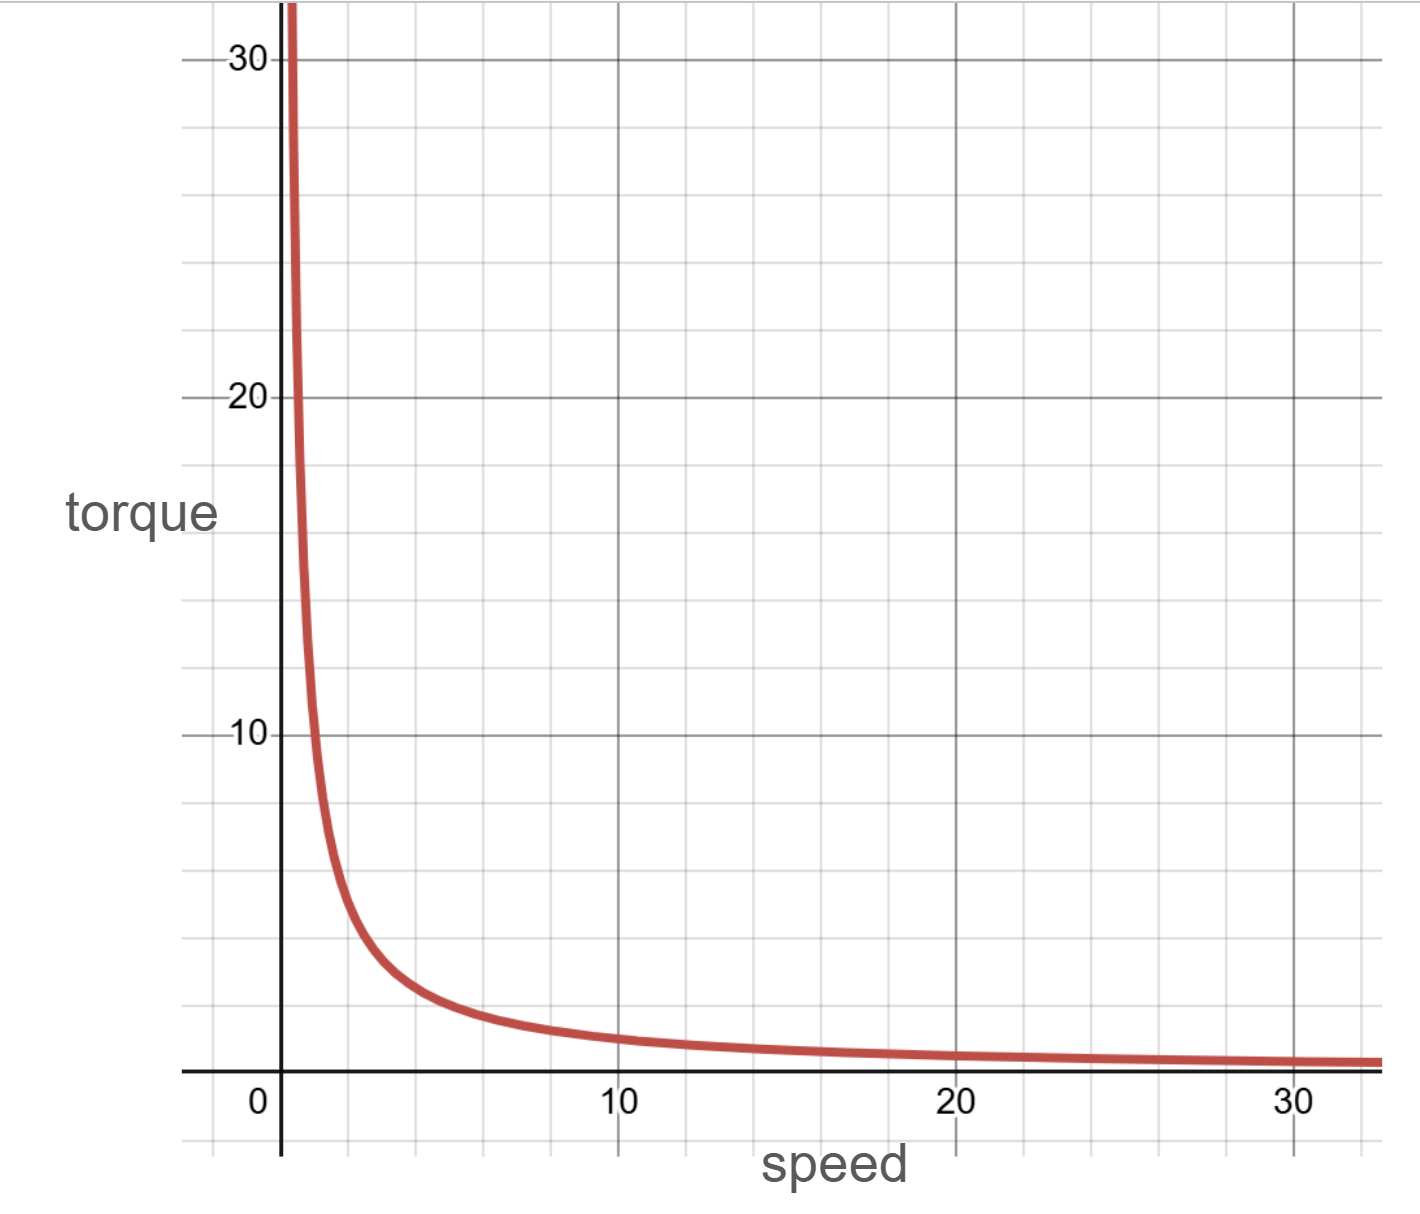
me and my team are trying to find a good balance of speed and torque so our robot doesn’t get pushed around during competition and so we don’t have to sacrifice to much of our speed
The majority of teams I have seen as well as my own do a 450rpm drivetrain on 2.75" wheels, but this needs to be 55W . A lot of other teams do a 360rpm drivetrain on 3.25" wheels instead, so they can have theirs at 44W.