if you have time can someone send the video into this thread by downloading it. I’m interested in seeing what the robot looks like, and how the system works. But youtube doesn’t work in here in China.
EDIT: 720p was too large to upload, you’ll have to settle for 144p 
Here’s a zip (4.0 MB) of the reveal for you and anybody else who needs it.
(Obviously, we prefer if you watch it on YouTube to boost our view count and give us some bragging rights)
It is worth noting there actually can be significant voltage drop over wire lengths. On a 3D printer project, I had to double up the conductors as I would drop significant power over a 8 foot run. I don’t know if this would affect V5 however.
Thanks for providing the video. Although the video made me feel lijke I was in 1985 it was still viewable. When I get back to North America I definitly view it again. Is the maximum size for posting items 5MB?
Is it allowed to have both drivers driving at the same time? And is a third person the driving coach required, in that case how do they execute instructions given to both drive members? How do they determine who is being instructed?
This is probably the wrong place to ask this question, but the back half of it does kinda pertain to the robot.
You can have a drive team of 1, 2, or 3 people. So a coach is not needed. In this case, the “drive coach” would alternate between the two drivers.
In my experience, playing defense on one opponent doesn’t really require a coach to walk you through it. But keeping track of the tether and how much extra distance is available would be difficult whilst driving.
I expect the drive coach for this bot to keep track of all the tethers. It makes the most sense to me, as drovers might forget they have a limited distance, and wrapping around towers to cover opponents could really shorten the tether for the other driver.
To clarify, I was replying to the information which was posted on this thread, by another member. But thanks for the information.
That is literally asking to have your robot destroyed lol. Tower takeover has become battle bots!
I think this is a point worth clarifying - we’re reasonably confident that no legal opponent could, specifically, destroy the wallbot.
This is because of the specific disallowances of robot-destroying mechanisms in the inspection checklist and rules manual. We’ve designed the current bot to handle the vigorous interaction possible from defense-focused opponents, and even that was not enough (see: 315G 6m base with ramps from Turning Point unable to budge the wall).
As of now, I’m still leaving the door open that a legal opponent could circumvent the wallbot, probably through some equally ingenious engineering. Even so, if the fear of losing to a wallbot is so high that teams design custom mechanical solutions into their robots, then I think that’s actually a point for Team WALL-E.
But referees are told to err on the side of the offensive robot. Incidental damage is expected to occur to wallbots. So, theoretically, a team could legally dismantle a wallbot.
Could this be the new meta:
Destroying Things With A Vex Tombstone Combat Robot - YouTube ?
Not what is being said 
We are saying that no vex legal robot has the ability to break the wall(not whether or not breaking it is legal) - such a destructive mechanism would be blocked in inspection. One could build a robot specifically to block the wall, but that detracts from offense(point for us).
I do have an idea for a mechanism that doesn’t detract from offensive capability but can combat walls like yours
Question about the tethers and string: how will you play effective defense if there is a risk of them wrapping around towers themselves? In a matter of seconds in a match all of the cubes and everything else becomes strewn haphazardly around the field.
Now there have been VEX legal robots that have passed inspection and broken wallbots in the past:
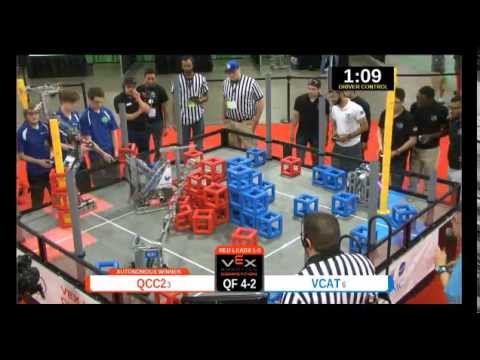
Maybe your wallbot is indestructible 
Brings to mind the Titanic “unsinkable…”
Point heard and acknowledged - I suppose we’ve been a little bold to claim our robot built and tested in 3 days is unbreakable.
Still, I think it’s important to stress that we’ve purposefully subjected the wall to lots of applied force from humans and robots alike and have been unable to materially affect the integrity of the wall. We’ve all watched that exact video very early into our design process and done our best to ensure no such catastrophic failure is possible.^
Obviously, competition is the best and ultimate proof of the wallbot. Lacking that, our intention in the testing we did and the phrasing we’ve used so far has been to remove any easy footholds for the wallbot-naysayers.
I think I can still say with perhaps 95% certainty: No, your normal metabot, or even an aggressively defensive variant, is not going to be able to break through our wall.
And if you design a robot that has some extra mechanisms to beat a wall, then the fact that such design work was necessary in the first place counts as a win to me 
^ Some quick notes on that wallbot vs ours. I think one of the biggest differences is the direction of the force being applied. VCAT had to try and keep 2 robots IN a corner, while we are keeping 2 robots OUT of a corner. Our walls are heavy enough that they’re very difficult to move even just on the field tiles; even if you can push them across the tile, they subsequently press against the field perimeter and then are virtually impossible to dislodge. We are also using a robust scissor design for the long wall, which I think is generally agreed to be much stronger than the linear slider design.
Can you hook onto the wall and pull it away from the goal zones?
Could you, as in “is it theoretically and legally possible” - yes. I think it would technically be grappling against a normal robot, but I’m voluntarily ceding that protection because this is a purely defensive robot.
Can you, as in “can an actual VRC robot do that” - no, unless perhaps you built an 8m tow truck for that explicit purpose.
Even then, we’ve got an ace (actually 2) up our sleeve. If it ever seems like you are intent on dislodging a wall, the basebots can be sent with the goal of pushing you into submission. The 100rpm 3.25" X drive bot is particularly torquey and probably a good deterrent for this kind of maneuver.
I want to consider the rope and wire tethers separately.
For the rope, its current state is ~25’ for each wall. The drums to dispense the rope also offer virtually no resistance to unspooling. Even if the rope gets wound up a ton between the bases of the towers etc., I think it’s safe to say there will be no length limitation. In our testing, in part because the rope is so loosely dispensed, it doesn’t really bind around anything in the first place. Perhaps a cleverer solution would be to put a drum on each side of the rope tether, so that the robot can never be inhibited and the wall can never be yanked out.
For the wire, the comparatively short length means this actually is a valid concern. The cop-out answer is “good driving” and a careful initial deploy to line the wire up with the auton line in the center of the field. With a 16’ tether, this gives us enough room to have at least one robot at every part of the field quickly - the other robot can “unwind” the tether and follow if necessary.
Couple closing notes:
- Chaos caused by the tethers is probably a win for this robot. We will deploy and drive primarily on the opponent’s half of the field, and knocking cubes around in unpredictable ways hopefully makes it harder to conspire against us.
- There is, I suppose, a concern that tether getting tightly wound around a tower might seem like an illegal grapple of the field elements. However, there’s no strategic intent behind this and so I don’t think we would be called out for G16. Of course, it’s virtually impossible to get that kind of tight wind up in the first place.
- Someone above suggested that the drive coach for this robot could keep watch on the tether state during the match. I don’t think our ri3d team discussed drive team roles much beyond dual driver, but I think this would be a great idea and likely a very useful allocation of drive team resources.
What is the like black coil cord? How can we get some of that?
Hope you have lots of spare wire and string…