Maybe I should have made it clearer… I was referring to the 6 teams that were in the finals. And yes, among that 6 wonderful teams, there is only 1 team that has secured or confirmed their spot for Worlds… and it is as the Excellence Award winner (for MS) - 8066X.
What it means is that - there is no guarantee that the tournament champ will qualify for worlds.
Last season, Singapore was only given 1 HS and 3 MS spots.
This season, there is no confirmation yet… in fact, there might even be a dropped from 4 to 3 spots.
And this also means that currently, we can only confirmed that the 2 Excellence Award winners for HS and MS have qualified.
I totally understand the rationale of working to increase the growth of the programme to earn more spots, etc… but just hope the RECF/IFI will not just look solely at the growth rate thats all… I mean - surely the strength of the region should matters as well.
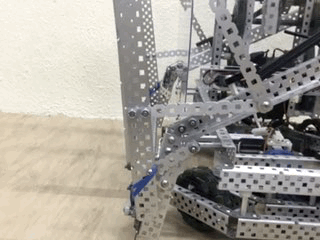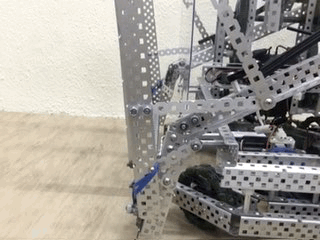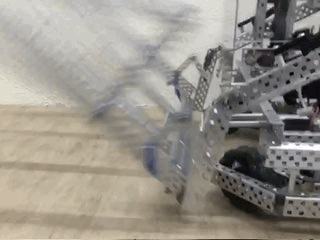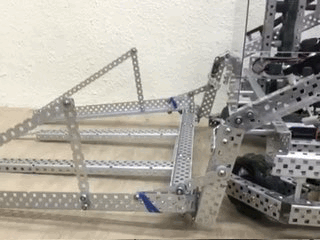
The flip-down tray is connected to the arm by hinges, while rubber bands are used to make the tray fall down. At the start of every match, the tray is carefully folded up, such that a tiny jerk of the robot will cause it to flip down.
Thanks. I just have a follow-up question. How does the hinge lock when falling down, because it doesn’t seem as though your forklift is wobbling when lifting things.
We have 2 bars that are pivoted together at each side (4 in total) that acts as a one-way gate, with 1 end connected to the tray and the other end connected to the arm. As the 2 bars are connected to each other using a loose rubber nut, they are able to be folded up. Once the tray falls down, the 2 bars will extend and lock in place, preventing the tray from folding back in.
After watching a few videos of your robots dumping have you ever considered getting rid of the launcher bit and using those motors to speed up your dumping mechanism? I’ve noticed even with the setup in the video you can sometimes get stars and cubes into the far zone by dumping. I think if you used those motors to speed it up you could get stars and cubes into the far zone considerably more often and more consistently. It’s just an observation I’ve made that an 8 motor lift geared for more speed than currently used could be faster and more efficient than picking up game objected one at a time to get them into the far zone.
Thanks for your suggestions.
And good observations
We certainly notice that currently, the stars and cubes may or may not end up in the far zone.
But it is not due to the number of motors used. It is the angle of delivery (or dumping), which requires a bit of adjustment.
And no… the catapult is not the main scoring mechanism. The usual tray intake is still the main.
But the catapult has its advantages, eg. it can definitely shoot the star across (during autonomous) faster than a normal dumper, and this also mean it is very good in disrupting the opponents’ autonomous program.
And further into the season, when there are robots that hang during autonomous, you can also throw a star all the way to the corner, either to stop the robot from hanging or to make it difficult for the robot to unhang.
And all said - 8059 series have always been bringing totally new robot designs (from SingVex) for the worlds
At the moment we are still doing our “R&D” and deciding on the best options for worlds (and yes, removing the catapult is one of those possible options mentioned by my students)
I agree with Kevin; cutting the catapult and overhauling the dumper is a viable option. Have you thought about using a slip gear for it? You could use something like a nautilus gear or a ratcheting mechanism… I’m not completely sure how you could do it but I know you can while keeping the intake prongs near the ground at all times except launch. I’ll put some more thought into it. Good luck this year. I can’t wait for school to start up here in the west so I can get building.
Also, what was the inspiration for the name “Blank”?
The strength of this robot are the versatility (being a hybrid) and getting the stars off the fence during autonomous faster than most dumpers.
But as i mentioned, it is far from being the finished article.
Eg. If the team is able to cut the 4-motor catapult to 2 motors (and use them for hanging) and improve on the intake, think it will be pretty formidable
And really… dumpers is so common and boring… we have 5 of them (in various combinations) in our lab
Blank. = means we start every robot in a clean slate… originality and creativity.
Well… actually it started off as a mistake by an organiser
The dumper? I don’t see one but I could be totally incorrect with how well some teams can hide things. I was saying to turn dumper into a large version of the catapult. But add some sort of mechanism to keep the prongs down until launch so you can use a slip gear setup to store power and then the whole arm shoots. This would completely eliminate the catapult. But then again, you are right; dumpers are too common.
Sorry… I thought you were referring to the catapult.
You are right - the dumper is currently just a 4-motor reverse dump tray.
Well… We did have a 4-motor, slip-gear, small little tray dumper. But it is not working well, it can hardly shoot 2 stars across
But we are definitely looking into it