I already figured out the solution at the top and I’m mostly memen right now
Noted
Then I highly recommend you mark your solution as such to prevent further confusion. There may be newer teams reading this and getting all the wrong ideas about structural integrity when it comes to VRC drivetrains.
Normie, Moving is overrated
Go to the top and look at the solution it’s the 1st comment
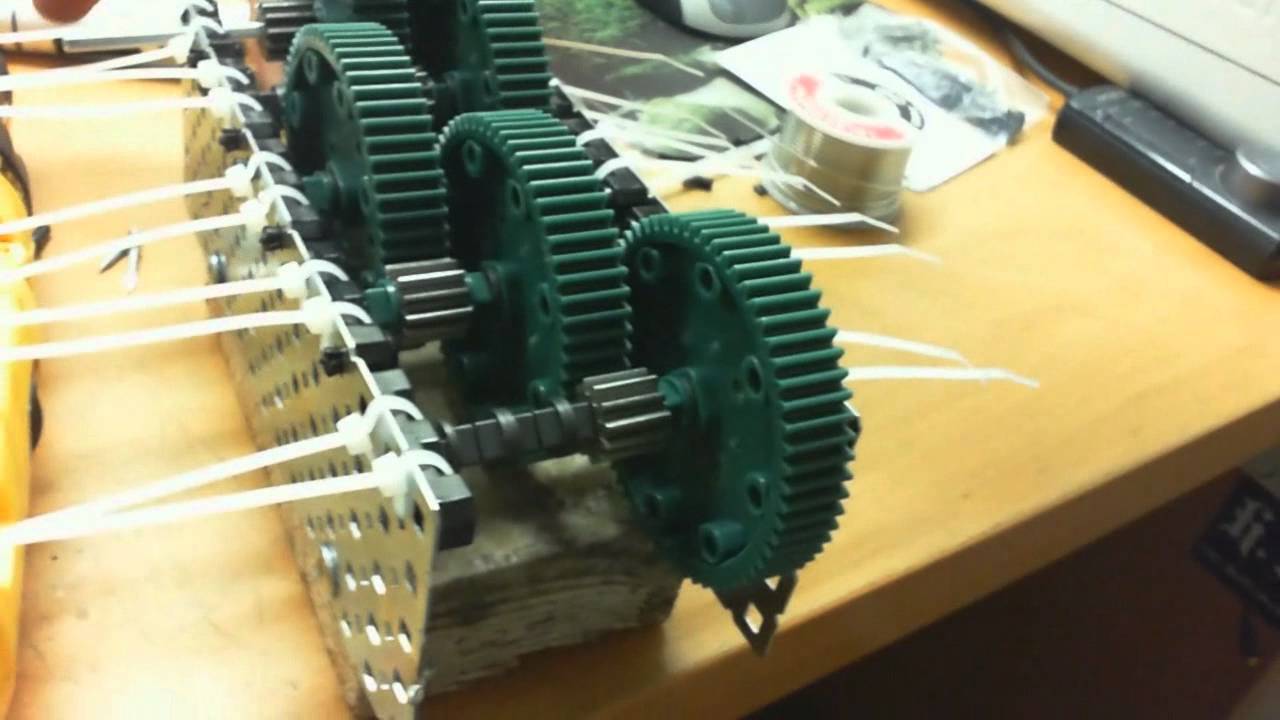
Also attach this to the gear box for maxium speed
Edit: Also add a 100 rpm motor so it has enough torque to spin it 
How about no
20202020
btw even for tracking wheels half cut wheels aren’t that great lol. The way the wheels are built the rollers are staggered to virtually always have a roller touching the ground.If you cut them in half you lose that
For drive motors, they are terrible. For tracking wheels, they are quite good with contacting the field since it is foam and not a hard surface.
Trolling like this could get you banned lol
Btw, literally nobody laughed. Nobody.
mom can we get engineering at home?
mom: we already have engineering at home.
engineering at home: 
false.
these are pretty funny
It was clearly jokes and I don’t think anyone lost anything from this but their time except for that one team that saw the bad idea and didn’t bother researching it
I mean we have the chit-chat/rumor mill topics if you want to meme. creating clutter with intentionally bad ideas not clearly indicated as a joke isn’t the best thing to do on a forum meant to help people, just saying.
There are threads dedicated to “funny”. This is listed under “TECHNICAL DISCUSSION”. I hate being that guy, but I like to think some people come on the forums to be productive and then they see this:
And then they sign out of their vex forum account and close the tab, never to touch the website again. Truly a sad case.
I’m NOT saying this can’t be a social hub, but don’t pretend like you’re in the right solely because it’s a light-hearted joke that I took too seriously. This kind of behavior is just sad and immature.
Here’s where you can go have fun with your memes (I’m sure there are other threads):
Also, truly believe me, I hate to be the “Karen” of the vex forums, but … nvm
I came on here to find out different ways to fit a highstrength gear and an omni wheel and all I found is a useless discussion that did not help me out much.
Please send pictures that are actual solutions that can work.

Here is a video about 4411S’s worlds robot where they have a similar base setup as your’s.
They drilled the outside c channels slightly so there will be just enough margin for the omni and gears to fit in the 1.5” space. You can also consider flipping one of the c channel and file down the spots which contacts the wheels.
In terms of slop, you can probably just ziptie the gear and wheel together. I did this on one of my base and the result turned out to be pretty good. Standoffs also seems to be an option but I’m not really a big fan on forcing things in