So I’m currently trying to find a way to decrease the motor value as it reaches certain stages. For instance, lets say that i was starting at 100rpm, then as i was halfway there it would slow the motor down to about 50rpm and when i got close it would change the value to about 10rpm. I have been experimenting with giving it a value to rotate to then slow it down but it halts and then goes which could knock over cubes in match. If someone could help me on what I am doing wrong it will be much appreciated 
Check out this link! Someone recently asked a similar question
https://renegaderobotics.org/pid-beginners-guide/
This might help, this is the theory behind what Torsten suggested.
I understand how they work its just for some reason vexcode is not liking something saying int is not a function pointer
int tilterPControl = ButtonR1 + 100(-1(Lift.rotation(degrees)/1.58));
Lift.spin(fwd,100,tilterPControl);
This would do it in blocks.
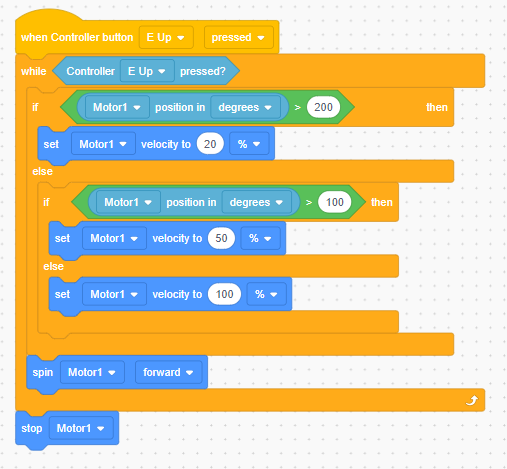
If the position is > 200 it will run at 20%, >100 50% and 100% otherwise.