Okay, ignore my example of TiP.
Rise Above I believe still exemplifies my point. There were robots that carried 6 risers, and just 1. Neither were as good as the ones that carried 3.
Okay, ignore my example of TiP.
Rise Above I believe still exemplifies my point. There were robots that carried 6 risers, and just 1. Neither were as good as the ones that carried 3.
Rise Above with 27 elements to place in 9 scoring zones in 60 seconds was a difficult game to max out. Some teams accomplished this. Every one who I saw able to max the game carried 3, not 6.
Pitching In has 22 game elements with one central scoring zone. It’s arguably a much easier game than Rise Above to [nearly] max out. Considering the similar number of game objects, I’d expect the ideal carrying capacity to be similar as well. The difference in the size of the game objects though introduces some difference in the carrying capacity though.
Agreed. Taking 11 double shots towards the center vs moving 27 large objects to all corners of the board is a significant difference.
I do believe that the 4 carry affords a significant advantage over 6, just because my team was able to make our high hanger much stronger after shrinking our hopper to four. We were still able to clear the board afterwards too.
Im gonna bring this topic back to life. I’ve noticed among the vex iq teams i mentor, 16688E has a faster bot with a 4 ball capacity outperformed 16688K with a 8 ball capacity because their cycle time was much faster. This in my opinion is like Next Level where the bots carrying 1 hub and dragging 4 were better than the ones dragging 6. Theres a sweet spot and i think ~4 balls is ideal.
As I’ve learned as well, the robots that I’ve seen that can do more than 4 are a lot slower because of their cycle time. It seems like if you can hold 4 you’ll do pretty well this game.
Just need to figure out the design is all.
In our last tournament, we went with a team that could cycle 10+ balls, they were 4th place. $ balls is definetely superior.
This is a interesting thread. Now when others are thinking meta, is this for teamwork or skills? Although I agree there are many good 4 ball catapults, I don’t believe that will be the meta at world’s. I think one reason there are many good 4 ball catapults, is because it’s a relatively simple to design and as someone has mentioned already, there are less ball jam issues because less complexity. And as such, many have “perfected” the design sooner. So the drivers would have had a lot more practice with the design early on compared to teams that are designing higher capacity bots. Resulting in generally higher scores. The other question is can the auto keep up the same performance with a 4 balls design since auto tends to run slower because of gyro turns. I have a feeling as the season progresses and teams start perfecting 6+ ball designs, they will start becoming the meta designs. They require more R+D and tuning but once “perfected”, those should be more efficient for both driving and auto. The additional couple of balls over 4 balls really doesn’t add a lot more overall weight to slow down the bot. There are already some impressive 6+ ball design in China. In fact the highest scoring ES LRT team has a 6 ball catapult. What I am looking forward to is seeing if a team comes up with a meta design that no one even thought about at world’s.
Anyway. That is my 2 cents. Cheers.
I think catapult is going to be meta for worlds, but instead of choo-choo mechanism, teams are prob going to use a cam follower.
What is a cam follower?
Cam follower is another catapult mech that pulls down catapult. There are many examples on youtube and VF.
By now many regional/state champions have been determined. I assume most of them at this stage are some sort of Catapult design. So let’s do a poll of how many ball storage are the champions so far and get an idea of what is the Meta Design possibly for Worlds.
whats VF 20charrrrrrr
VF = Vexforum I believe  But I am pretty new so I don’t know all the ins and outs yet.
I have seen the future and it holds 10 balls! See you in Dallas!
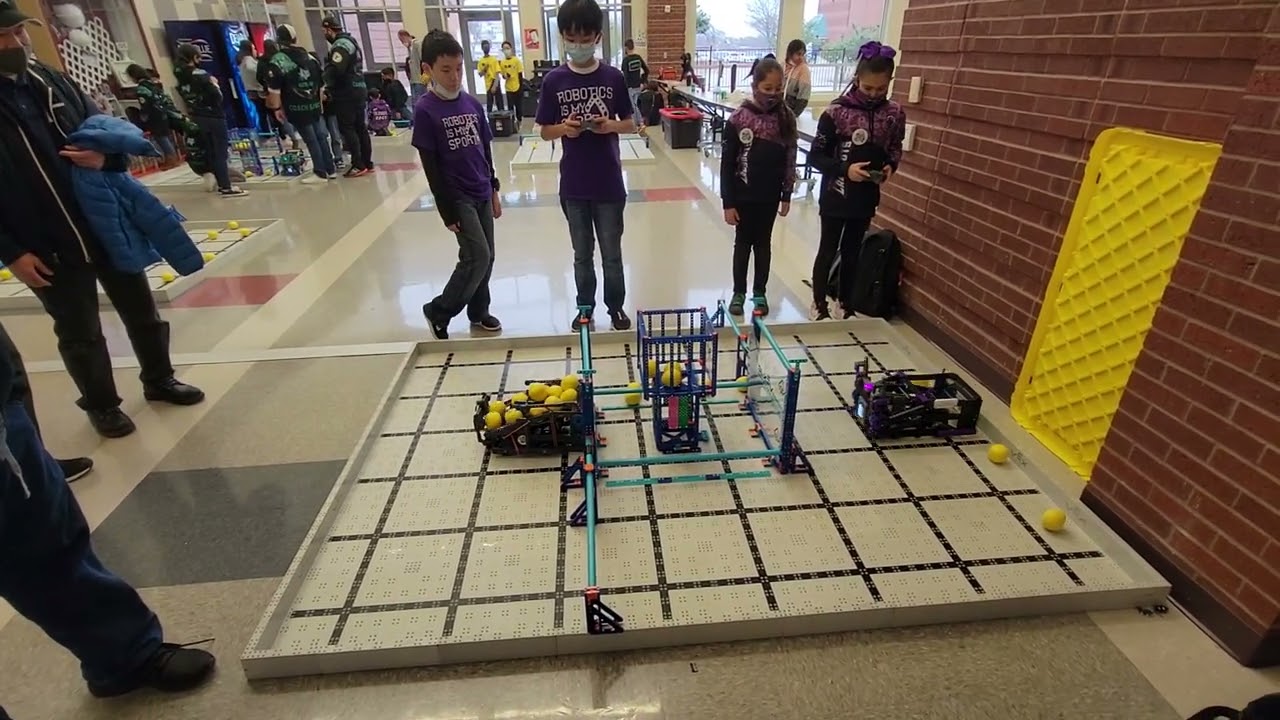
I think this design will quickly become the meta. 10+ balls op
The only problem is, I have a four ball catapult that does that much faster, and it can high hang. Besides, Worlds is in a month so not much time to rebuild and recode
It’s getting close to world’s now so I figured I would bring this thread back to life. My team I mentor worked on high ball capacity robots all season. It’s interesting to see many teams are increasing their ball capacity now.
Here is a new video I came across. Interestingly it’s very similar to my team’s design they have been working on the majority of the season.
The ball indexer of this bot in this video is pretty interesting.
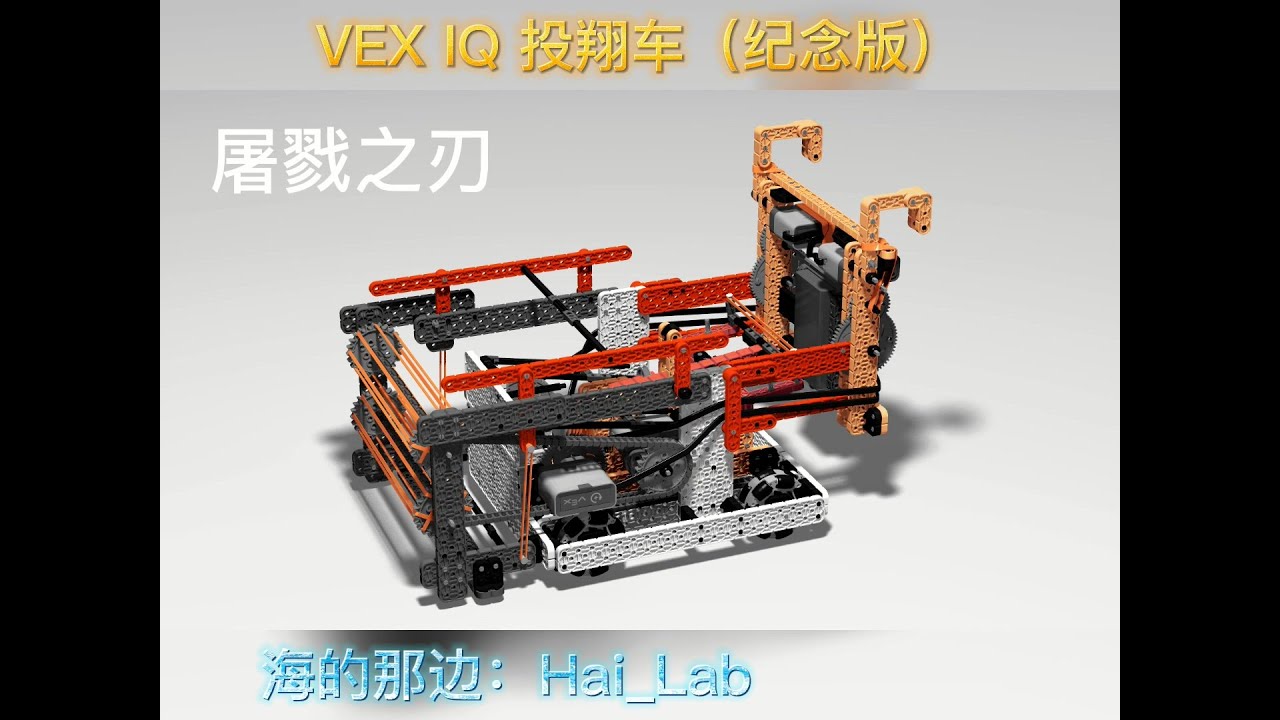
World’s will be very interesting since it seems many might be bringing bots that are different from their state finals.
See you at world’s
Cheers.
If anyone can get me in contact with the 8th grader that designed and built this please let me know. I would like to offer them a job on their 18th birthday. Like Nick Saban, it is good to get those offers out early.