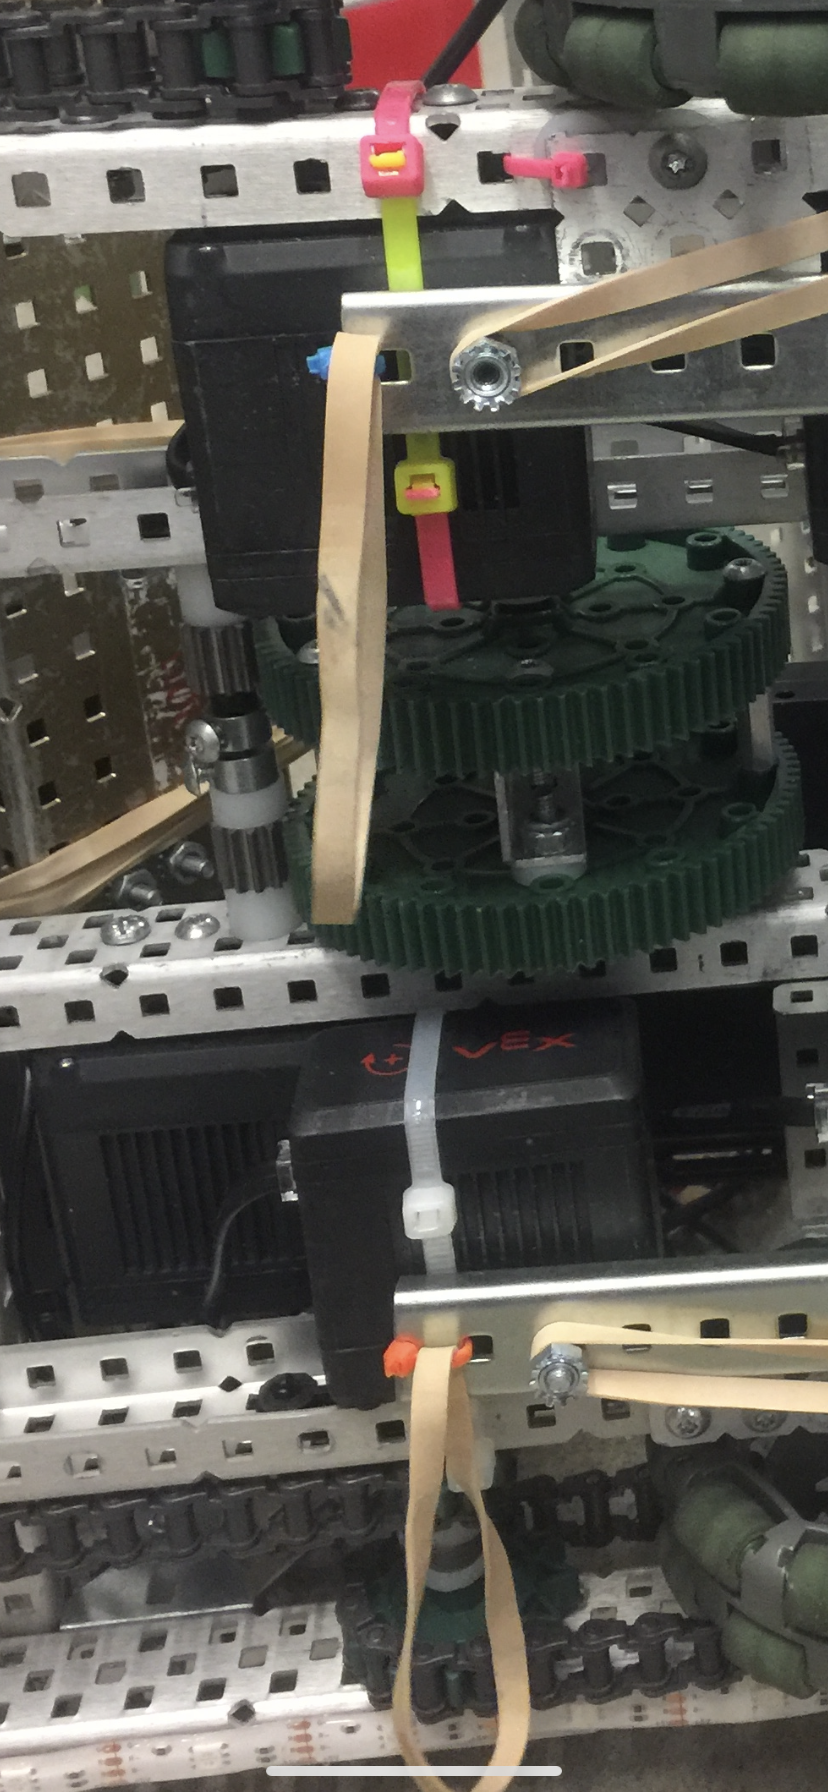
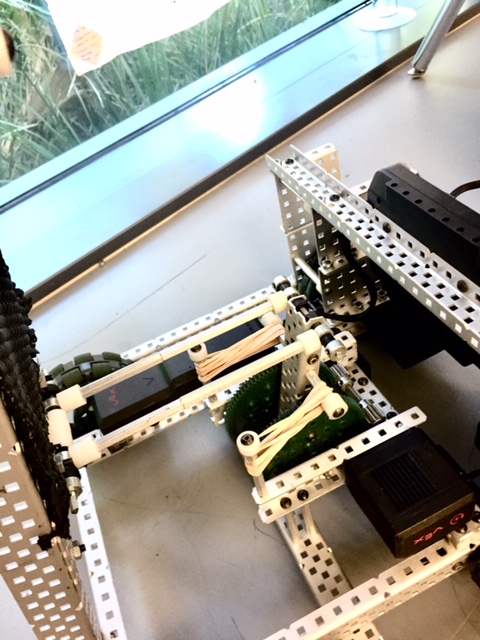
first check to see if there is any significant friction in the mechanism, because that will kill it. then, try adding some rubber bands to assist the tilter in its struggles.
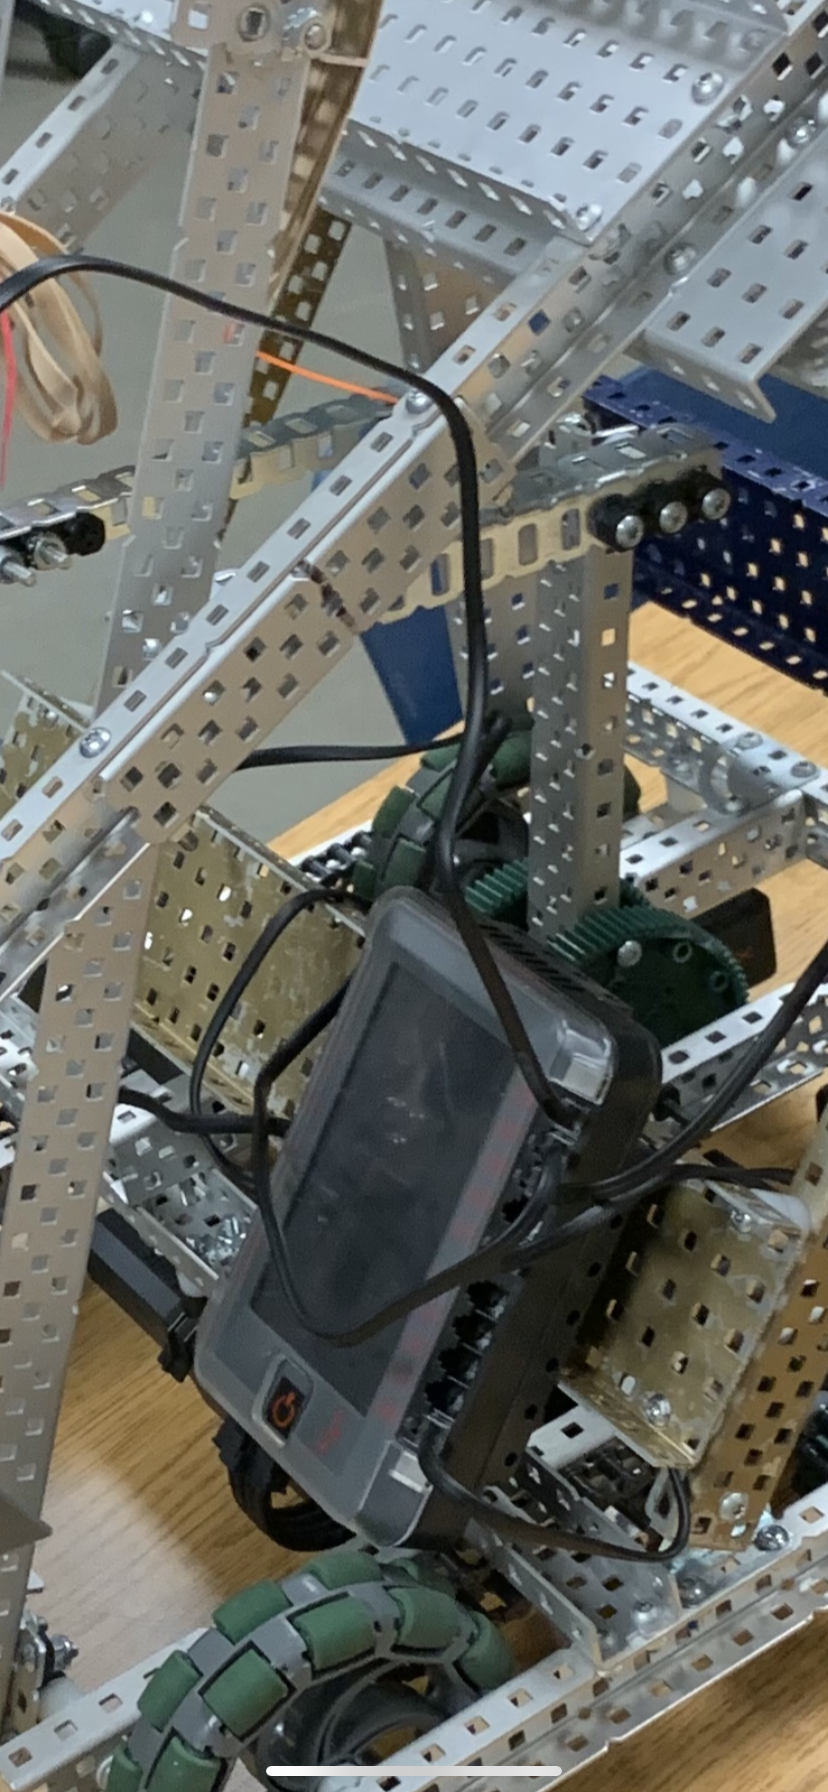
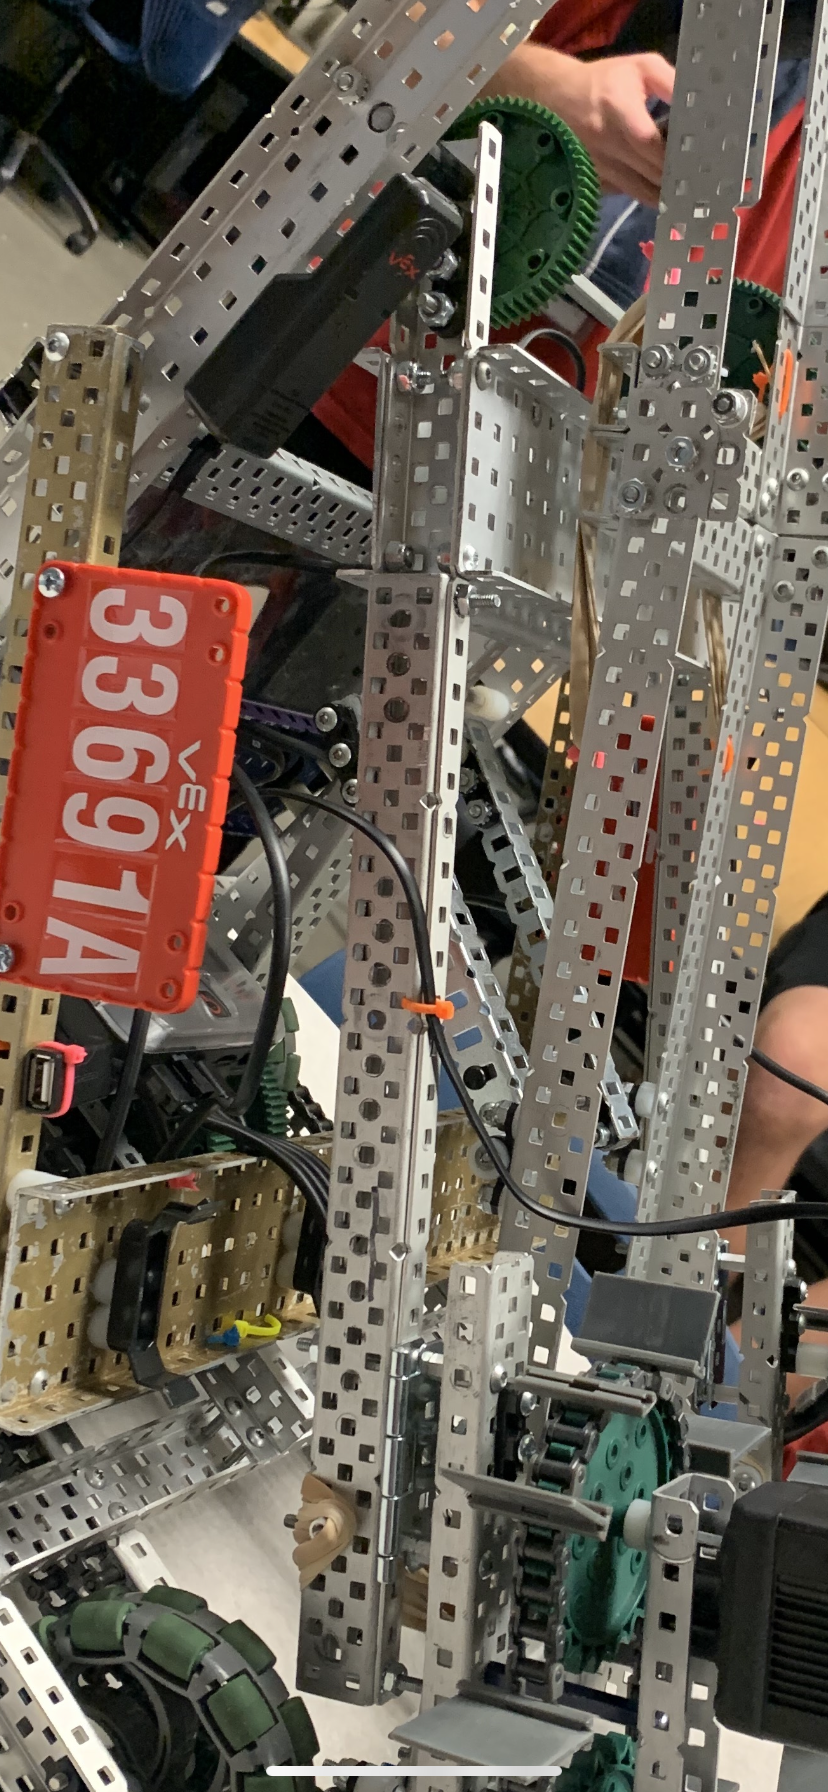
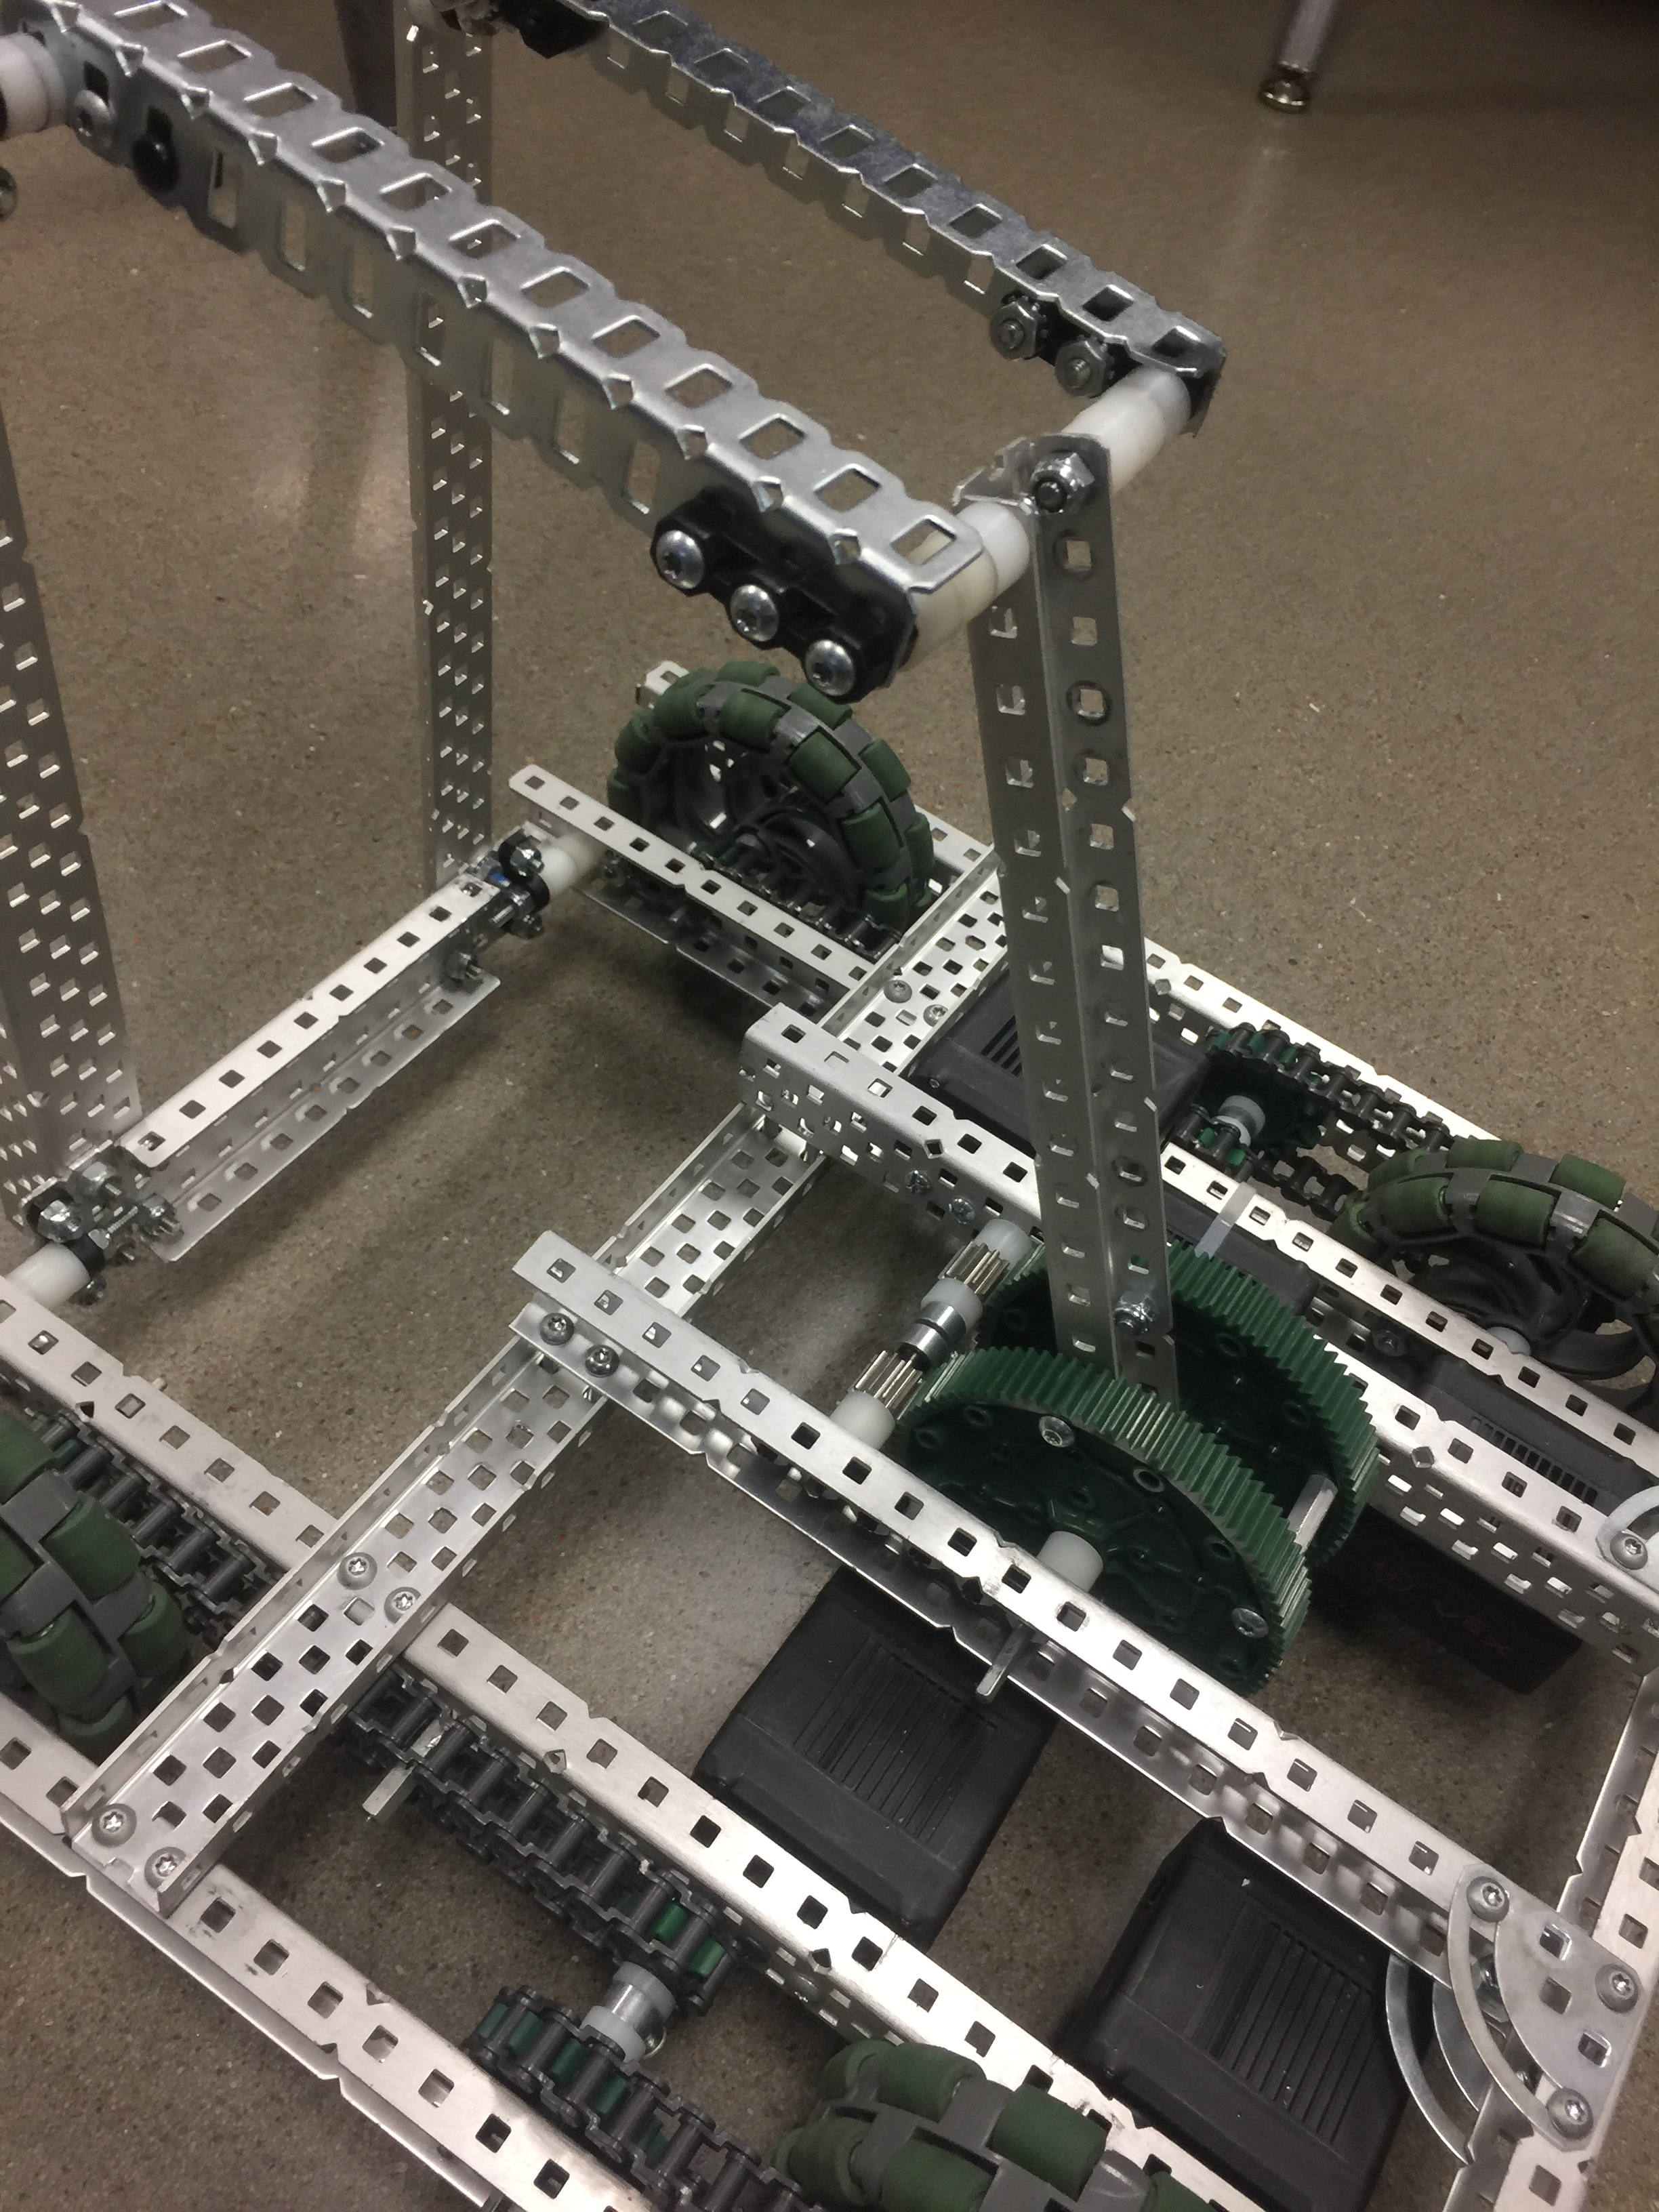
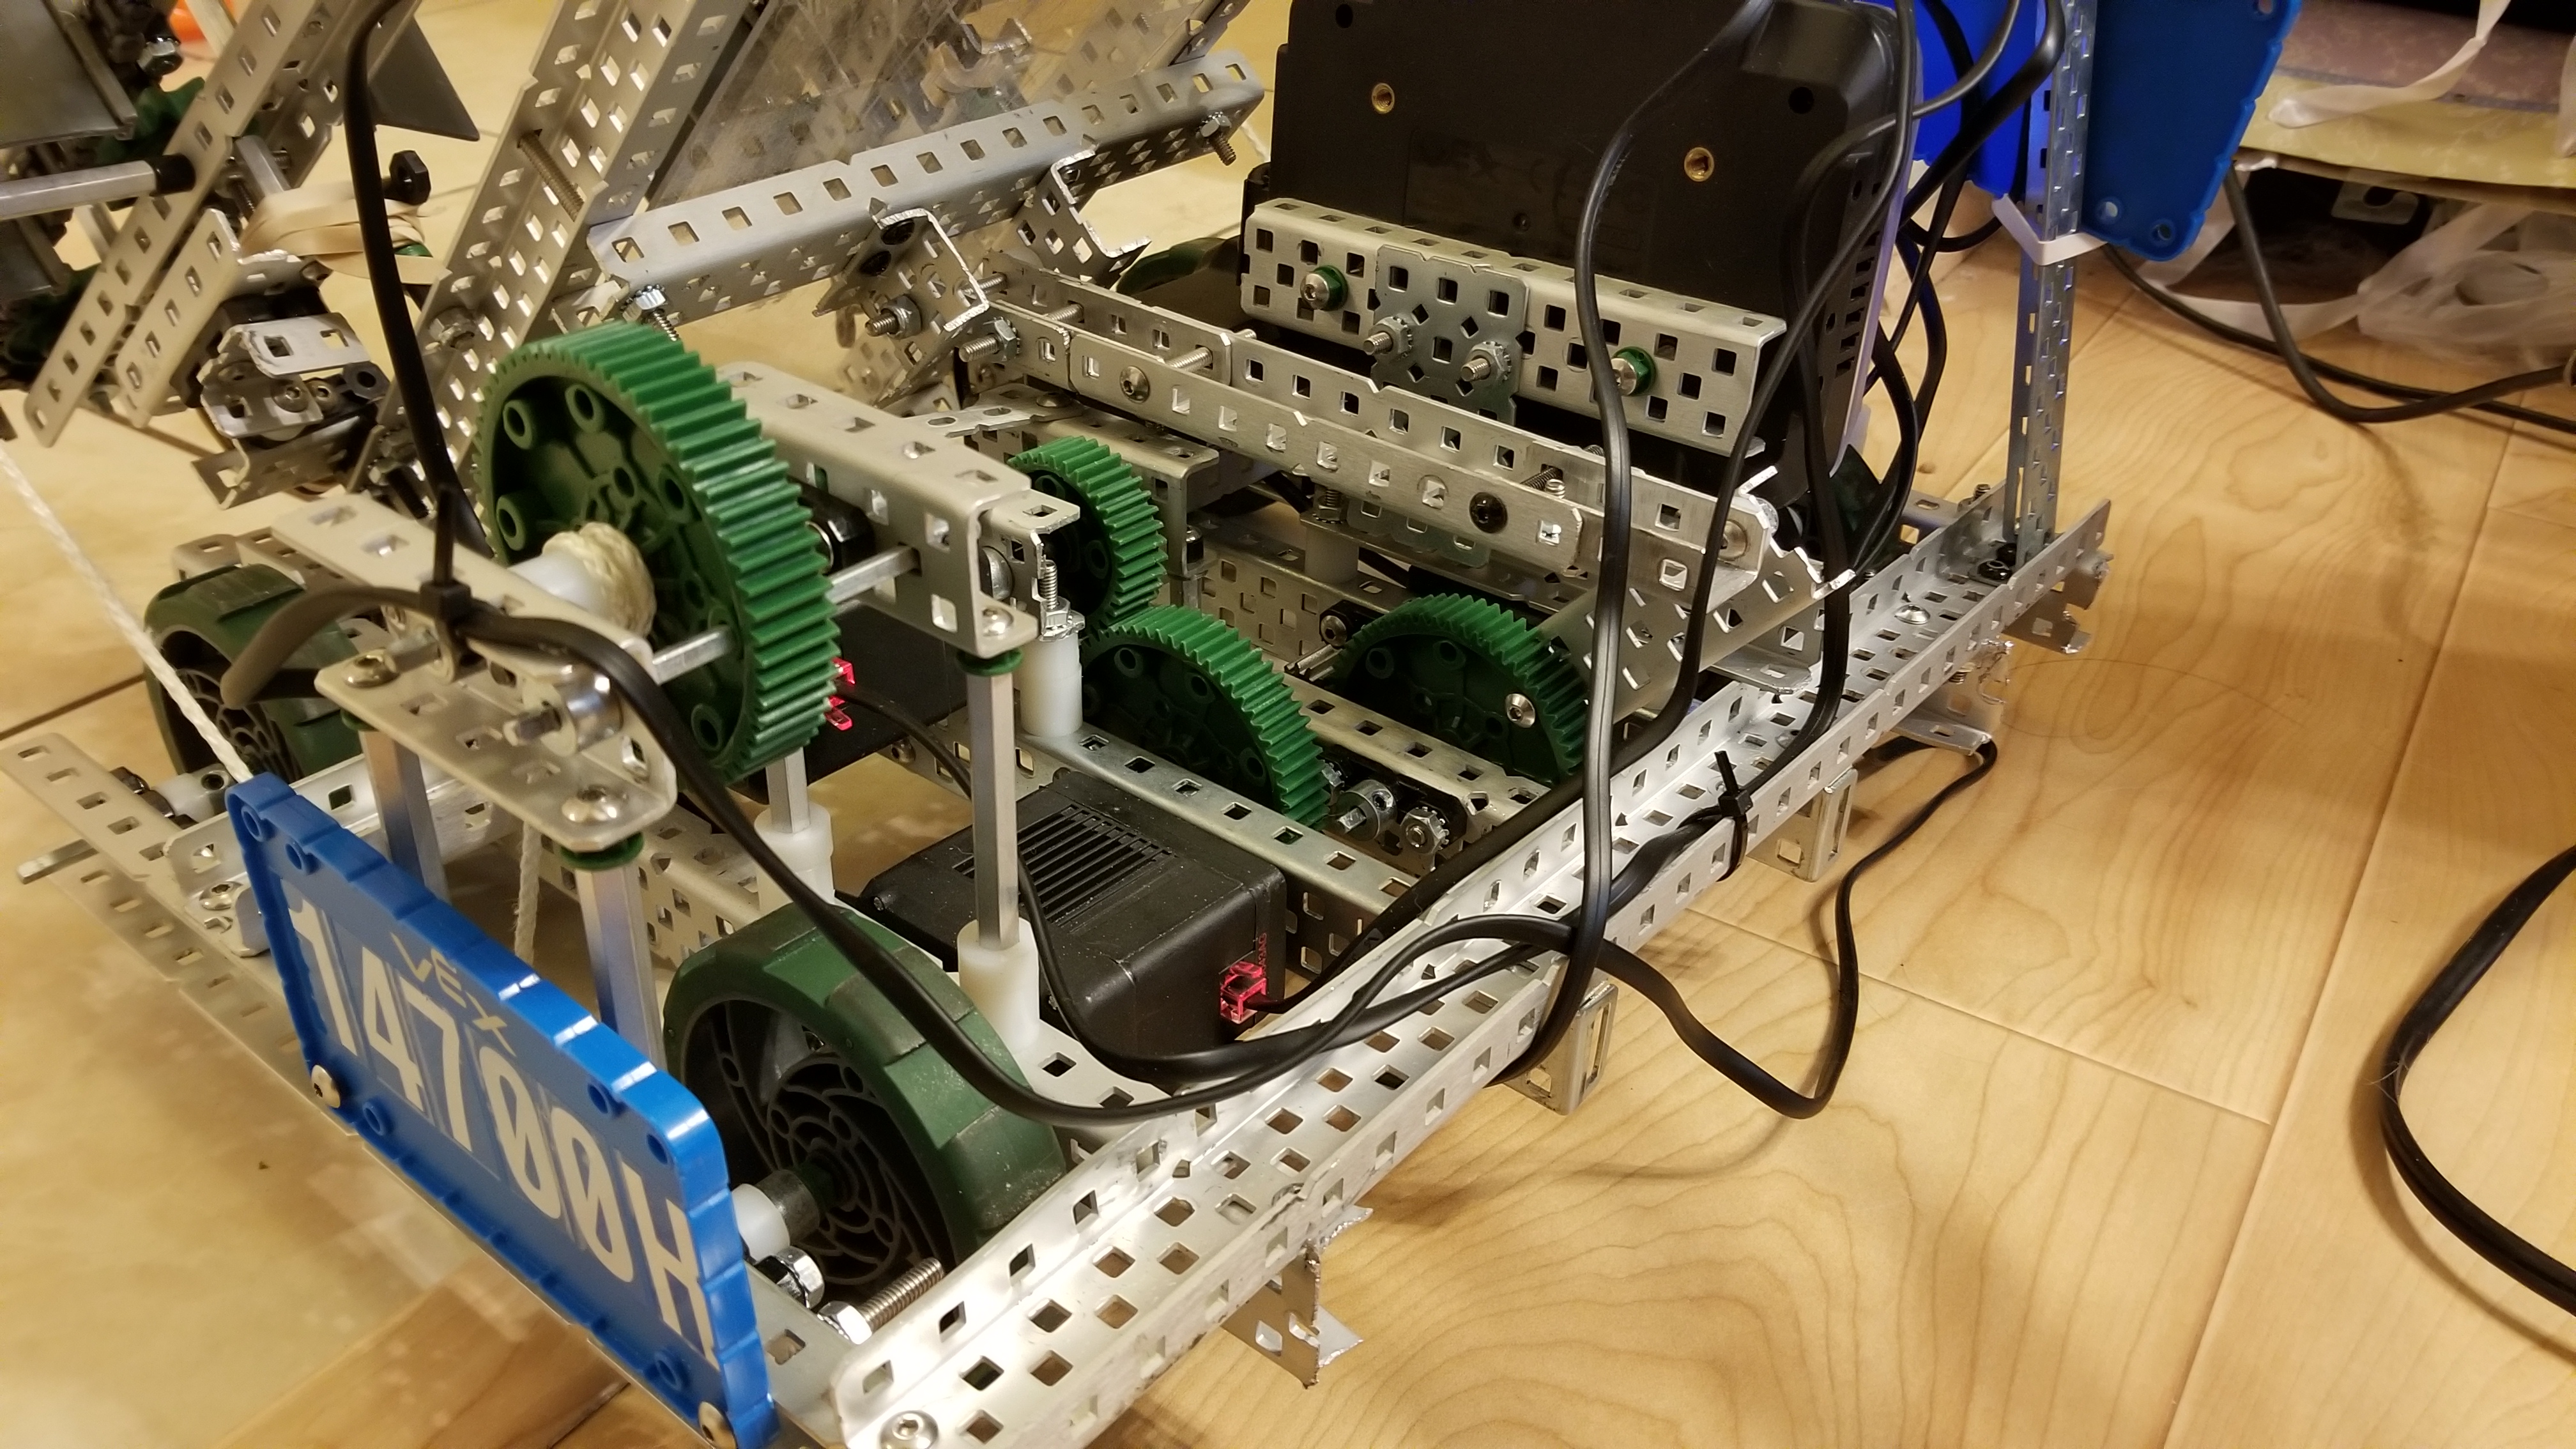
then there must be some issue somewhere else. a compound ratio may still be your best bet, but if you rebuilt and compacted your tilter that could be good also. here is a picture of our tilter:
Don’t use standoffs for the arm like we did, I’ve been told that they lack the structural integrity to be trusted here, but we have no issues whatsoever with our tilter.
Given the insane torque(14.7Nm!) of your 100 RPM 1:7 setup, I doubt that the problem is from friction or the weight of the tray.
Your code could be causing the tilter arm to push against the drive axle or a piece of metal when the tray is tilted back, stalling the motor and causing it to overheat.
That is a good example. What does the gear assembly and rope that go around the left side of the robot work? It looks like the 84t is tied to a c-channel with an axle?