If I use a straight flywheel should I use two motors to spin faster and a motor indexer, or a slower flywheel with a pneumatic indexer.
Disclaimer: I have done no testing and this is pure speculation on my part, based on research and reading around on the forum
I think that a 2m flywheel will be necessary. I see others talking on the forum how 1m flywheel doesn’t have enough power to consistently shoot across the field, and it also loses a lot of power.
I’m not entirely sure about using pneumatic indexers. Others on the forum have said it’s ok, but I still worry about having enough pressure to index a larger number of discs. Granted, you may not have to use it a lot in teamwork, with 4 teams on a field with 2 high goals with a rough 20 disc capacity meaning you would only have to shoot around 10 ish discs. I worry more about skills and having enough pressure to fill both of the high goals alone
Also for my specific robot case, I have no spare motors for a 2m flywheel and a separate intake feeder/indexer, so I’m trying to figure out a way around that right now
Again, better to do your own testing, this is what I think after just browsing the forum
Indexing doesn’t require a lot of pressure so a pressure regulator and two reservoirs should give enough air.
I believe the people who made the MARC robot in the RI24hr video said it can shoot about 50 discs before running out of pressure from two reservoirs.
I’ve heard that a one motor flywheel works pretty well and that the two motor might be unnecessary but I recommend every one to try it themselves.
The indexing arm can actuate about 50 times as per their comments on the YouTube video, but theoretically if powered by a motor it could allow the shooter to “shoot” as many discs as possible.
The 3" balls from Turning Point, for reference, were 55 grams. The discs this year are 65 ±10g. Single motor flywheels launching balls during Turning Point were fairly common; granted, that was shooting from about 3 tiles away. But yeah, it’s reasonably possible to run a 1 motor flywheel seeing it worked during Turning Point’s similar setup.
Yeah, a motor powered indexer would be better, especially for teams without pneumatics. My prototype motor distribution is currently 4 motors for the drivetrain, 1 motor for intake, 1 for indexer and geared to the intake to share power using a ratchet gear, and 2 on the flywheel.
If using a motor for the indexer you should probably ratchet it to another mechanism, because there is so much more power from the motor tht could still be used.
That’s what I meant by the 1 motor for the indexer and geared to the intake. Both motors will be active for intaking and the indexer will be inactive when spinning one way. If the indexing motor spins the other way, the intake will run reverse and the indexer will push the discs into the flywheel.
Or maybe even better would be building a differential so you can power a fly wheel and use the indexer with the same motor, this could solve your problem with motor distrbution.
I got 100 actuations that are able to push a disk from a single acting pistons on two reservoirs
I’ll have to look into that. I’ve never actually built one before, and I don’t really understand the mechanics quite yet. Thanks for the guidance.
If anyone wants to try sharing motors with ratchets, you may want to study these classic reveals:
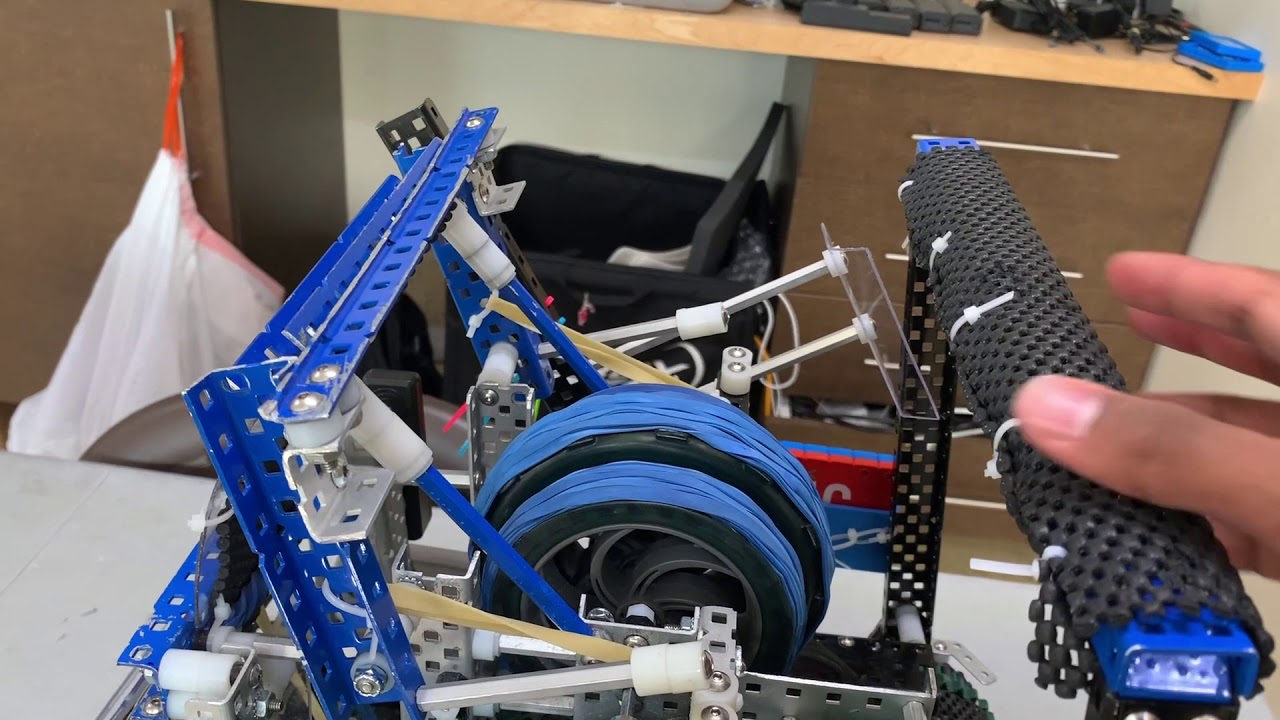
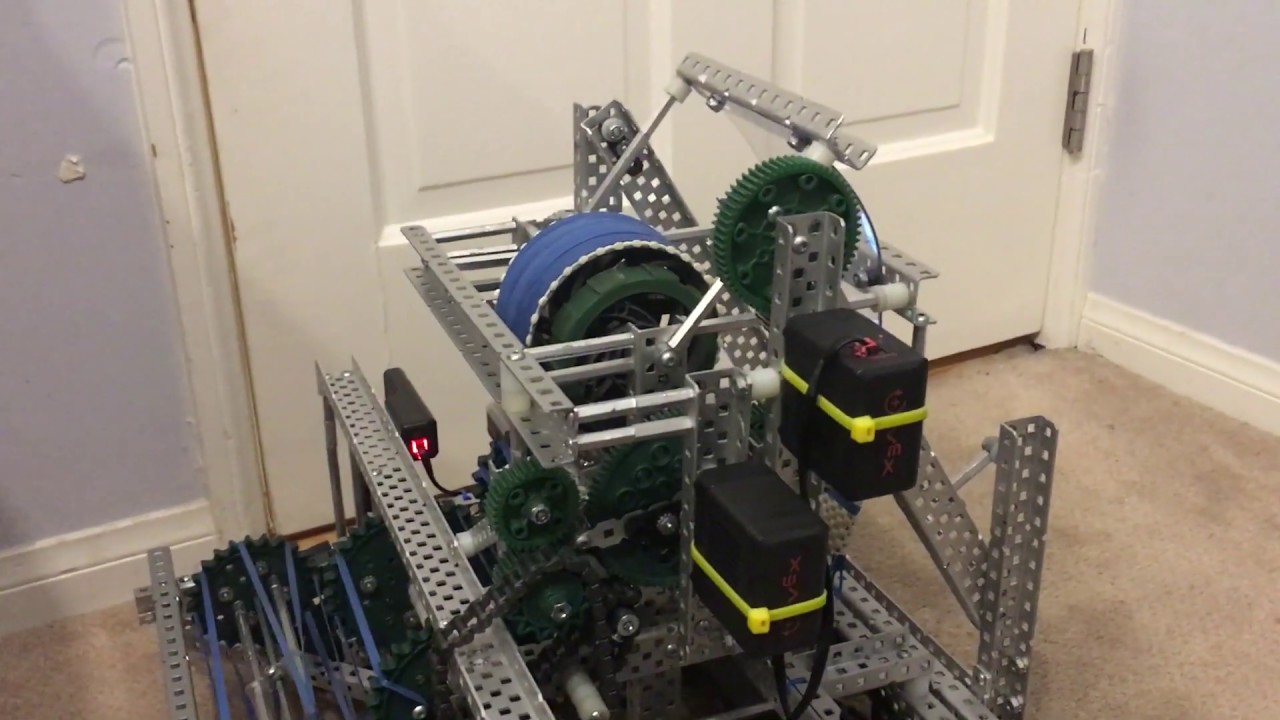
It should be relatively easy to have a single motor flywheel and then another motor to power both intake and indexer.
If you need to have one extra function (like an angle changer) and somehow share it with flywheel motor, it should be possible too, but you may run into tricky control issues. I would just leave flywheel motor alone to make it easier to control its speed precisely and reliably.
ill build an example of this today and post it here for you! I feel like this would be a good option with the way you plan to distribute your motors.
Here is the differential I made. It’s very poorly built, but still shows how the design works.
Video of Differential
You may have to download the video at the top right.
When both motors are spinning at the same speed in the same direction the indexer remains still.
When you raise or lower the speed of the indexing motor it will move, but all while still giving exra power to the flywheel.
I’ve got a question for those of you who received your field elements already. How sturdy is the high goal? If an aluminum bot were to climb it, would it brake? Does anyone know if that action would deemed illegal?
@1422_WI
G16
… 20 characters …
Definitely illegal
The goals themselves are held in by some PVC pipe and the same piece that the goals from tipping point had (the circular one that you tighten similar to a shaft collar). I’m a little concerned for the longevity of these pieces, and although I doubt a disc will be thrown with enough force to knock it down, theyre secured to the point where theyre able to spin in place (assuming i set them up correctly). Pictures below
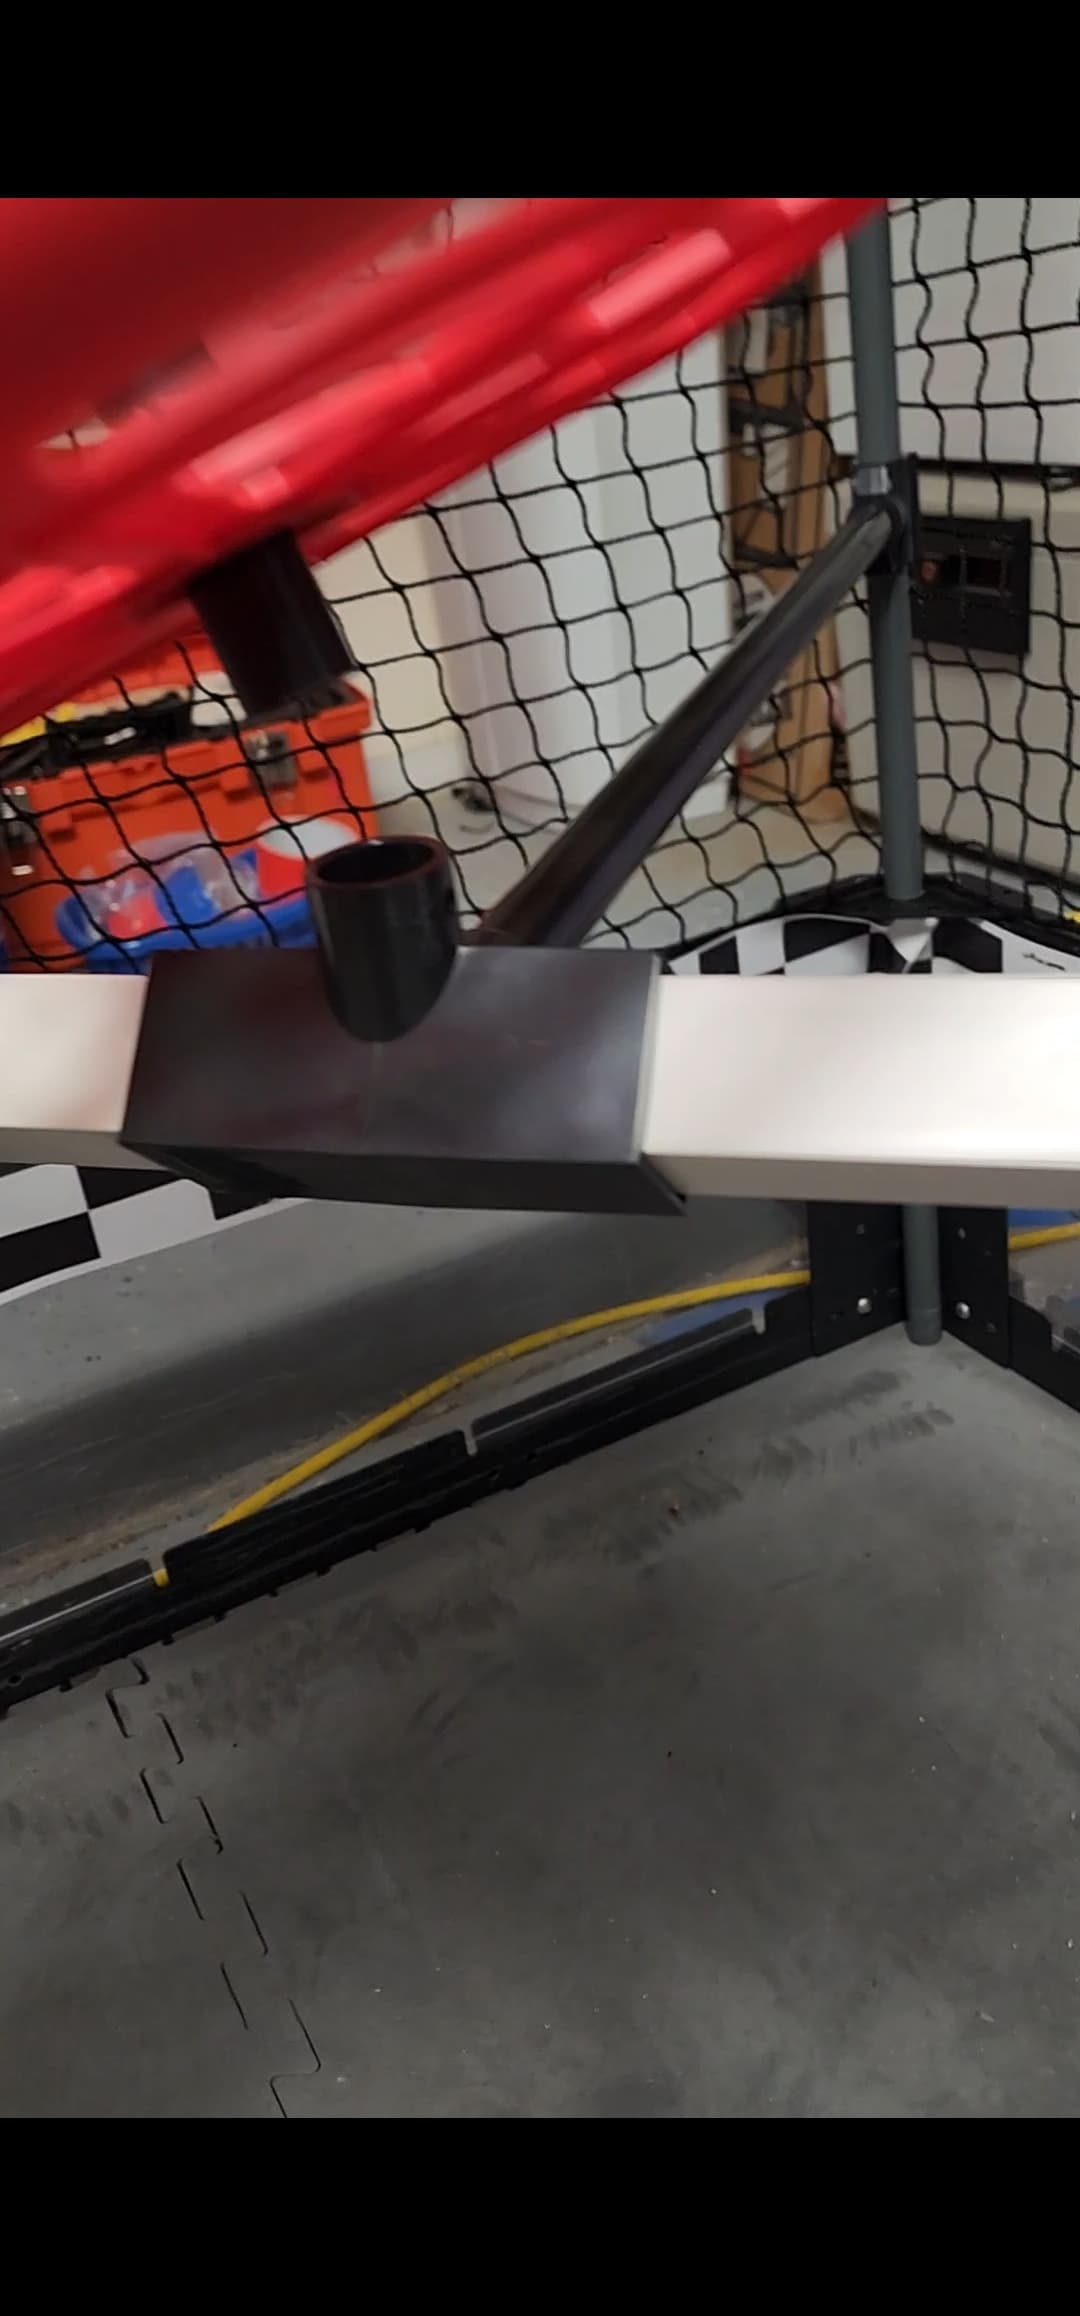
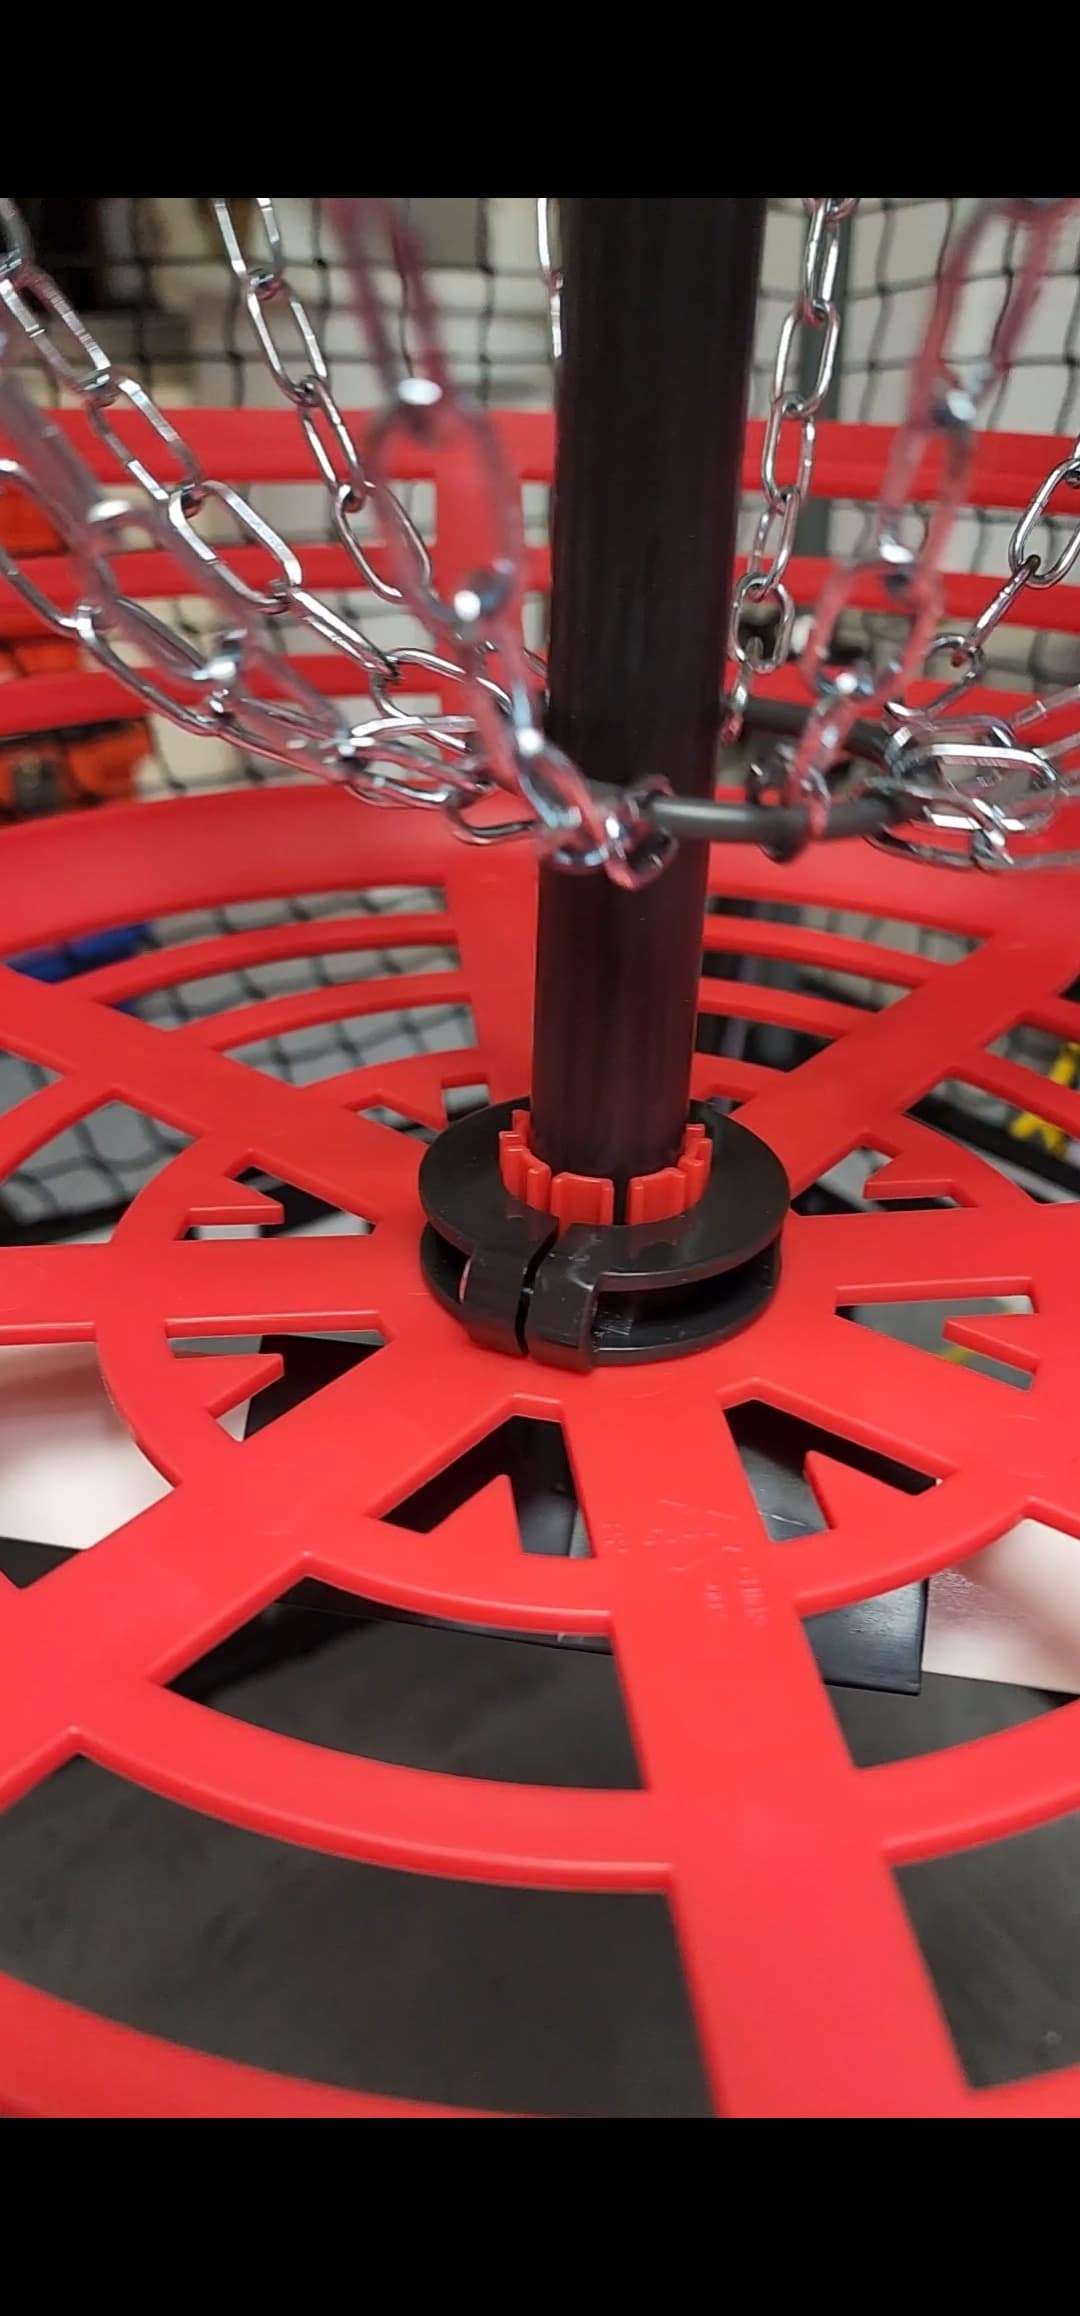
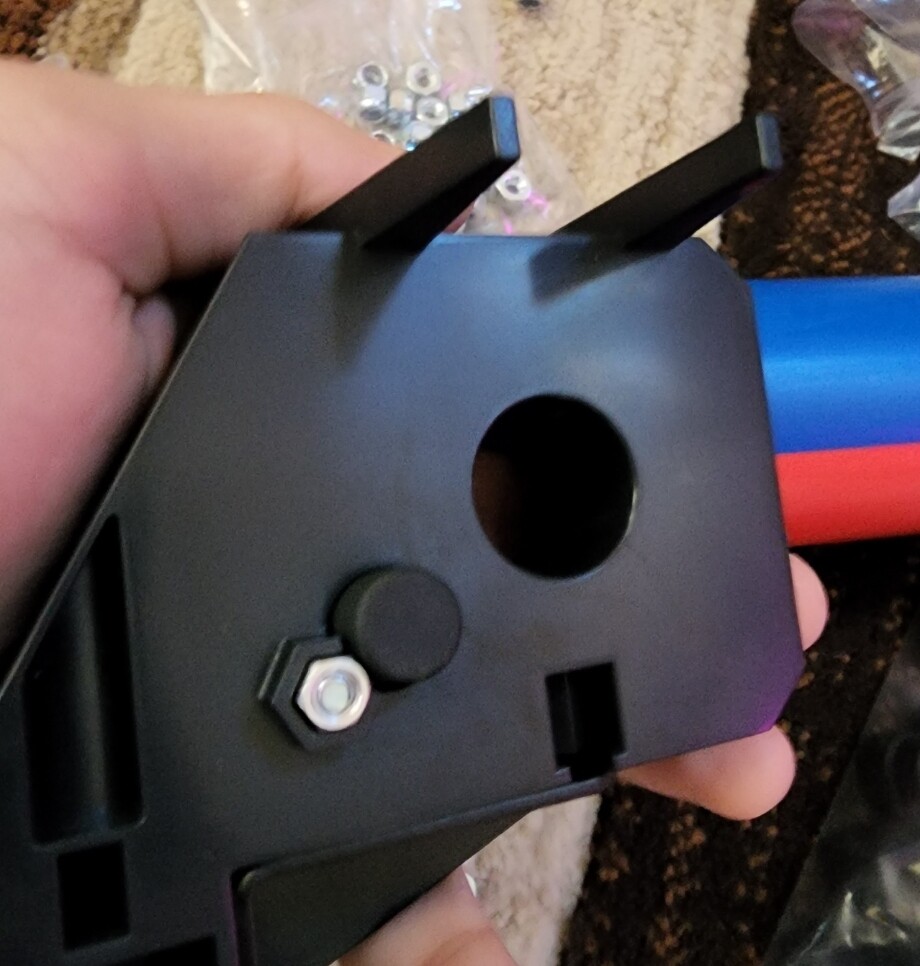
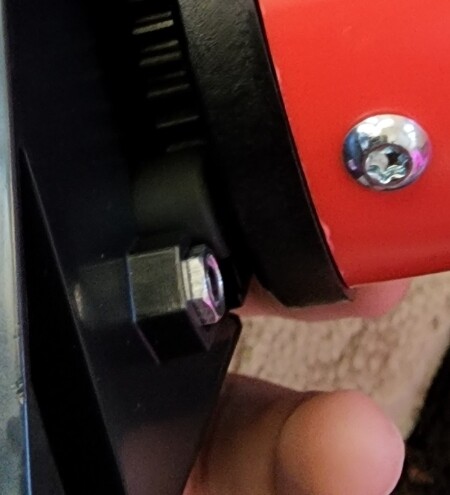
Also a little skeptical about the durability of the rollers, as the “ratcheting” mechanism is just a gear with resistance from some rubber
The rubber ratcheting piece is designed to be rotated as it wears to keep it fresh, but yes on a practice field in your shop I think you may wear it out over the season. I think it was brought up elsewhere, but there is also interference between the bolt head through the roller and the “pointers”.